
Robomanics
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
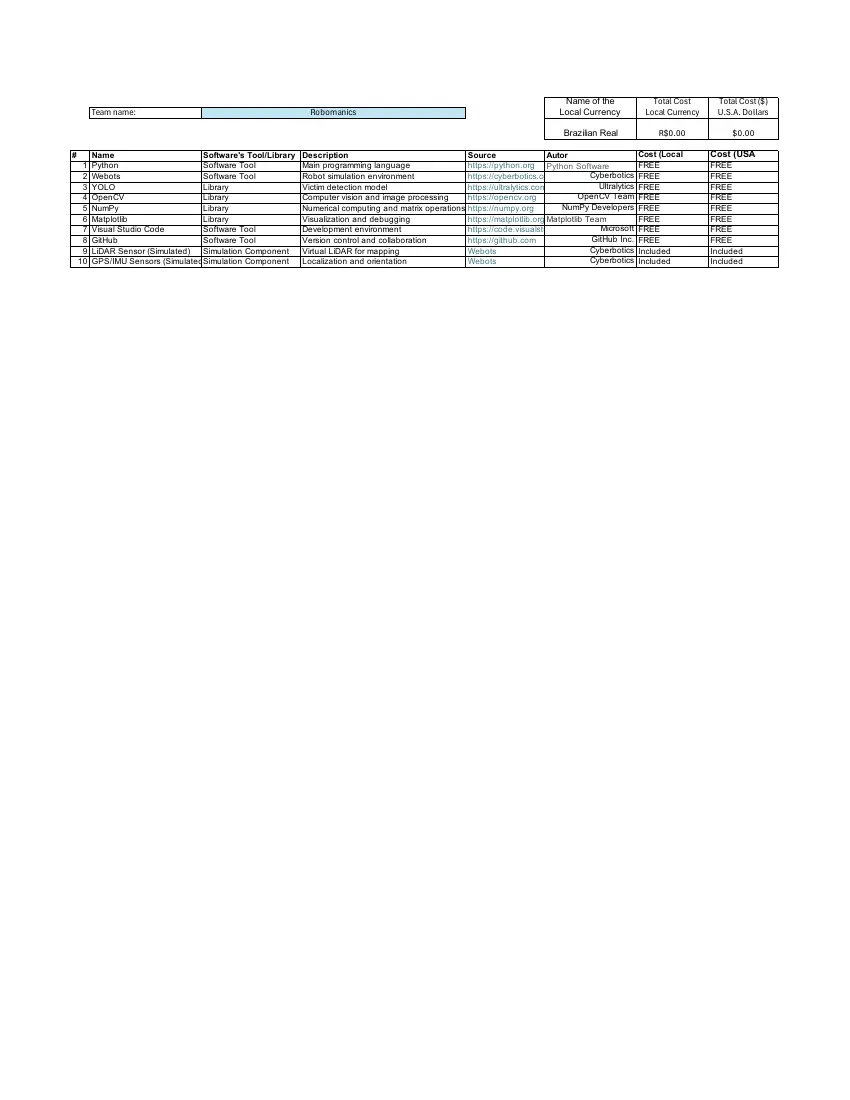
- Bill of materials1 pagePublished
- Team description paperNot shared
- Engineering journalNot shared
- Source code6 KB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
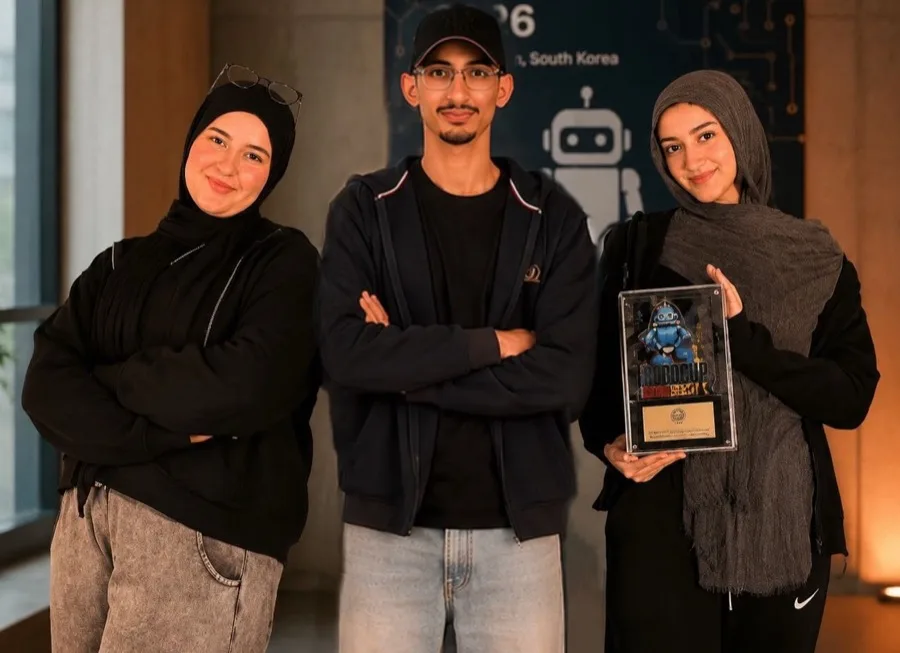
In their words
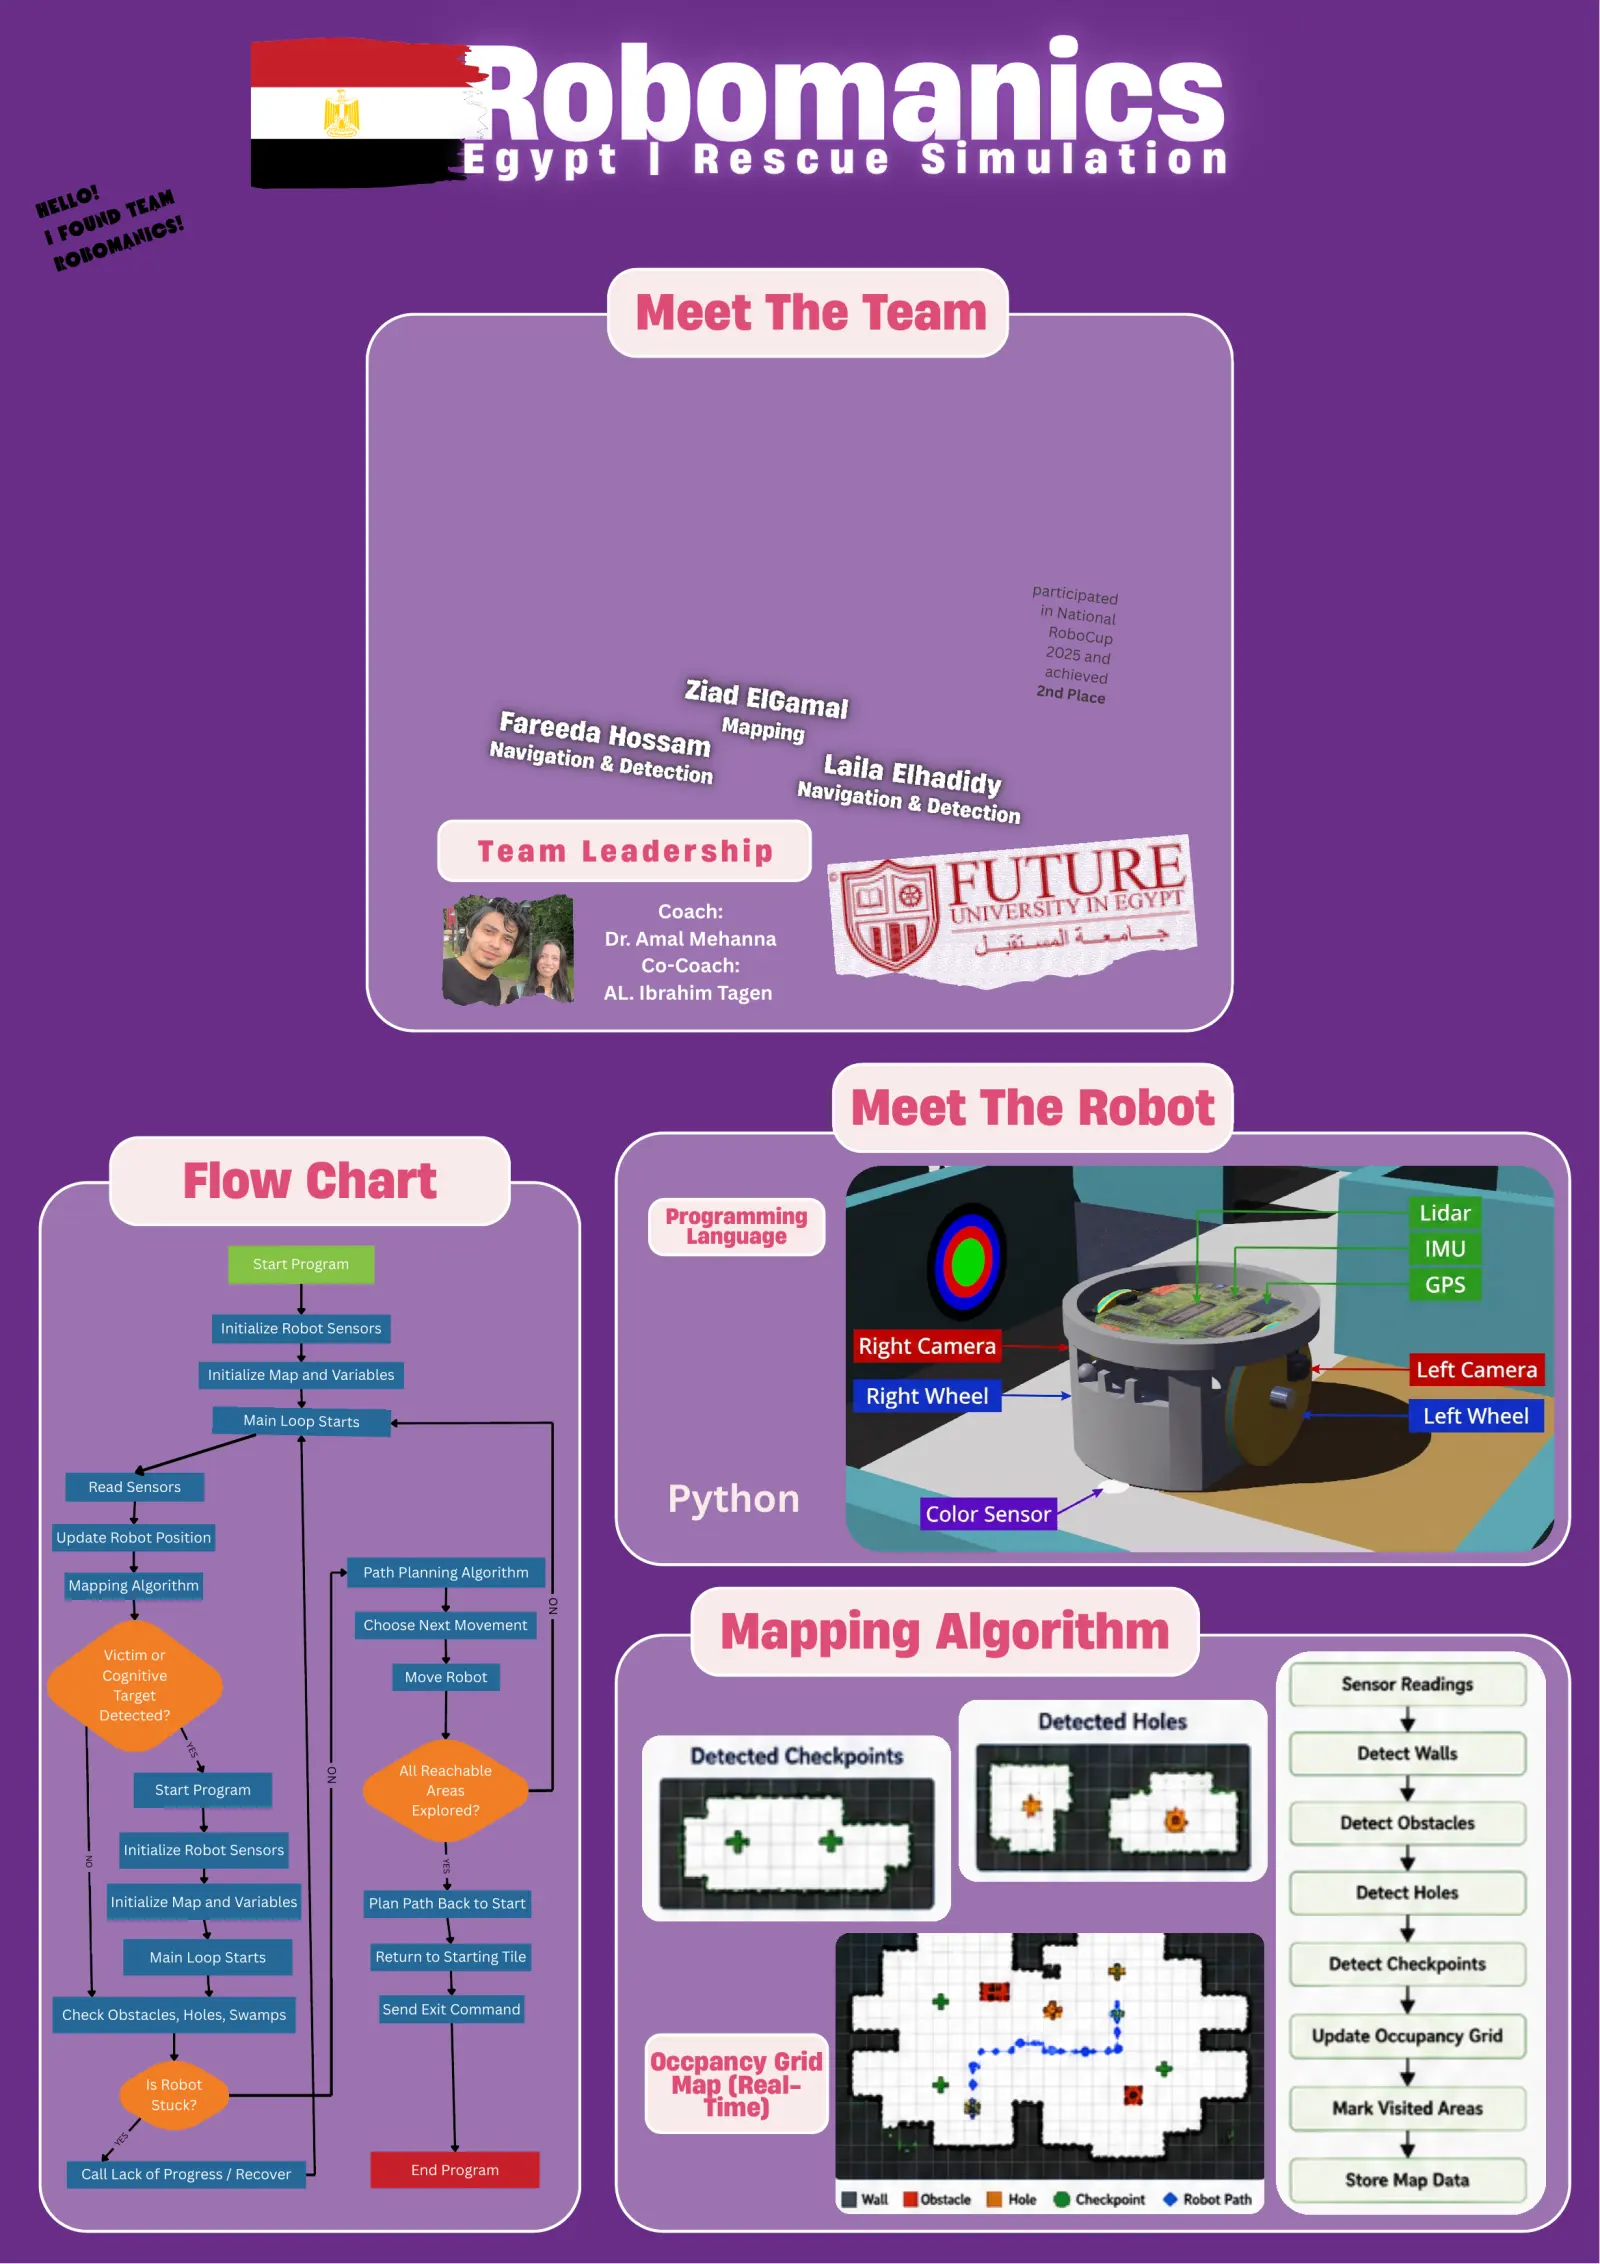
Robomanics is an autonomous rescue simulation robot designed to explore unknown environments, detect victims, solve cognitive targets, and safely return to its starting position. The system is developed in Python and follows a modular architecture consisting of perception, decision-making, and motion-control layers.
The robot continuously collects data from GPS, IMU, LiDAR, distance sensors, and RGB cameras to build an occupancy-grid representation of the environment. This map is used to identify walls, obstacles, holes, checkpoints, and unexplored areas. Using autonomous path-planning and navigation algorithms, the robot efficiently explores the arena while dynamically adapting to environmental changes and handling recovery situations when navigation difficulties occur.
For victim detection, the robot processes camera images to identify and classify rescue symbols, determine their locations, and report them accurately. In addition, a dedicated cognitive target detection module recognizes circular targets, extracts ring colors, converts them into numerical values, and classifies the target according to competition requirements.
What distinguishes Robomanics is the integration of mapping, victim detection, cognitive target recognition, autonomous exploration, and recovery mechanisms into a unified decision-making framework. This allows the robot to operate efficiently in complex environments while maintaining reliable performance, accurate reporting, and complete mission execution from exploration to safe return.
Poster
Read the text of this document — 168 words
!
                                                                      Robomanics
                                                                      Egypt | Rescue Simulation
   ll o      eam
He      nd
           T
   f ou       ics!
 I       m an
        o
   Rob

                                                                                         Meet The Team

                                                                                                                                   participa
                                                                                                                                            ted
                                                                                                                                    in Nation
                                                                                                                                              al
                                                                                                                                     RoboCup
                                                                                                                                     2025 and
                                                                                                                                     achieved
                                                                                              Ziad ElGa                            2nd Plac
                                                                                                          mal                                e
                                                                         Fareeda         Mapping
                                                                        Navigati
                                                                                  Hossam
                                                                                o   n & Dete
                                                                                            ction           La i l a E l h
                                                                                                          Navigati     adidy
                                                                                                                  on & Det
                                                                                                                          ection

                                                                      Team Leadership

                                                                                            Coach:
                                                                                      Dr. Amal Mehanna
                                                                                          Co-Coach:
                                                                                      AL. Ibrahim Tagen

                                                                                                                Meet The Robot
                      Flow Chart
                                                                                            Programming
                                                                                              Language
                                  Start Program

                             Initialize Robot Sensors

                            Initialize Map and Variables

                                 Main Loop Starts

                                                                                            Python
      Read Sensors

  Update Robot Position

                                                    Path Planning Algorithm
   Mapping Algorithm

                                                                                                    Mapping Algorithm
                                                                               NO

                                                    Choose Next Movement

          Victim or
          Cognitive                                        Move Robot
           Target
          Detected?
                      YE
                        S

                                                           All Reachable
                                             NO

                 Start Program                                  Areas
                                                             Explored?

             Initialize Robot Sensors
     NO

                                                                YES

           Initialize Map and Variables             Plan Path Back to Start

                Main Loop Starts                     Return to Starting Tile

  Check Obstacles, Holes, Swamps                        Send Exit Command

                                                                                          Occpancy Grid
                Is Robot                                                                   Map (Real-
                 Stuck?                                                                       Time)
            S
           YE

     Call Lack of Progress / Recover                        End Program
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Read the text of this document — 154 words
Name of the             Total Cost      Total Cost ($)
       Team name:                                             Robomanics                                                        Local Currency         Local Currency    U.S.A. Dollars

                                                                                                                                  Brazilian Real           R$0.00            $0.00

#      Name                       Software's Tool/Library   Description                               Source                 Autor                     Cost (Local      Cost (USA
     1 Python                     Software Tool             Main programming language                 https://python.org Python Software               FREE             FREE
     2 Webots                     Software Tool             Robot simulation environment              https://cyberbotics.com            Cyberbotics FREE               FREE
     3 YOLO                       Library                   Victim detection model                    https://ultralytics.com              Ultralytics FREE             FREE
     4 OpenCV                     Library                   Computer vision and image processing      https://opencv.org              OpenCV Team FREE                  FREE
     5 NumPy                      Library                   Numerical computing and matrix operations https://numpy.org         NumPy    Developers    FREE             FREE
     6 Matplotlib                 Library                   Visualization and debugging               https://matplotlib.org Matplotlib Team           FREE             FREE
     7 Visual Studio Code         Software Tool             Development environment                   https://code.visualstud              Microsoft FREE               FREE
     8 GitHub                     Software Tool             Version control and collaboration         https://github.com                 GitHub Inc. FREE               FREE
     9 LiDAR Sensor (Simulated)   Simulation Component      Virtual LiDAR for mapping                 Webots                             Cyberbotics Included           Included
    10 GPS/IMU Sensors (Simulated)S imulation Component     Localization and orientation              Webots                             Cyberbotics Included           Included
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Source code
The team's own source code, 6 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.