
Kavosh_Simul
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials33 KBPublished
- Team description paperNot shared
- Engineering journalNot shared
- Source codeNot shared
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
Kavosh_Simul is an autonomous Rescue Simulation robot designed around efficient wall inspection, reliable token detection, and modular software integration. The robot uses a two-wheel structure with two side-facing cameras, GPS/location sensing, IMU, LiDAR, color sensing, and distance sensors, including a downward-facing distance sensor for early hole detection. Its software is organized into independent modules for sensing, vision, mapping support, navigation, motion control, and reporting.
The main strength of our system is its perception pipeline. Instead of sending every full camera frame directly to a neural network, the robot first searches for meaningful wall candidates, crops only the region of interest, and then sends the ROI to a YOLO11s detector for Greek victim symbols. Cognitive targets are handled separately using an OpenCV-based rule pipeline with HSV segmentation, circular filtering, ring sampling, and numerical classification. To improve reliability, detections are verified through confidence checks, temporal confirmation, 3D fake-victim rejection using depth information, and GPS/yaw/LiDAR-based duplicate suppression.
What sets our robot apart is its focus on practical reliability rather than raw detection count. Our next development step is to complete our Python-based SLAM mapping system and connect it with wall-focused path planning to inspect all important wall areas with minimum unnecessary travel.
Poster
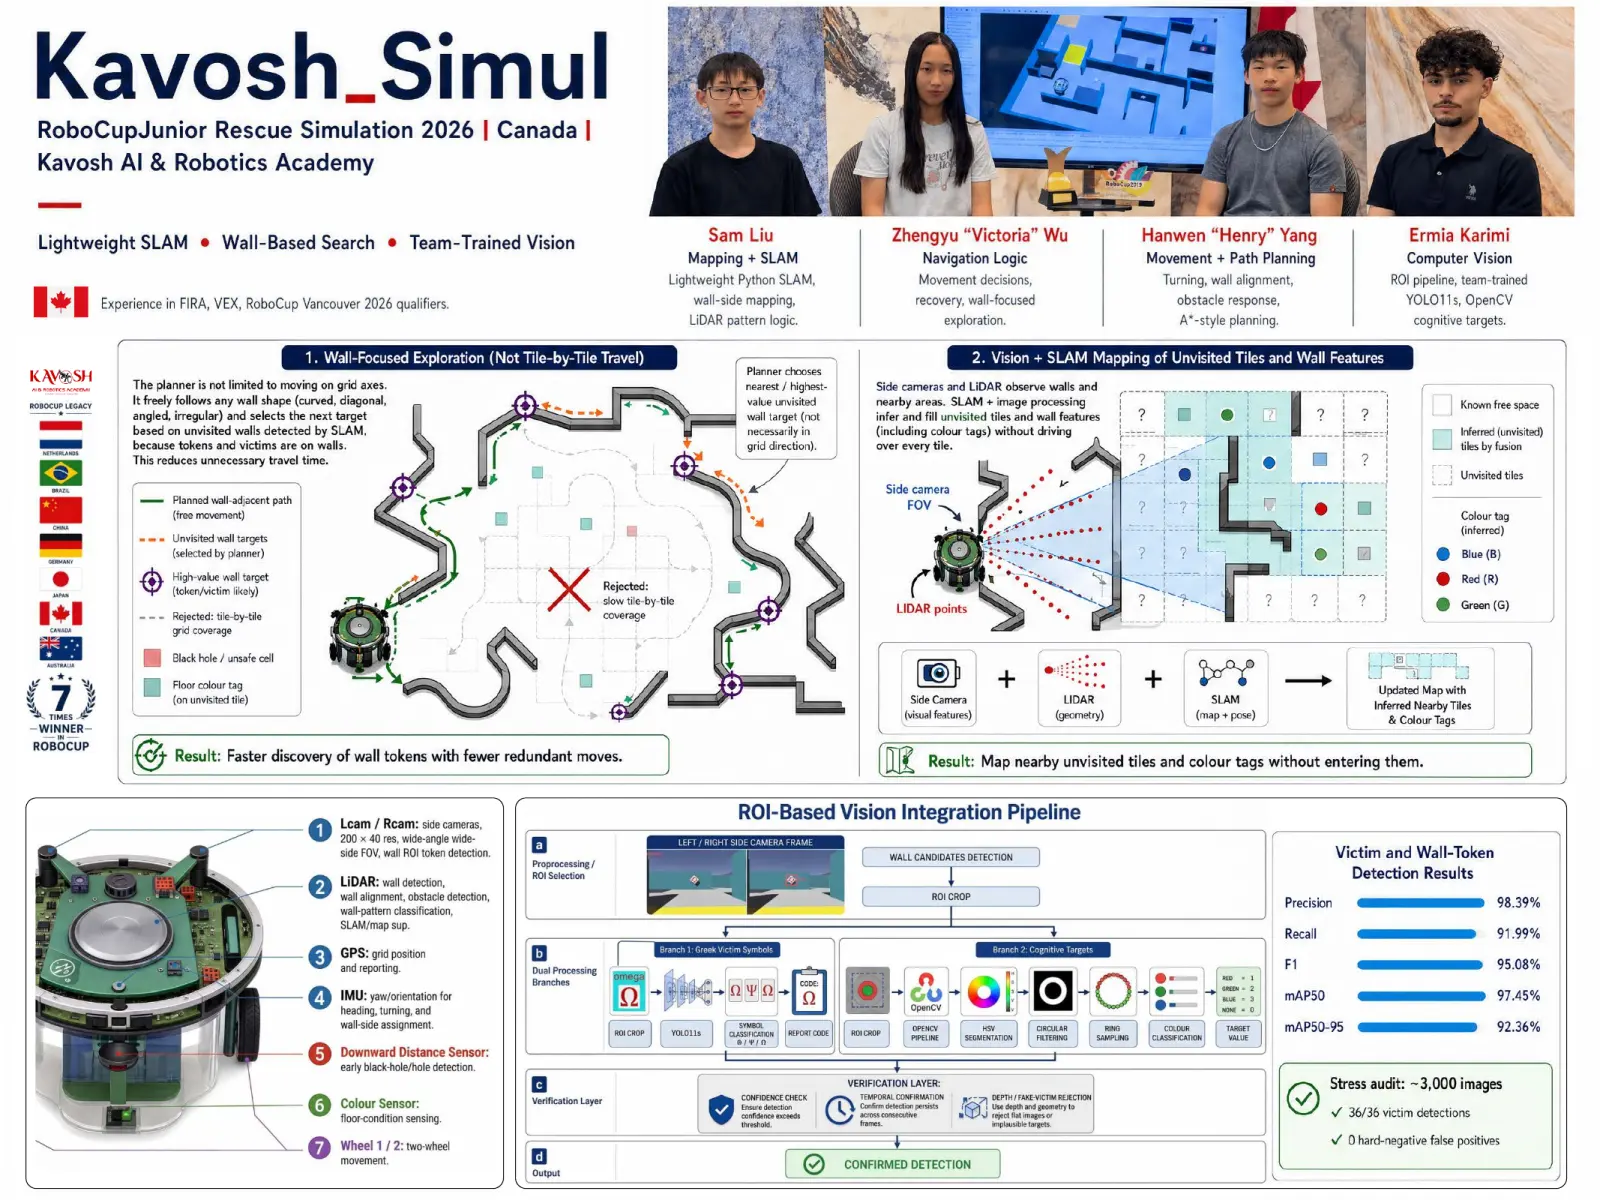
1 page, rendered as images so they load quickly. This document has no text layer — the words in it are part of the image.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.