
Top Class
Maze league · Republic of Korea ·
RoboCup 2026
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials75 KBPublished
- Team description paperNot shared
- Engineering journalNot shared
- Source code140 KB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
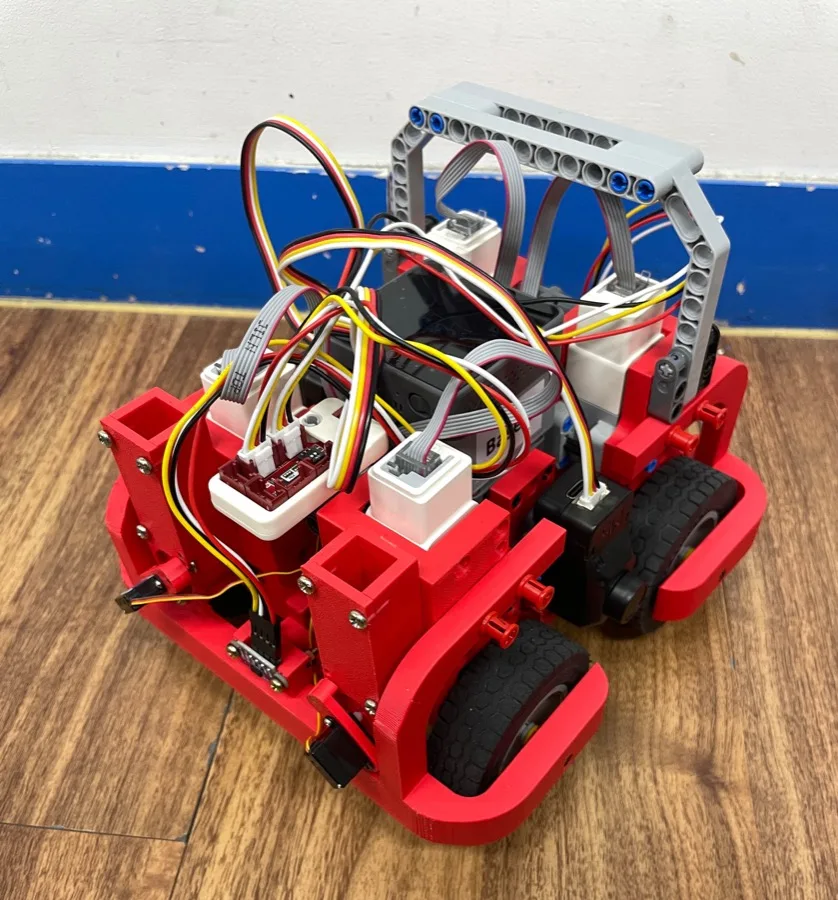
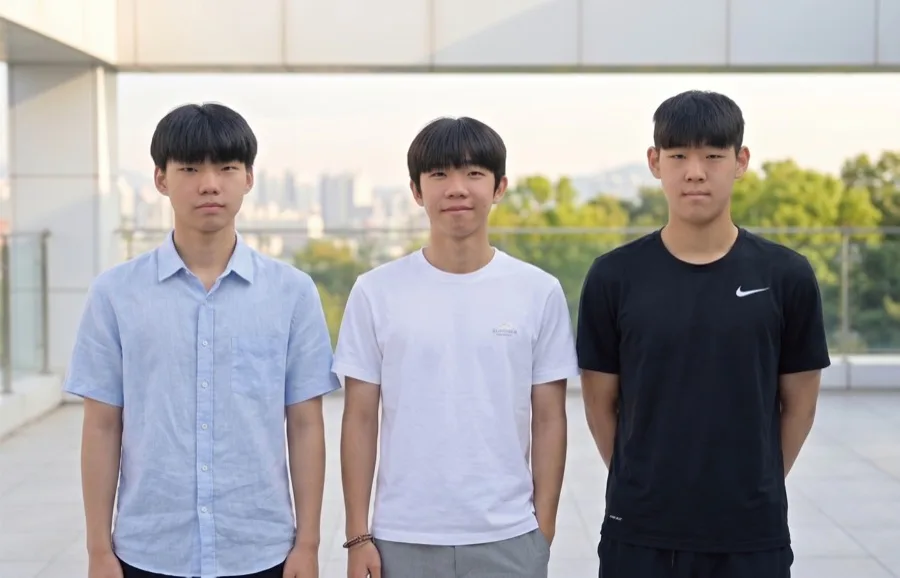
Poster
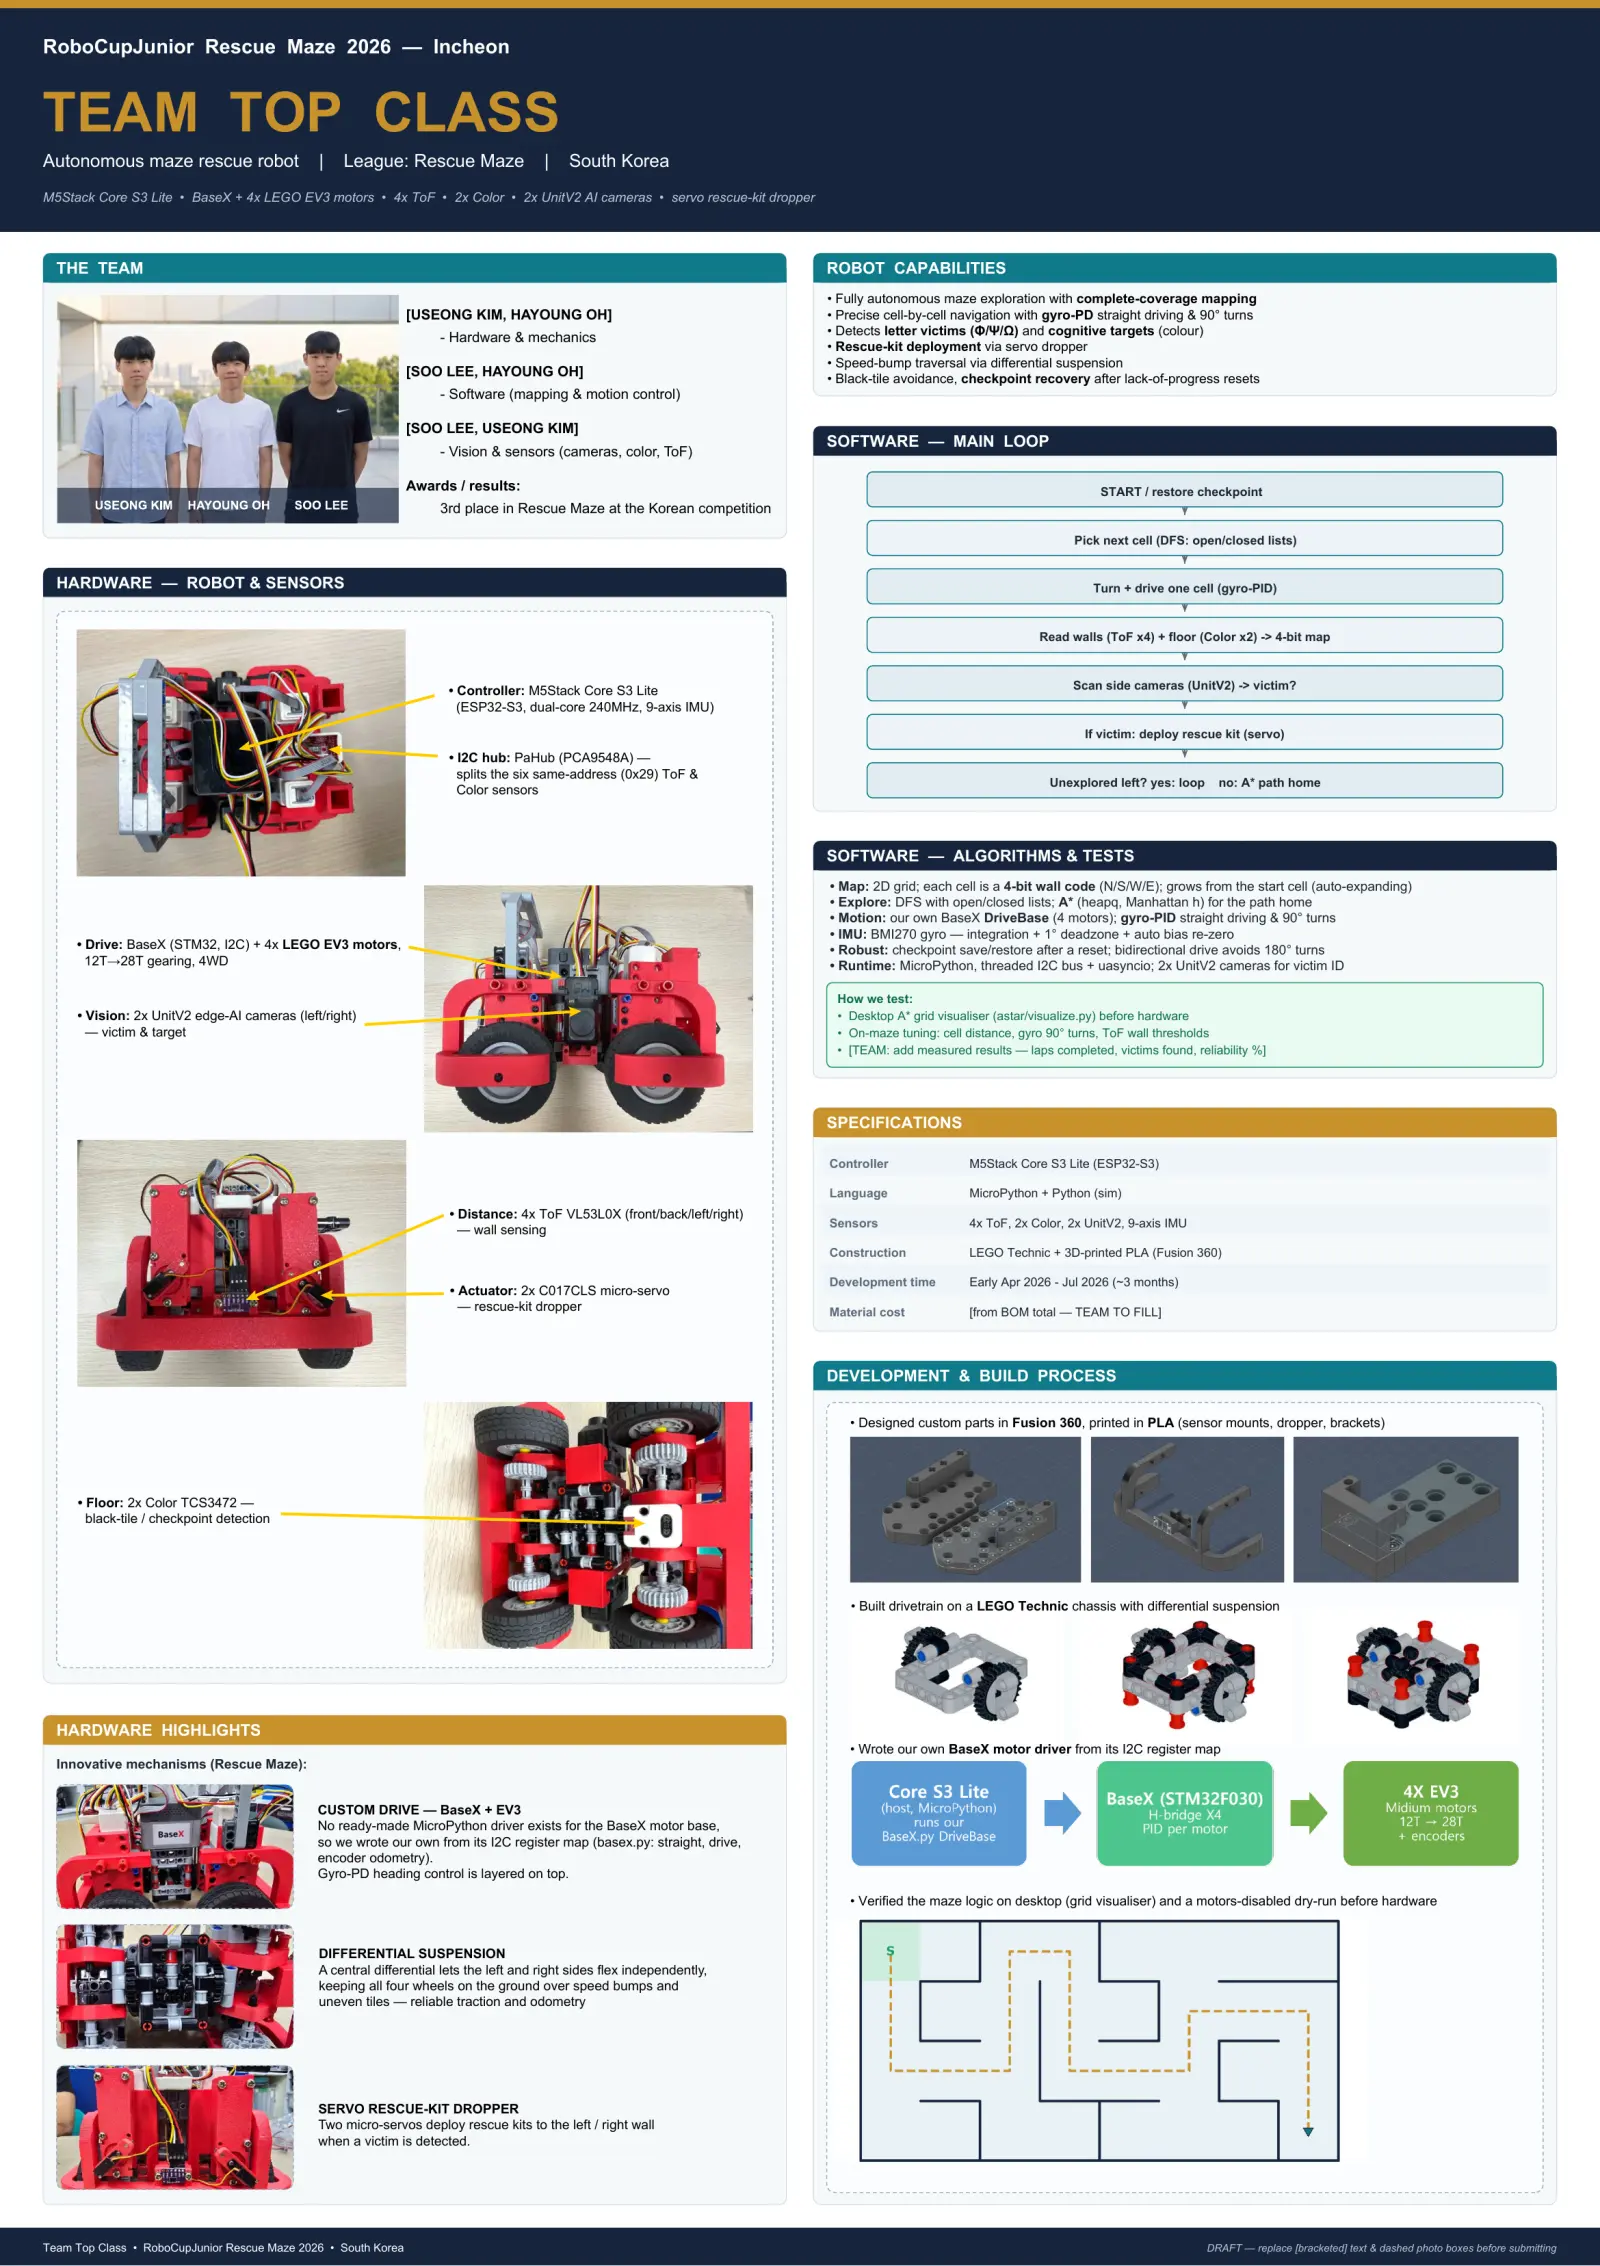
Read the text of this document — 622 words
RoboCupJunior Rescue Maze 2026 — Incheon
TEAM TOP CLASS
Autonomous maze rescue robot | League: Rescue Maze | South Korea
M5Stack Core S3 Lite • BaseX + 4x LEGO EV3 motors • 4x ToF • 2x Color • 2x UnitV2 AI cameras • servo rescue-kit dropper
THE TEAM ROBOT CAPABILITIES
• Fully autonomous maze exploration with complete-coverage mapping
[USEONG KIM, HAYOUNG OH] • Precise cell-by-cell navigation with gyro-PD straight driving & 90° turns
• Detects letter victims (Φ/Ψ/Ω) and cognitive targets (colour)
- Hardware & mechanics
• Rescue-kit deployment via servo dropper
• Speed-bump traversal via differential suspension
[SOO LEE, HAYOUNG OH] • Black-tile avoidance, checkpoint recovery after lack-of-progress resets
- Software (mapping & motion control)
[SOO LEE, USEONG KIM]
SOFTWARE — MAIN LOOP
- Vision & sensors (cameras, color, ToF)
Awards / results: START / restore checkpoint
3rd place in Rescue Maze at the Korean competition v
Pick next cell (DFS: open/closed lists)
v
HARDWARE — ROBOT & SENSORS Turn + drive one cell (gyro-PID)
v
Read walls (ToF x4) + floor (Color x2) -> 4-bit map
v
• Controller: M5Stack Core S3 Lite Scan side cameras (UnitV2) -> victim?
(ESP32-S3, dual-core 240MHz, 9-axis IMU) v
If victim: deploy rescue kit (servo)
v
• I2C hub: PaHub (PCA9548A) —
splits the six same-address (0x29) ToF &
Unexplored left? yes: loop no: A* path home
Color sensors
SOFTWARE — ALGORITHMS & TESTS
• Map: 2D grid; each cell is a 4-bit wall code (N/S/W/E); grows from the start cell (auto-expanding)
• Explore: DFS with open/closed lists; A* (heapq, Manhattan h) for the path home
• Motion: our own BaseX DriveBase (4 motors); gyro-PID straight driving & 90° turns
• IMU: BMI270 gyro — integration + 1° deadzone + auto bias re-zero
• Drive: BaseX (STM32, I2C) + 4x LEGO EV3 motors, • Robust: checkpoint save/restore after a reset; bidirectional drive avoids 180° turns
12T→28T gearing, 4WD • Runtime: MicroPython, threaded I2C bus + uasyncio; 2x UnitV2 cameras for victim ID
How we test:
• Vision: 2x UnitV2 edge-AI cameras (left/right) • Desktop A* grid visualiser (astar/visualize.py) before hardware
— victim & target • On-maze tuning: cell distance, gyro 90° turns, ToF wall thresholds
• [TEAM: add measured results — laps completed, victims found, reliability %]
SPECIFICATIONS
Controller M5Stack Core S3 Lite (ESP32-S3)
Language MicroPython + Python (sim)
• Distance: 4x ToF VL53L0X (front/back/left/right)
Sensors 4x ToF, 2x Color, 2x UnitV2, 9-axis IMU
— wall sensing
Construction LEGO Technic + 3D-printed PLA (Fusion 360)
Development time Early Apr 2026 - Jul 2026 (~3 months)
• Actuator: 2x C017CLS micro-servo
— rescue-kit dropper Material cost [from BOM total — TEAM TO FILL]
DEVELOPMENT & BUILD PROCESS
• Designed custom parts in Fusion 360, printed in PLA (sensor mounts, dropper, brackets)
• Floor: 2x Color TCS3472 —
black-tile / checkpoint detection
• Built drivetrain on a LEGO Technic chassis with differential suspension
HARDWARE HIGHLIGHTS
• Wrote our own BaseX motor driver from its I2C register map
Innovative mechanisms (Rescue Maze):
CUSTOM DRIVE — BaseX + EV3
No ready-made MicroPython driver exists for the BaseX motor base,
so we wrote our own from its I2C register map (basex.py: straight, drive,
encoder odometry).
Gyro-PD heading control is layered on top.
• Verified the maze logic on desktop (grid visualiser) and a motors-disabled dry-run before hardware
DIFFERENTIAL SUSPENSION
A central differential lets the left and right sides flex independently,
keeping all four wheels on the ground over speed bumps and
uneven tiles — reliable traction and odometry
SERVO RESCUE-KIT DROPPER
Two micro-servos deploy rescue kits to the left / right wall
when a victim is detected.
Team Top Class • RoboCupJunior Rescue Maze 2026 • South Korea DRAFT — replace [bracketed] text & dashed photo boxes before submitting
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Source code
The team's own source code, 140 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.