
Superteam Award

TOKAI Susano

Maze league · Japan · RoboCup 2026

Document register

  1. Poster1 pagePublished
  2. Presentation videoYouTubePublished
  3. Bill of materials79 KBPublished
  4. Team description paper584 KBPublished
  5. Engineering journal428 KBPublished
  6. Source code93 KB · GitHubPublished

Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
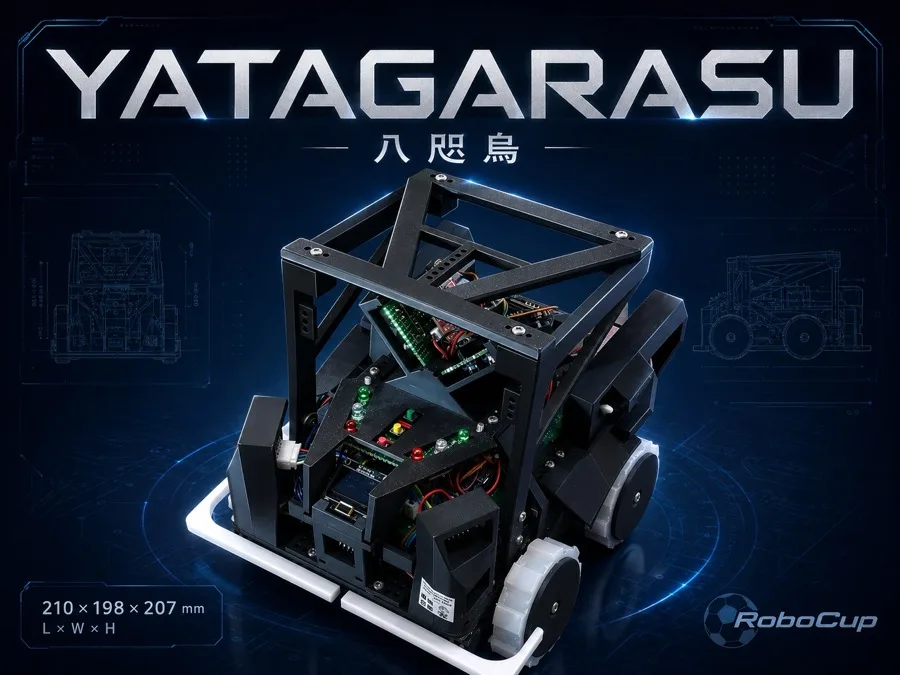
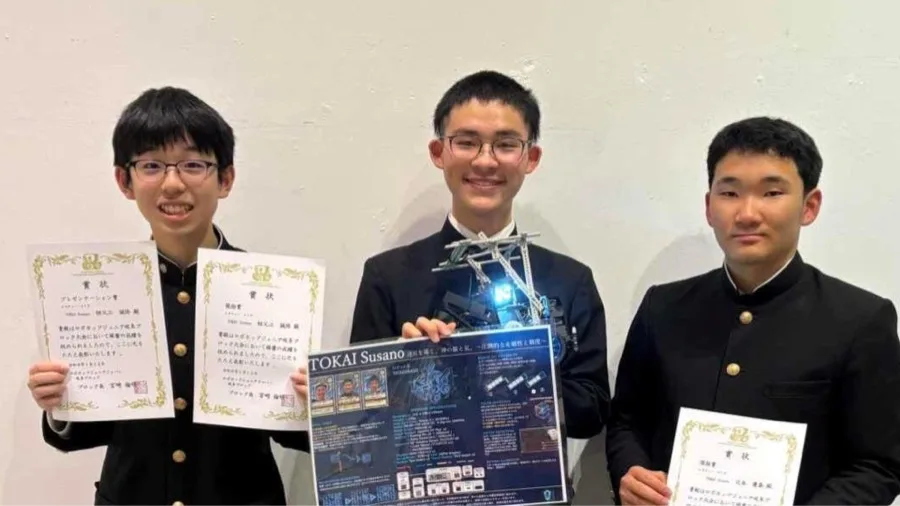
TOKAI Susano's robot
The TOKAI Susano team

In their words

TOKAI Susano is a team taking on RoboCupJunior Rescue Maze for the first time. Our initial goal was to place highly in the Japan Open, and through three prototypes we gradually developed stable driving, reliable exploration, victim detection, and rescue-kit deployment. The current robot combines a compact, low-center-of-gravity four-wheel-drive structure, self-made silicone tires, multiple ToF sensors, an IMU, a color sensor, and OpenMV cameras. In particular, we emphasized backup systems for dealing with errors and restarts during the competition, including tile-by-tile coordinate management, recording wall information, saving and restoring data with a microSD card, and coordinate matching after leaving the red zone. As a result, the robot has achieved a high return success rate in flat mazes and continues to be improved so that it can handle obstacles and multi-floor courses. This TDP describes TOKAI Susano's mechanical design, electronic design, software architecture, performance evaluation, and the problems encountered during development and how they were solved.

Poster
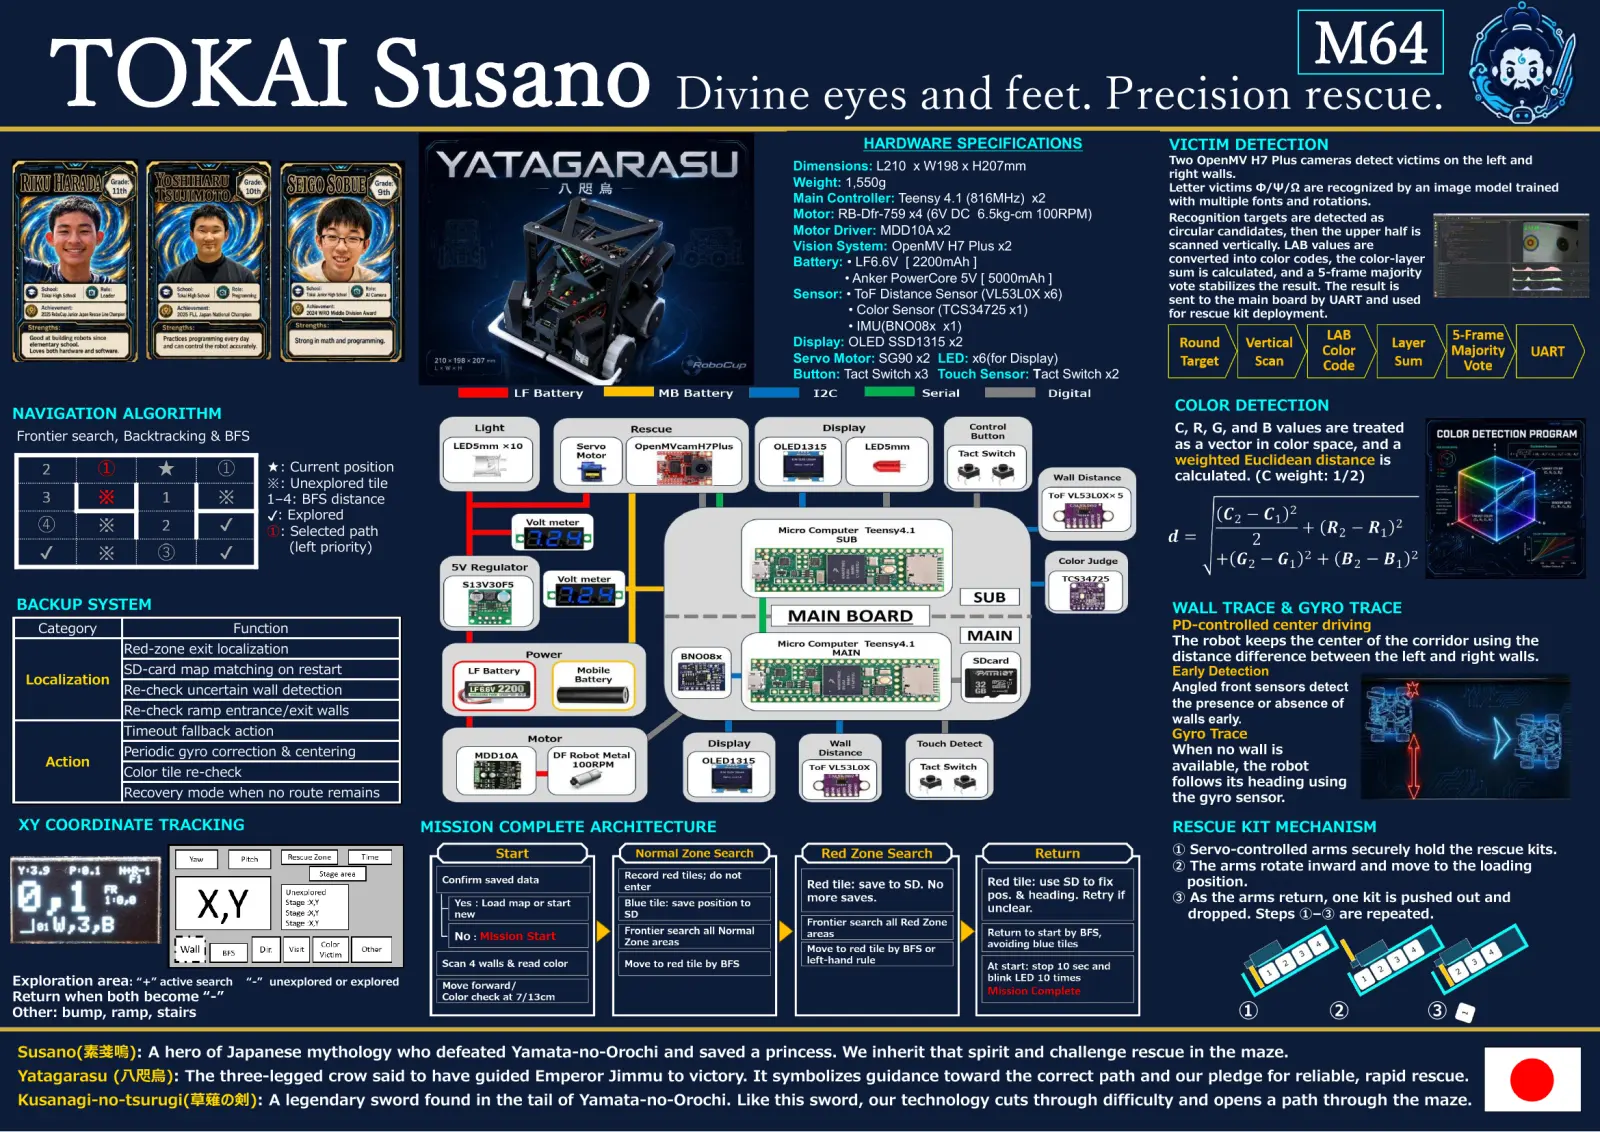
Read the text of this document — 453 words
M64
     TOKAI Susano Divine eyes and feet. Precision rescue.                                                      HARDWARE SPECIFICATIONS                    VICTIM DETECTION
                                                                                                                                                          Two OpenMV H7 Plus cameras detect victims on the left and
                                                                                                    Dimensions: L210 x W198 x H207mm
                                                                                                                                                          right walls.
                                                                                                    Weight: 1,550g                                        Letter victims Φ/Ψ/Ω are recognized by an image model trained
                                                                                                    Main Controller: Teensy 4.1 (816MHz) x2               with multiple fonts and rotations.
                                                                                                    Motor: RB-Dfr-759 x4 (6V DC 6.5kg-cm 100RPM)          Recognition targets are detected as
                                                                                                    Motor Driver: MDD10A x2                               circular candidates, then the upper half is
                                                                                                    Vision System: OpenMV H7 Plus x2                      scanned vertically. LAB values are
                                                                                                    Battery: • LF6.6V [ 2200mAh ]                         converted into color codes, the color-layer
                                                                                                                                                          sum is calculated, and a 5-frame majority
                                                                                                            • Anker PowerCore 5V [ 5000mAh ]
                                                                                                                                                          vote stabilizes the result. The result is
                                                                                                    Sensor: • ToF Distance Sensor (VL53L0X x6)            sent to the main board by UART and used
                                                                                                             • Color Sensor (TCS34725 x1)                 for rescue kit deployment.
                                                                                                             • IMU(BNO08x x1)
                                                                                                    Display: OLED SSD1315 x2
                                                                                                    Servo Motor: SG90 x2 LED: x6(for Display)
                                                                                                    Button: Tact Switch x3 Touch Sensor: Tact Switch x2

                                                                                                                                                          COLOR DETECTION
NAVIGATION ALGORITHM
                                                                                                                                                          C, R, G, and B values are treated
Frontier search, Backtracking & BFS
                                                                                                                                                          as a vector in color space, and a
                                                                                                                                                          weighted Euclidean distance is
                                          ★: Current position
                                                                                                                                                          calculated. (C weight: 1/2)
                                          ※: Unexplored tile
                                          1–4: BFS distance
                                           : Explored
                                          ①: Selected path
                                             (left priority)

BACKUP SYSTEM                                                                                                                                             WALL TRACE & GYRO TRACE
    Category                          Function                                                                                                            PD-controlled center driving
                                                                                                                                                          The robot keeps the center of the corridor using the
                 Red-zone exit localization
                                                                                                                                                          distance difference between the left and right walls.
                 SD-card map matching on restart                                                                                                          Early Detection
  Localization
                 Re-check uncertain wall detection                                                                                                        Angled front sensors detect
                                                                                                                                                          the presence or absence of
                 Re-check ramp entrance/exit walls
                                                                                                                                                          walls early.
                 Timeout fallback action                                                                                                                  Gyro Trace
                 Periodic gyro correction & centering                                                                                                     When no wall is
     Action                                                                                                                                               available, the robot
                 Color tile re-check
                                                                                                                                                          follows its heading using
                 Recovery mode when no route remains                                                                                                      the gyro sensor.

XY COORDINATE TRACKING                                              MISSION COMPLETE ARCHITECTURE                                                         RESCUE KIT MECHANISM
                                                                                                                                                          ① Servo-controlled arms securely hold the rescue kits.
                                                                                                                                                          ② The arms rotate inward and move to the loading
                                                                                                                                                           position.
                                                                                                                                                          ③ As the arms return, one kit is pushed out and
                                                                                                                                                            dropped. Steps ①–③ are repeated.

Exploration area: “+” active search    “-” unexplored or explored
Return when both become “-”
Other: bump, ramp, stairs                                                                                                                                           ➀              ➁              ➂
Susano(素戔嗚): A hero of Japanese mythology who defeated Yamata-no-Orochi and saved a princess. We inherit that spirit and challenge rescue in the maze.
Yatagarasu (八咫烏): The three-legged crow said to have guided Emperor Jimmu to victory. It symbolizes guidance toward the correct path and our pledge for reliable, rapid rescue.
Kusanagi-no-tsurugi(草薙の剣): A legendary sword found in the tail of Yamata-no-Orochi. Like this sword, our technology cuts through difficulty and opens a path through the maze.

Open as plain text

1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.

Download the original PDF (1,009 KB) from GitHub

Presentation video

Hosted on YouTube. The player loads only when you press play.

Open in YouTube

Bill of materials

Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.

Open Bill of materials

Team description paper

Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.

Open Team description paper

Engineering journal

Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.

Open Engineering journal

Source code

The team's own source code, 93 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.

Download TOKAI Susano's source code