
Simple
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials221 KBPublished
- Team description paper710 KBPublished
- Engineering journal427 KBPublished
- Source code35 KB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
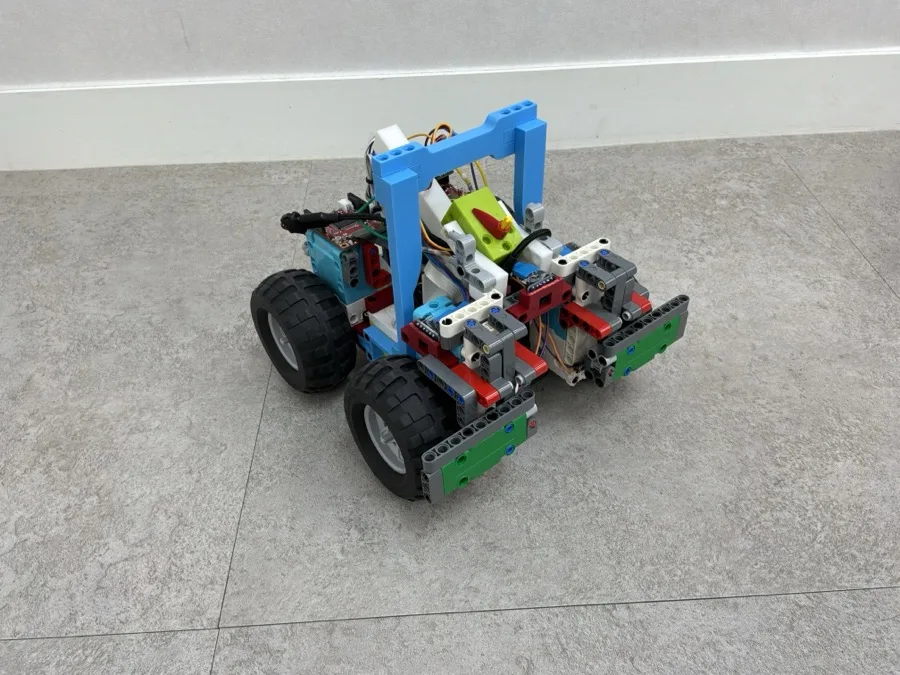
Our articulated rescue robot combines SPIKE Prime and OpenMV control, rule-based vision, adaptive mapping, and a bidirectional rescue-kit dispenser for fast and reliable maze navigation.
Poster
Read the text of this document — 172 words
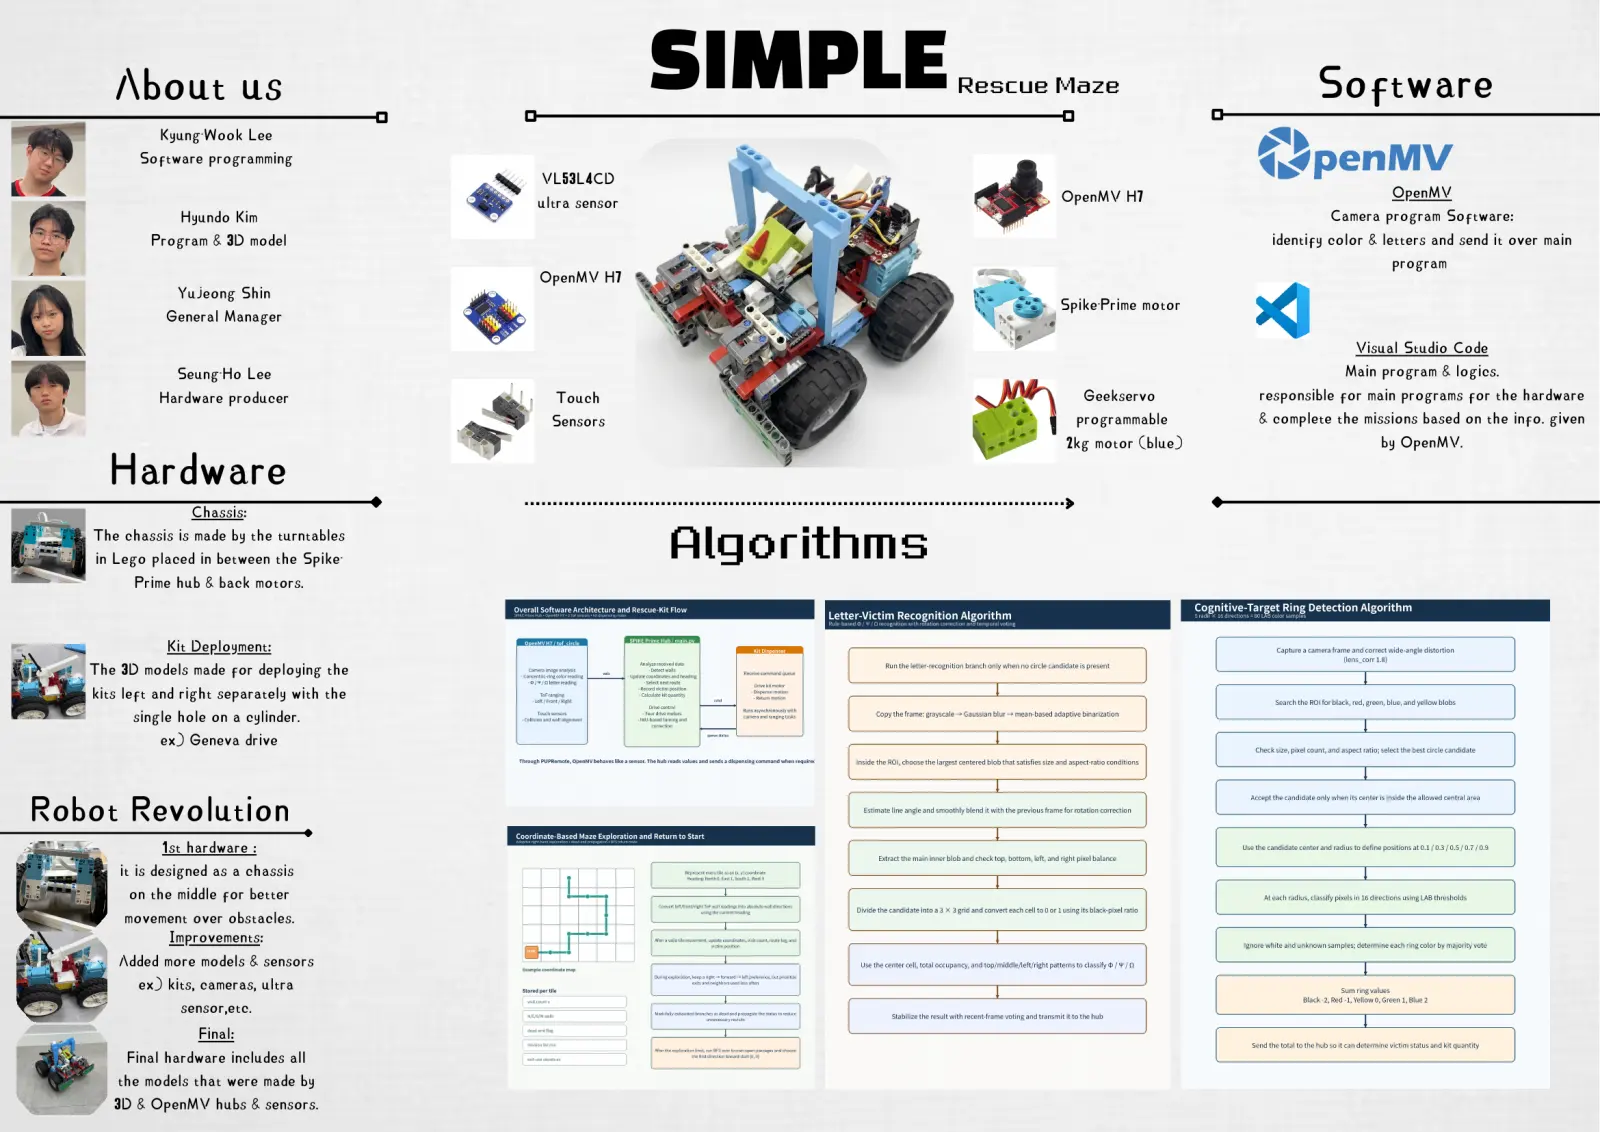
About us                                              SIMPLE       Rescue Maze                       Software
            Kyung-Wook Lee
          Software programming
                                             VL53L4CD
                                                                                OpenMV H7                              OpenMV
                                             ultra sensor
               Hyundo Kim                                                                                    Camera program Software:
            Program & 3D model                                                                      identify color & letters and send it over main
                                                                                                                       program
                                             OpenMV H7
               Yujeong Shin
                                                                               Spike-Prime motor
              General Manager
                                                                                                                 Visual Studio Code
               Seung-Ho Lee                                                                                     Main program & logics.
             Hardware producer                 Touch                              Geekservo        responsible for main programs for the hardware
                                               Sensors                           programmable      & complete the missions based on the info. given
                                                                                2kg motor (blue)                     by OpenMV.

     Hardware
                 Chassis:
   The chassis is made by the turntables
   in Lego placed in between the Spike-                     Algorithms
         Prime hub & back motors.

               Kit Deployment:
   The 3D models made for deploying the
   kits left and right separately with the
          single hole on a cylinder.
              ex) Geneva drive

Robot Revolution
               1st hardware :
       it is designed as a chassis
         on the middle for better
        movement over obstacles.
                Improvements:
       Added more models & sensors
           ex) kits, cameras, ultra
                  sensor,etc.
                   Final:
        Final hardware includes all
       the models that were made by
      3D & OpenMV hubs & sensors.
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Shown as the original PDF: this document could not be rendered as images, so the file itself is what the page offers.
Team description paper
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Engineering journal
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Source code
The team's own source code, 35 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.