
RRR Kabelmüsli
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials77 KBPublished
- Team description paper359 KBPublished
- Engineering journalNot shared
- Source codeNot shared
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
Side Note: The web version of our TDP uploaded in these input fields is significantly simplified and does not meet all requirements. Please refer to the main PDF file instead. Thank you for your understanding.
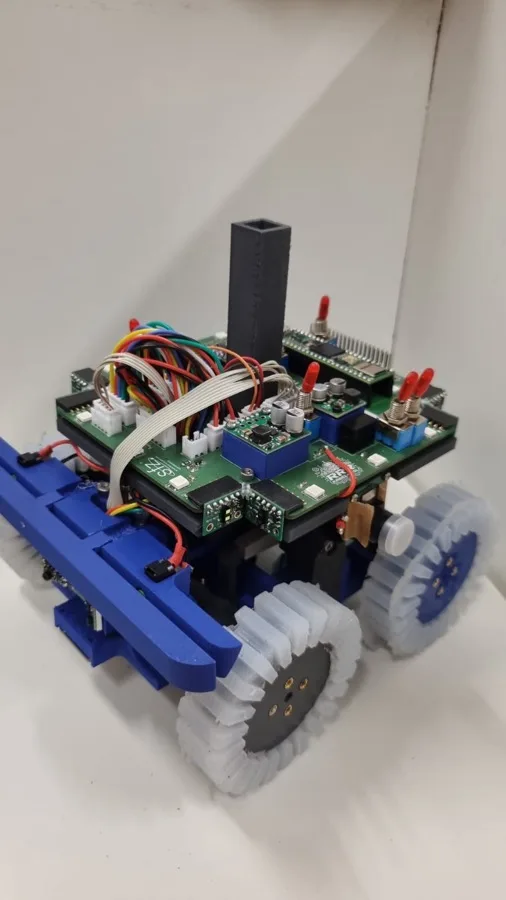
We built a completely new RoboCupJunior Rescue Maze robot for the 2026 season. The goal was a compact, competition-ready platform with higher consistency and better integration than our earlier robots. Compared to previous seasons, this build replaces a cable-heavy architecture with a central custom PCB, a tighter mechanical package, and a cleaner split between embedded sensing, Raspberry Pi decision making, and telemetry.
Our robot uses four driven wheels, a passive suspension based on coupled rocking axles, custom cast silicone tires, eight side-facing VL53L1X distance sensors, three forward multi-target ToF sensors, RGB and reflectance floor sensing, dual ultra-wide-angle victim cameras, and a directional rescue-kit mechanism. The software stack combines live sensor fusion, a three-dimensional tile map, shortest-path navigation, persistent silver checkpoint recovery, dual-model victim recognition, and a local dashboard.
This paper focuses on the design rationale, the integration strategy, and the validation loops that shaped the final system. Special attention is given to compact packaging, maintainability, checkpoint recovery, and synthetic-data victim training.
Poster
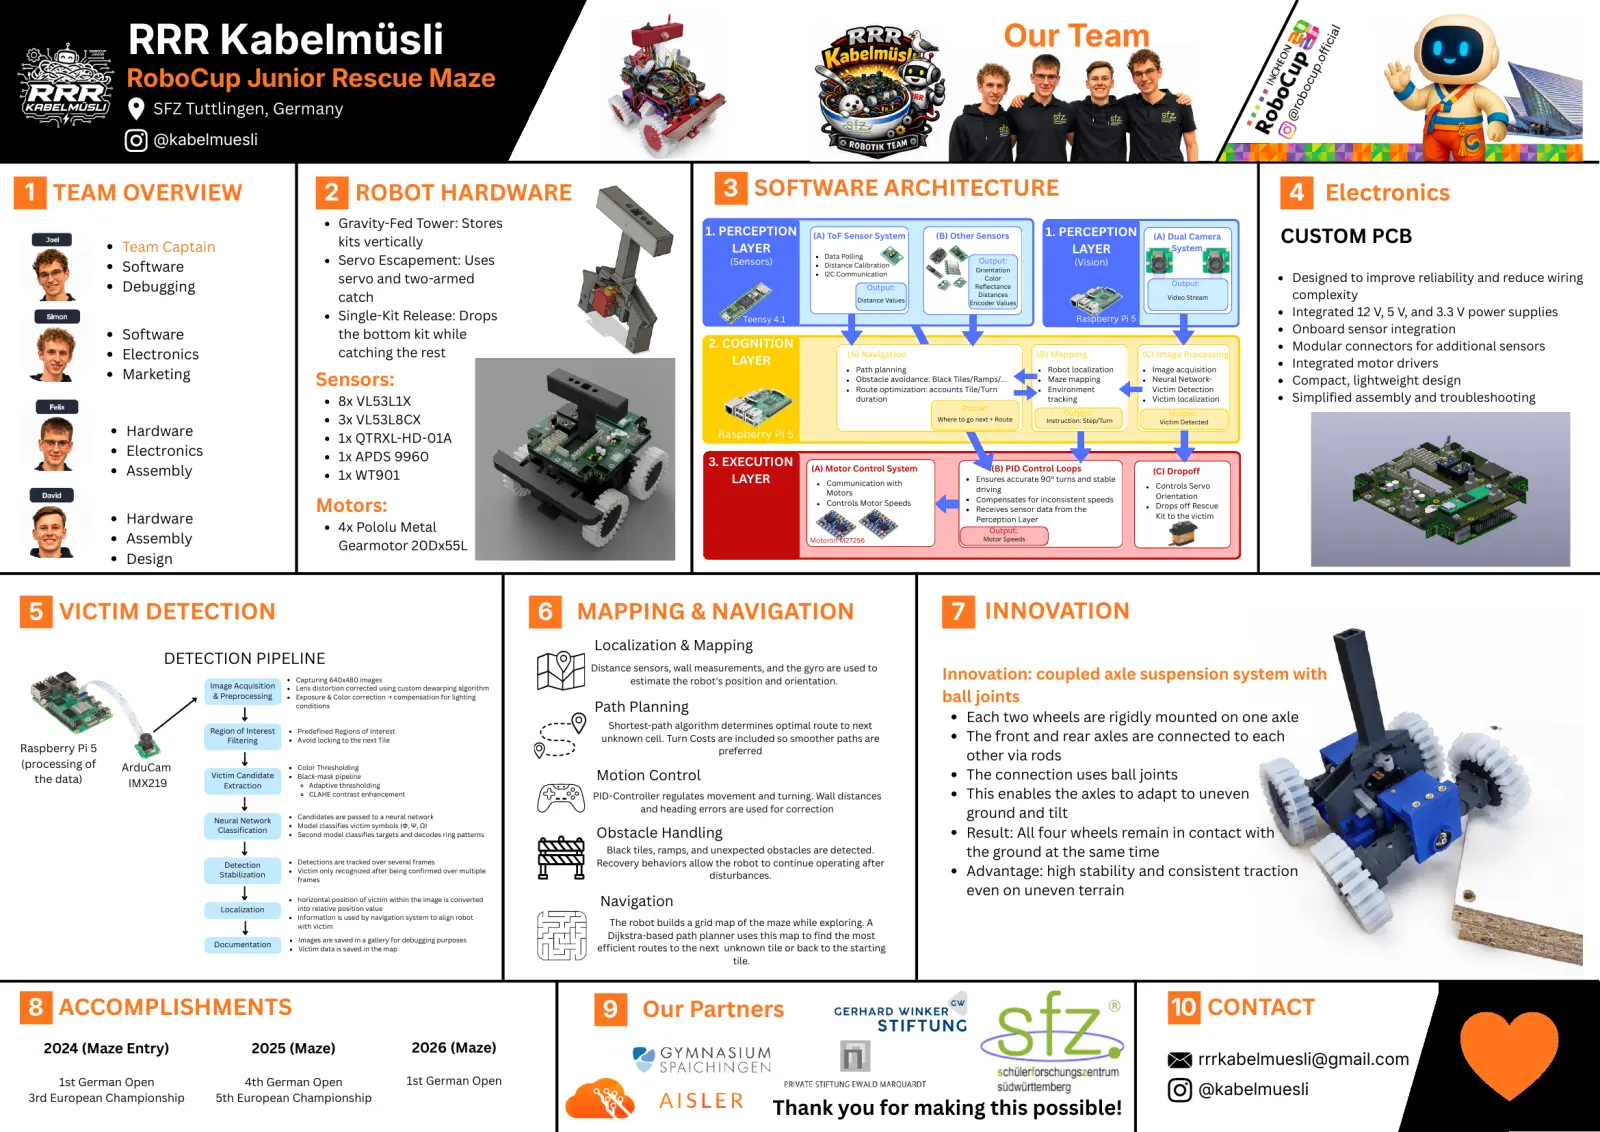
Read the text of this document — 637 words
RRR Kabelmüsli Our Team
ial
fic
.of
RoboCup Junior Rescue Maze
up
oc
ob
SFZ Tuttlingen, Germany
@r
@kabelmuesli
1 TEAM OVERVIEW 2 ROBOT HARDWARE 3 SOFTWARE ARCHITECTURE 4 Electronics
Gravity-Fed Tower: Stores
Team Captain kits vertically
1. PERCEPTION (A) ToF Sensor System (B) Other Sensors 1. PERCEPTION (A) Dual Camera CUSTOM PCB
LAYER LAYER System
Software Servo Escapement: Uses (Sensors)
Data Polling
Distance Calibration
Output: (Vision)
Orientation
servo and two-armed
I2C Communication
Color Designed to improve reliability and reduce wiring
Debugging Output: Reflectance Output:
catch Distance Values
Distances
Encoder Values
Video Stream complexity
Single-Kit Release: Drops Teensy 4.1 Raspberry Pi 5
Integrated 12 V, 5 V, and 3.3 V power supplies
Software the bottom kit while Onboard sensor integration
2. COGNITION Modular connectors for additional sensors
Electronics catching the rest (A) Navigation (B) Mapping (C) Image Processing
LAYER Integrated motor drivers
Path planning Robot localization Image acquisition
Marketing Sensors: Obstacle avoidance: Black Tiles/Ramps/... Maze mapping Neural Network- Compact, lightweight design
Route optimization: accounts Tile/Turn Environment Victim Detection
8x VL53L1X duration tracking Victim localization Simplified assembly and troubleshooting
Output:
Output: Output:
3x VL53L8CX Where to go next + Route Instruction: Step/Turn Victim Detected
Hardware 1x QTRXL-HD-01A Raspberry Pi 5
Electronics 1x APDS 9960 3. EXECUTION
Assembly 1x WT901
(A) Motor Control System (B) PID Control Loops (C) Dropoff
LAYER Communication with
Ensures accurate 90° turns and stable
Controls Servo
Motors driving
Orientation
Motors: Controls Motor Speeds Compensates for inconsistent speeds
Receives sensor data from the Drops off Rescue
Hardware Perception Layer Kit to the victim
4x Pololu Metal Output:
Assembly Gearmotor 20Dx55L
Motoron M2T256 Motor Speeds
Design
5 VICTIM DETECTION 6 MAPPING & NAVIGATION 7 INNOVATION
Localization & Mapping
DETECTION PIPELINE Distance sensors, wall measurements, and the gyro are used to
Capturing 640x480 images estimate the robot's position and orientation. Innovation: coupled axle suspension system with
Image Acquisition Lens distortion corrected using custom dewarping algorithm
& Preprocessing Exposure & Color correction → compensation for lighting ball joints
conditions Path Planning
Shortest-path algorithm determines optimal route to next
Each two wheels are rigidly mounted on one axle
Region of Interest
The front and rear axles are connected to each
Predefined Regions of Interest
Filtering Avoid locking to the next Tile unknown cell. Turn Costs are included so smoother paths are
Raspberry Pi 5 preferred
other via rods
(processing of ArduCam Color Thresholding
the data) Victim Candidate Black-mask pipeline Motion Control The connection uses ball joints
IMX219 Extraction Adaptive thresholding
CLAHE contrast enhancement PID-Controller regulates movement and turning. Wall distances This enables the axles to adapt to uneven
and heading errors are used for correction
Neural Network
Candidates are passed to a neural network ground and tilt
Model classifies victim symbols (Φ, Ψ, Ω)
Classification
Second model classifies targets and decodes ring patterns Obstacle Handling Result: All four wheels remain in contact with
Black tiles, ramps, and unexpected obstacles are detected. the ground at the same time
Detection Detections are tracked over several frames Recovery behaviors allow the robot to continue operating after
Stabilization
Victim only recognized after being confirmed over multiple
frames disturbances. Advantage: high stability and consistent traction
even on uneven terrain
Localization
horizontal position of victim within the image is converted
into relative position value
Navigation
Information is used by navigation system to align robot
with victim The robot builds a grid map of the maze while exploring. A
Images are saved in a gallery for debugging purposes
Dijkstra-based path planner uses this map to find the most
Documentation
Victim data is saved in the map efficient routes to the next unknown tile or back to the starting
tile.
8 ACCOMPLISHMENTS 9 Our Partners 10 CONTACT
2024 (Maze Entry) 2025 (Maze) 2026 (Maze)
rrrkabelmuesli@gmail.com
1st German Open 4th German Open 1st German Open
3rd European Championship 5th European Championship
@kabelmuesli
Thank you for making this possible!
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Team description paper
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.