
PRIMEX FCoEE
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials65 KBPublished
- Team description paper622 KBPublished
- Engineering journalNot shared
- Source code7.7 MB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
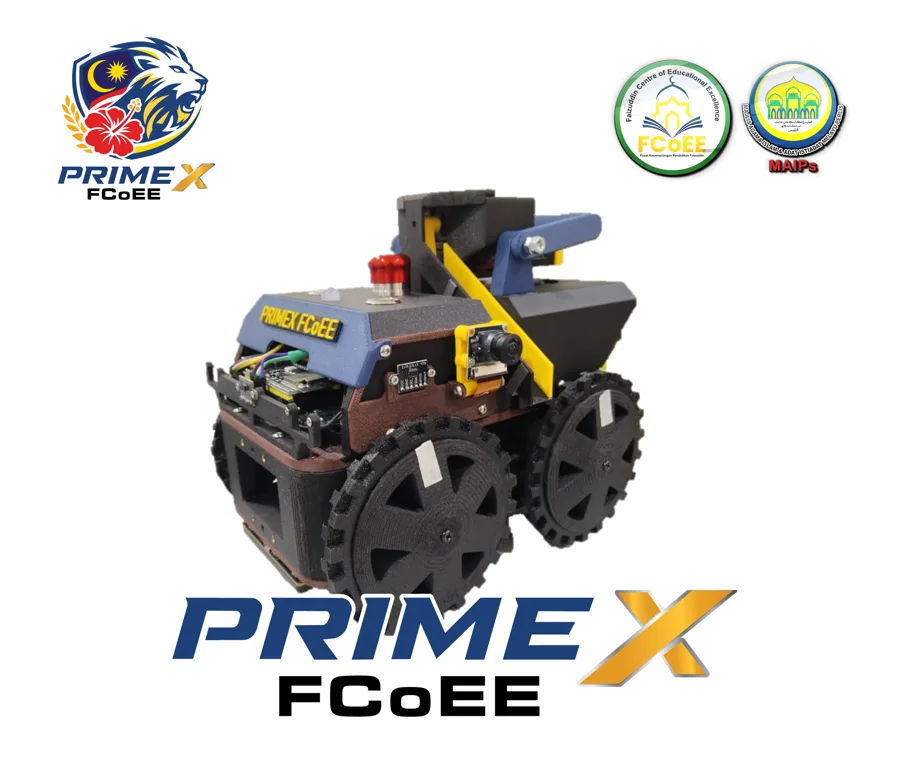
PRIMEX FCoEE is a fully autonomous maze-solving rescue robot developed by a student team from the Faizuddin Center of Educational Excellence (FCoEE) for the RoboCupJunior Rescue Maze 2026 competition. The robot is built on a dual-processor architecture, with a Jetson Orin Nano handling all vision and navigation decisions and an ESP32-S3 managing real-time motor and actuator control, mounted on a fully custom chassis 3D-printed using engineering-grade carbon fiber reinforced materials (ABS-CF and PETG-CF) for structural rigidity and durability under field conditions. The robot explores unknown mazes autonomously using a Right-Hand Rule algorithm with real-time 2D grid mapping, requiring no pre-mapping and no hardcoded field logic. It detects two types of victims. The first victim is Greek letter victims (Φ, Ψ, Ω) using a custom TensorFlow deep learning model trained on a manually captured dataset covering varied angles, distances, and lighting, achieving 90% accuracy. The second victim is cognitive targets, detected using outermost-circle-first template strategy that anchors inner ring boundaries and computes the health status sum from color values, achieving 80% ring layer detection and 90% per-ring color classification. Floor tile types are reliably identified by a downward-facing mBot2 color sensor with local calibration performed before each run, allowing the robot to adapt to changing venue lighting conditions.
The full system integrates high-performance hardware, autonomous maze navigation, trained letter victim detection, template-based cognitive target detection, and adaptive floor color sensing into a single cohesive whole. The combination reflects the team's commitment to building a robot that is not only technically capable across every scoring dimension of the competition, but also robust and consistent under real field conditions.
Poster
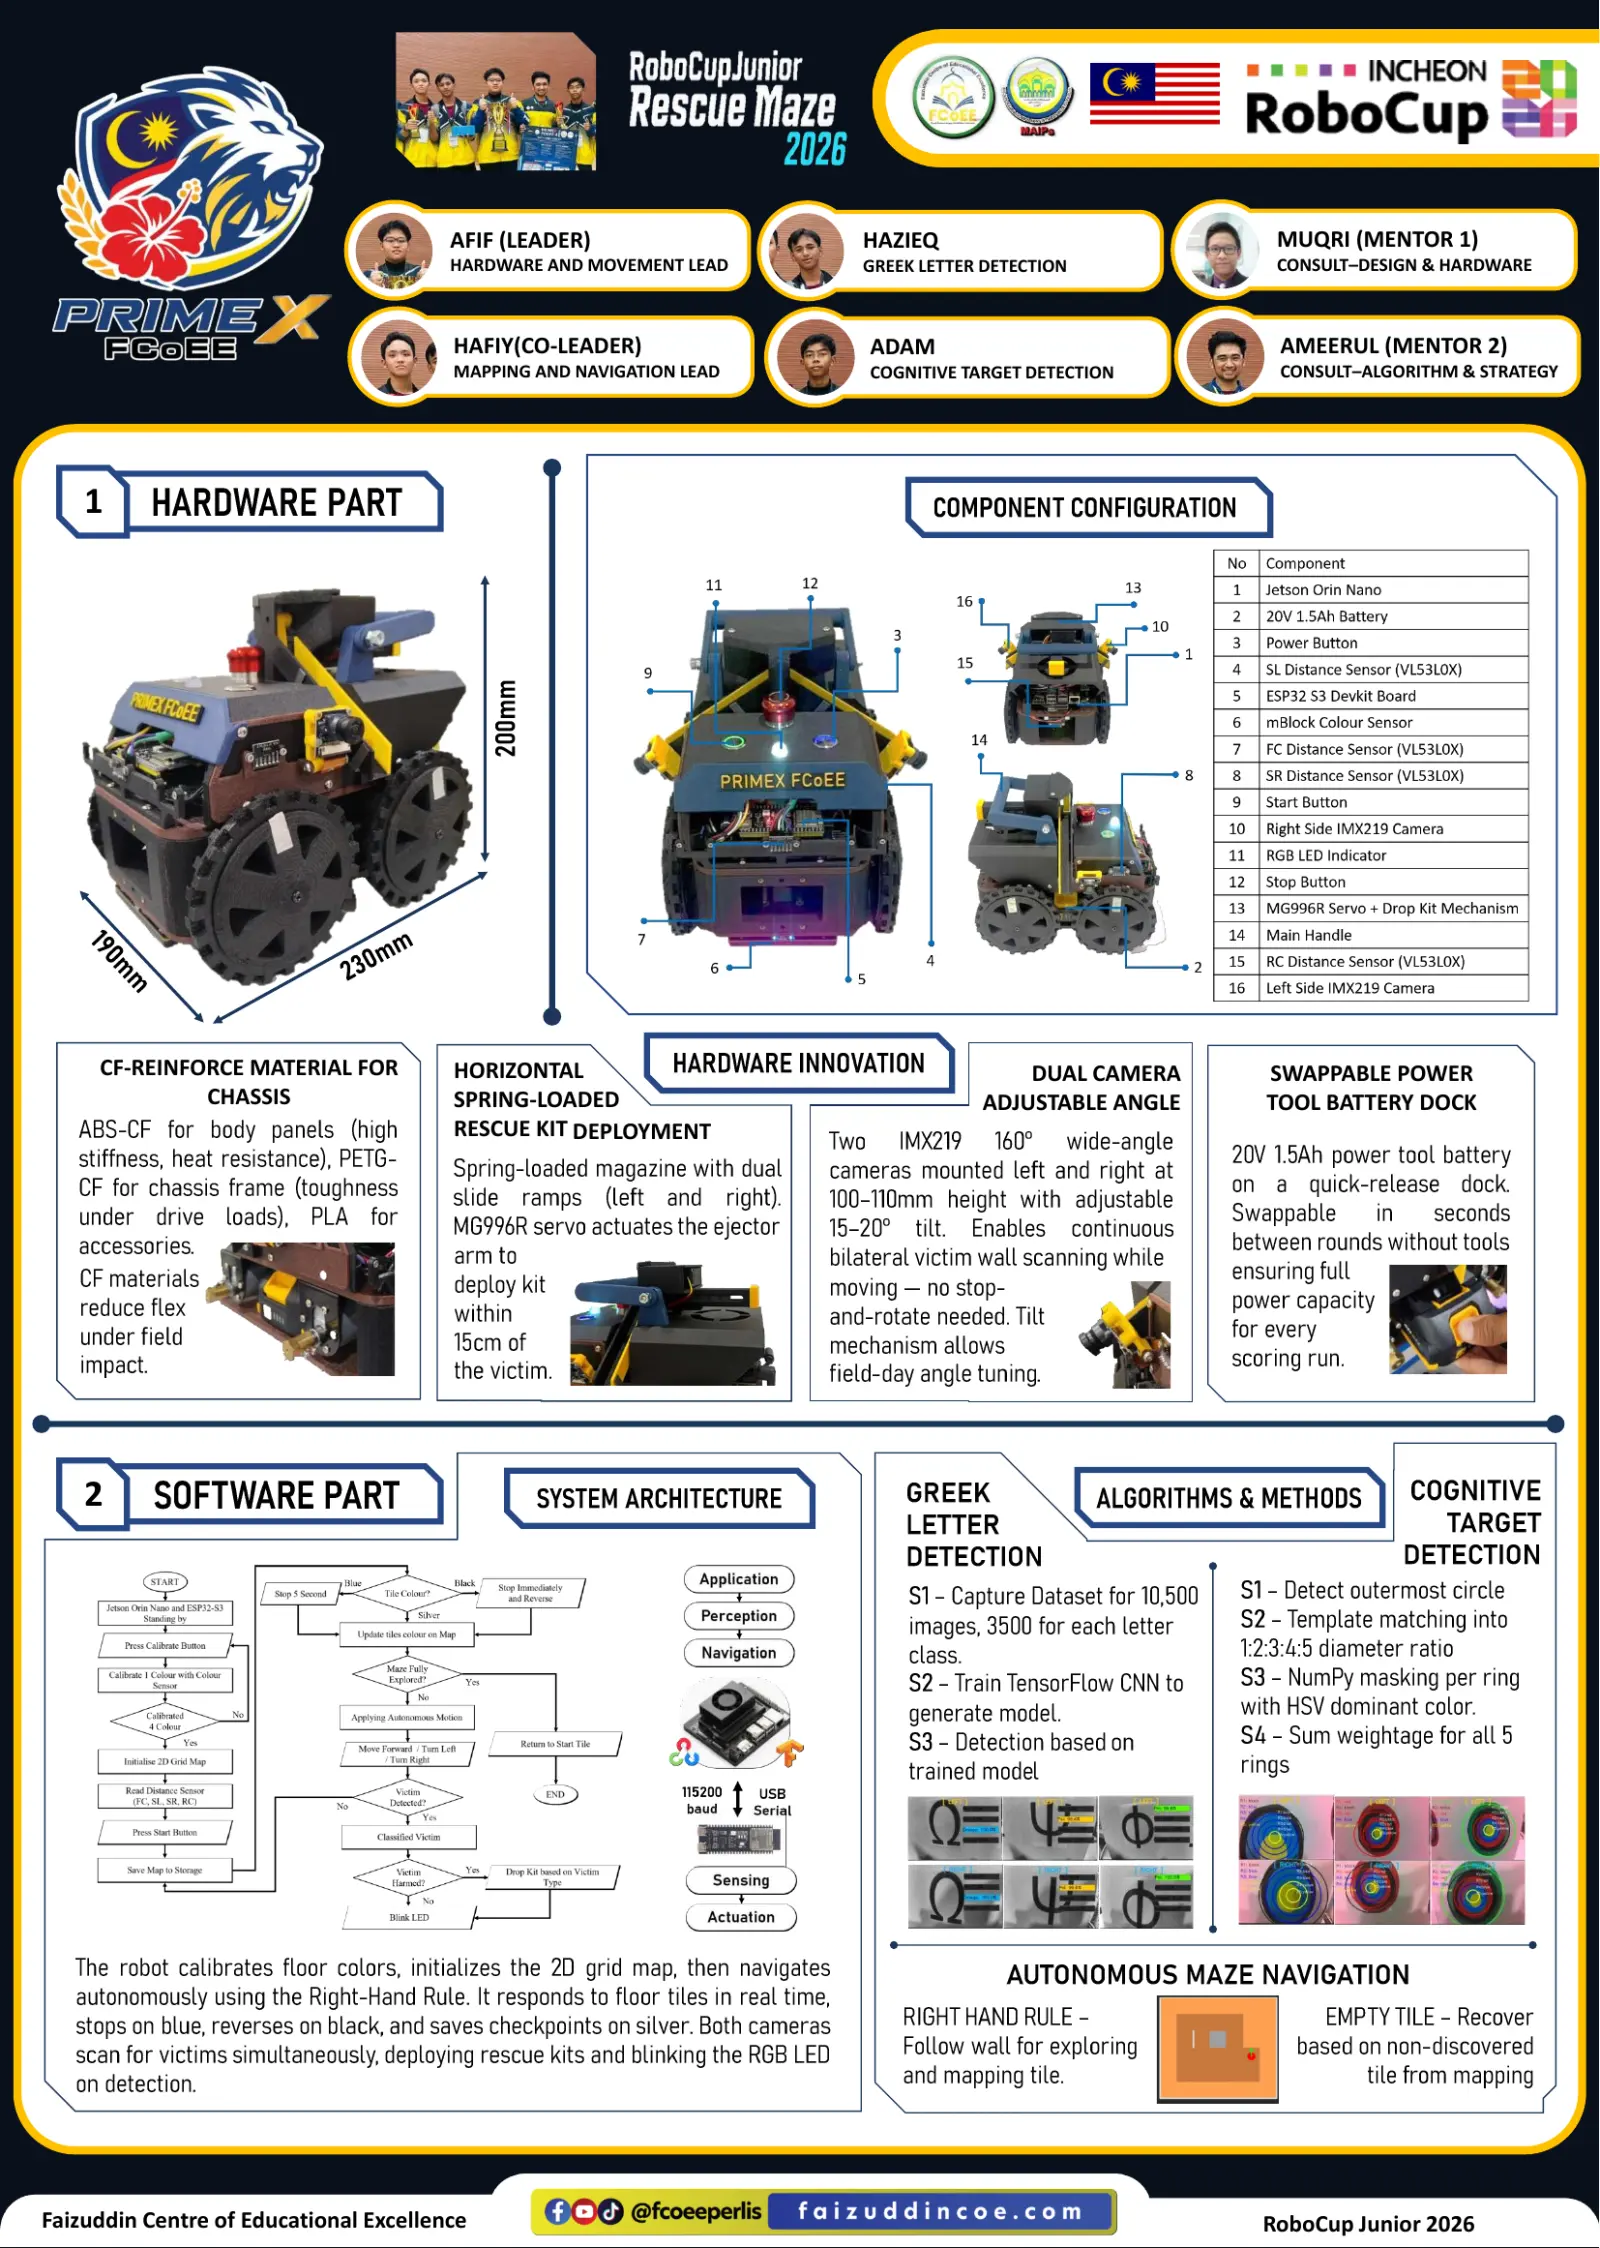
Read the text of this document — 321 words
AFIF (LEADER)                               HAZIEQ                                    MUQRI (MENTOR 1)
                                          HARDWARE AND MOVEMENT LEAD                  GREEK LETTER DETECTION                    CONSULT–DESIGN & HARDWARE

                                          HAFIY(CO-LEADER)                            ADAM                                      AMEERUL (MENTOR 2)
                                          MAPPING AND NAVIGATION LEAD                 COGNITIVE TARGET DETECTION                CONSULT–ALGORITHM & STRATEGY

    1     HARDWARE PART                        200mm                                         COMPONENT
                                                                                                     CONFIGURATION

      CF-REINFORCE MATERIAL FOR           HORIZONTAL        HARDWARE INNOVATION      DUAL CAMERA                               SWAPPABLE POWER
                 CHASSIS                  SPRING-LOADED                          ADJUSTABLE ANGLE                              TOOL BATTERY DOCK
   ABS- CF for body panels (high          RESCUE KIT DEPLOYMENT
                                                                      Two IMX219 160° wide- angle
   stiffness, heat resistance), PETG-                                                                                       20V 1.5Ah power tool battery
                                          Spring- loaded magazine with dual       cameras mounted left and right at
   CF for chassis frame (toughness                                                                                          on a quick- release dock.
                                          slide ramps (left and right).           100–110mm height with adjustable
   under drive loads), PLA for                                                                                              Swappable     in   seconds
                                          MG996R servo actuates the ejector       15–20° tilt. Enables continuous
   accessories.                                                                                                             betweenrounds withouttools
                                          arm to                                  bilateral victim wall scanning while
   CF materials                                                                                                             ensuring full
                                          deploy kit                              moving — no stop-
   reduce flex                                                                                                              power capacity
                                          within                                  and- rotate needed. Tilt
   under field                                                                                                              for every
                                          15cm of                                 mechanism allows
   impact.                                the victim.                                                                       scoring run.
                                                                                  field- day angle tuning.

    2      SOFTWARE PART                               SYSTEM ARCHITECTURE                GREEK                ALGORITHMS & METHODS COGNITIVE
                                                                                          LETTER                                       TARGET
                                                                                          DETECTION                                 DETECTION
                                                                                          S1 – Capture Dataset for 10,500   S1 – Detect outermost circle
                                                                                          images, 3500 for each letter      S2 – Template matching into
                                                                                          class.                            1:2:3:4:5 diameter ratio
                                                                                          S2 – Train TensorFlow CNN to      S3 – NumPy masking per ring
                                                                                          generate model.                   with HSV dominant color.
                                                                                          S3 – Detectionbased on            S4 – Sum weightage for all 5
                                                                                          trained model                     rings

   The robot calibrates floor colors, initializes the 2D grid map, then navigates                    AUTONOMOUS MAZE NAVIGATION
   autonomouslyusing the Right- Hand Rule. It responds to floor tiles in real time,
   stops on blue, reverses on black, and saves checkpoints on silver. Both cameras        RIGHTHANDRULE –                           EMPTY TILE– Recover
   scan for victims simultaneously,deployingrescue kits and blinking the RGB LED          Follow wall for exploring               based on non- discovered
   on detection.                                                                          and mapping tile.                              tile from mapping

Faizuddin Centre of Educational Excellence                                                                                     RoboCup Junior 2026
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Team description paper
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Source code
The team's own source code, 7.7 MB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.