
LF Rescue Unit
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials76 KBPublished
- Team description paperNot shared
- Engineering journalNot shared
- Source code3 KB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
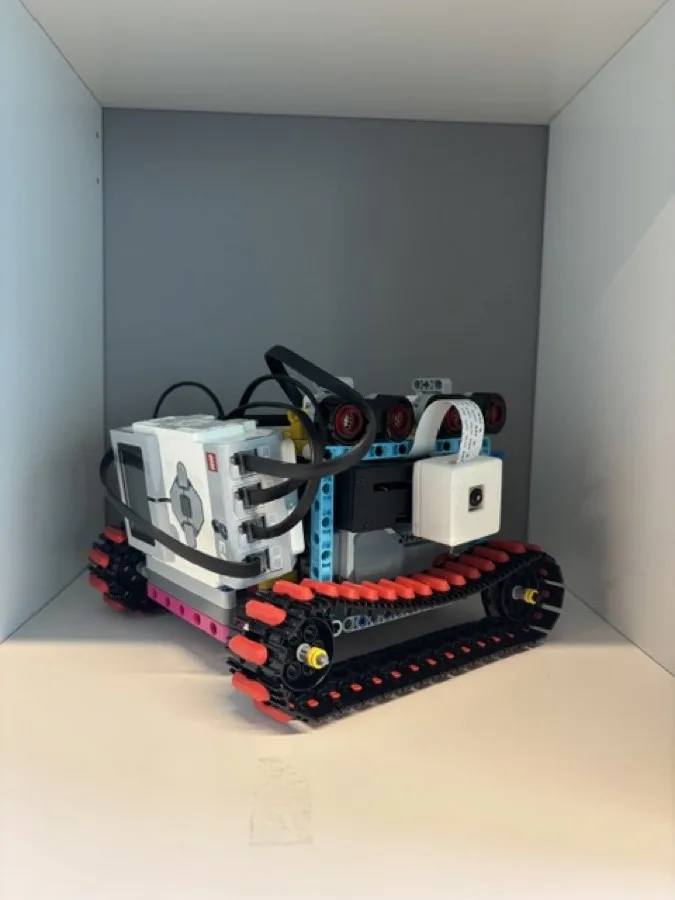
Our robot is based on a combination of a LEGO EV3 and a Raspberry Pi. It is autonomous and designed to navigate complex maze environments, detect victims, avoid obstacles, and deploy rescue kits reliably. The robot is capable of following walls, identifying floor markings, recognizing victims through both color and letter detection.
A major focus of the project was reliability and modularity. The robot uses a distributed architecture in which navigation and vision processing operate independently while remaining coordinated through event-based communication. This approach improves stability during movement and allows the robot to continue navigating smoothly even while image processing tasks are being performed.
Another important aspect of the design is the use of mostly standard and easily replaceable components instead of highly specialized custom-built systems. This simplifies maintenance, reduces construction complexity, and allows the team to focus more on software development, testing, and system integration.
Throughout development, the robot was improved through iterative testing and redesign. Special attention was given to navigation consistency, victim detection reliability under varying lighting conditions, and stable rescue kit deployment. The final result is a robust and adaptable robot capable of performing reliably in Rescue Maze challenges.
Poster
Read the text of this document — 149 words
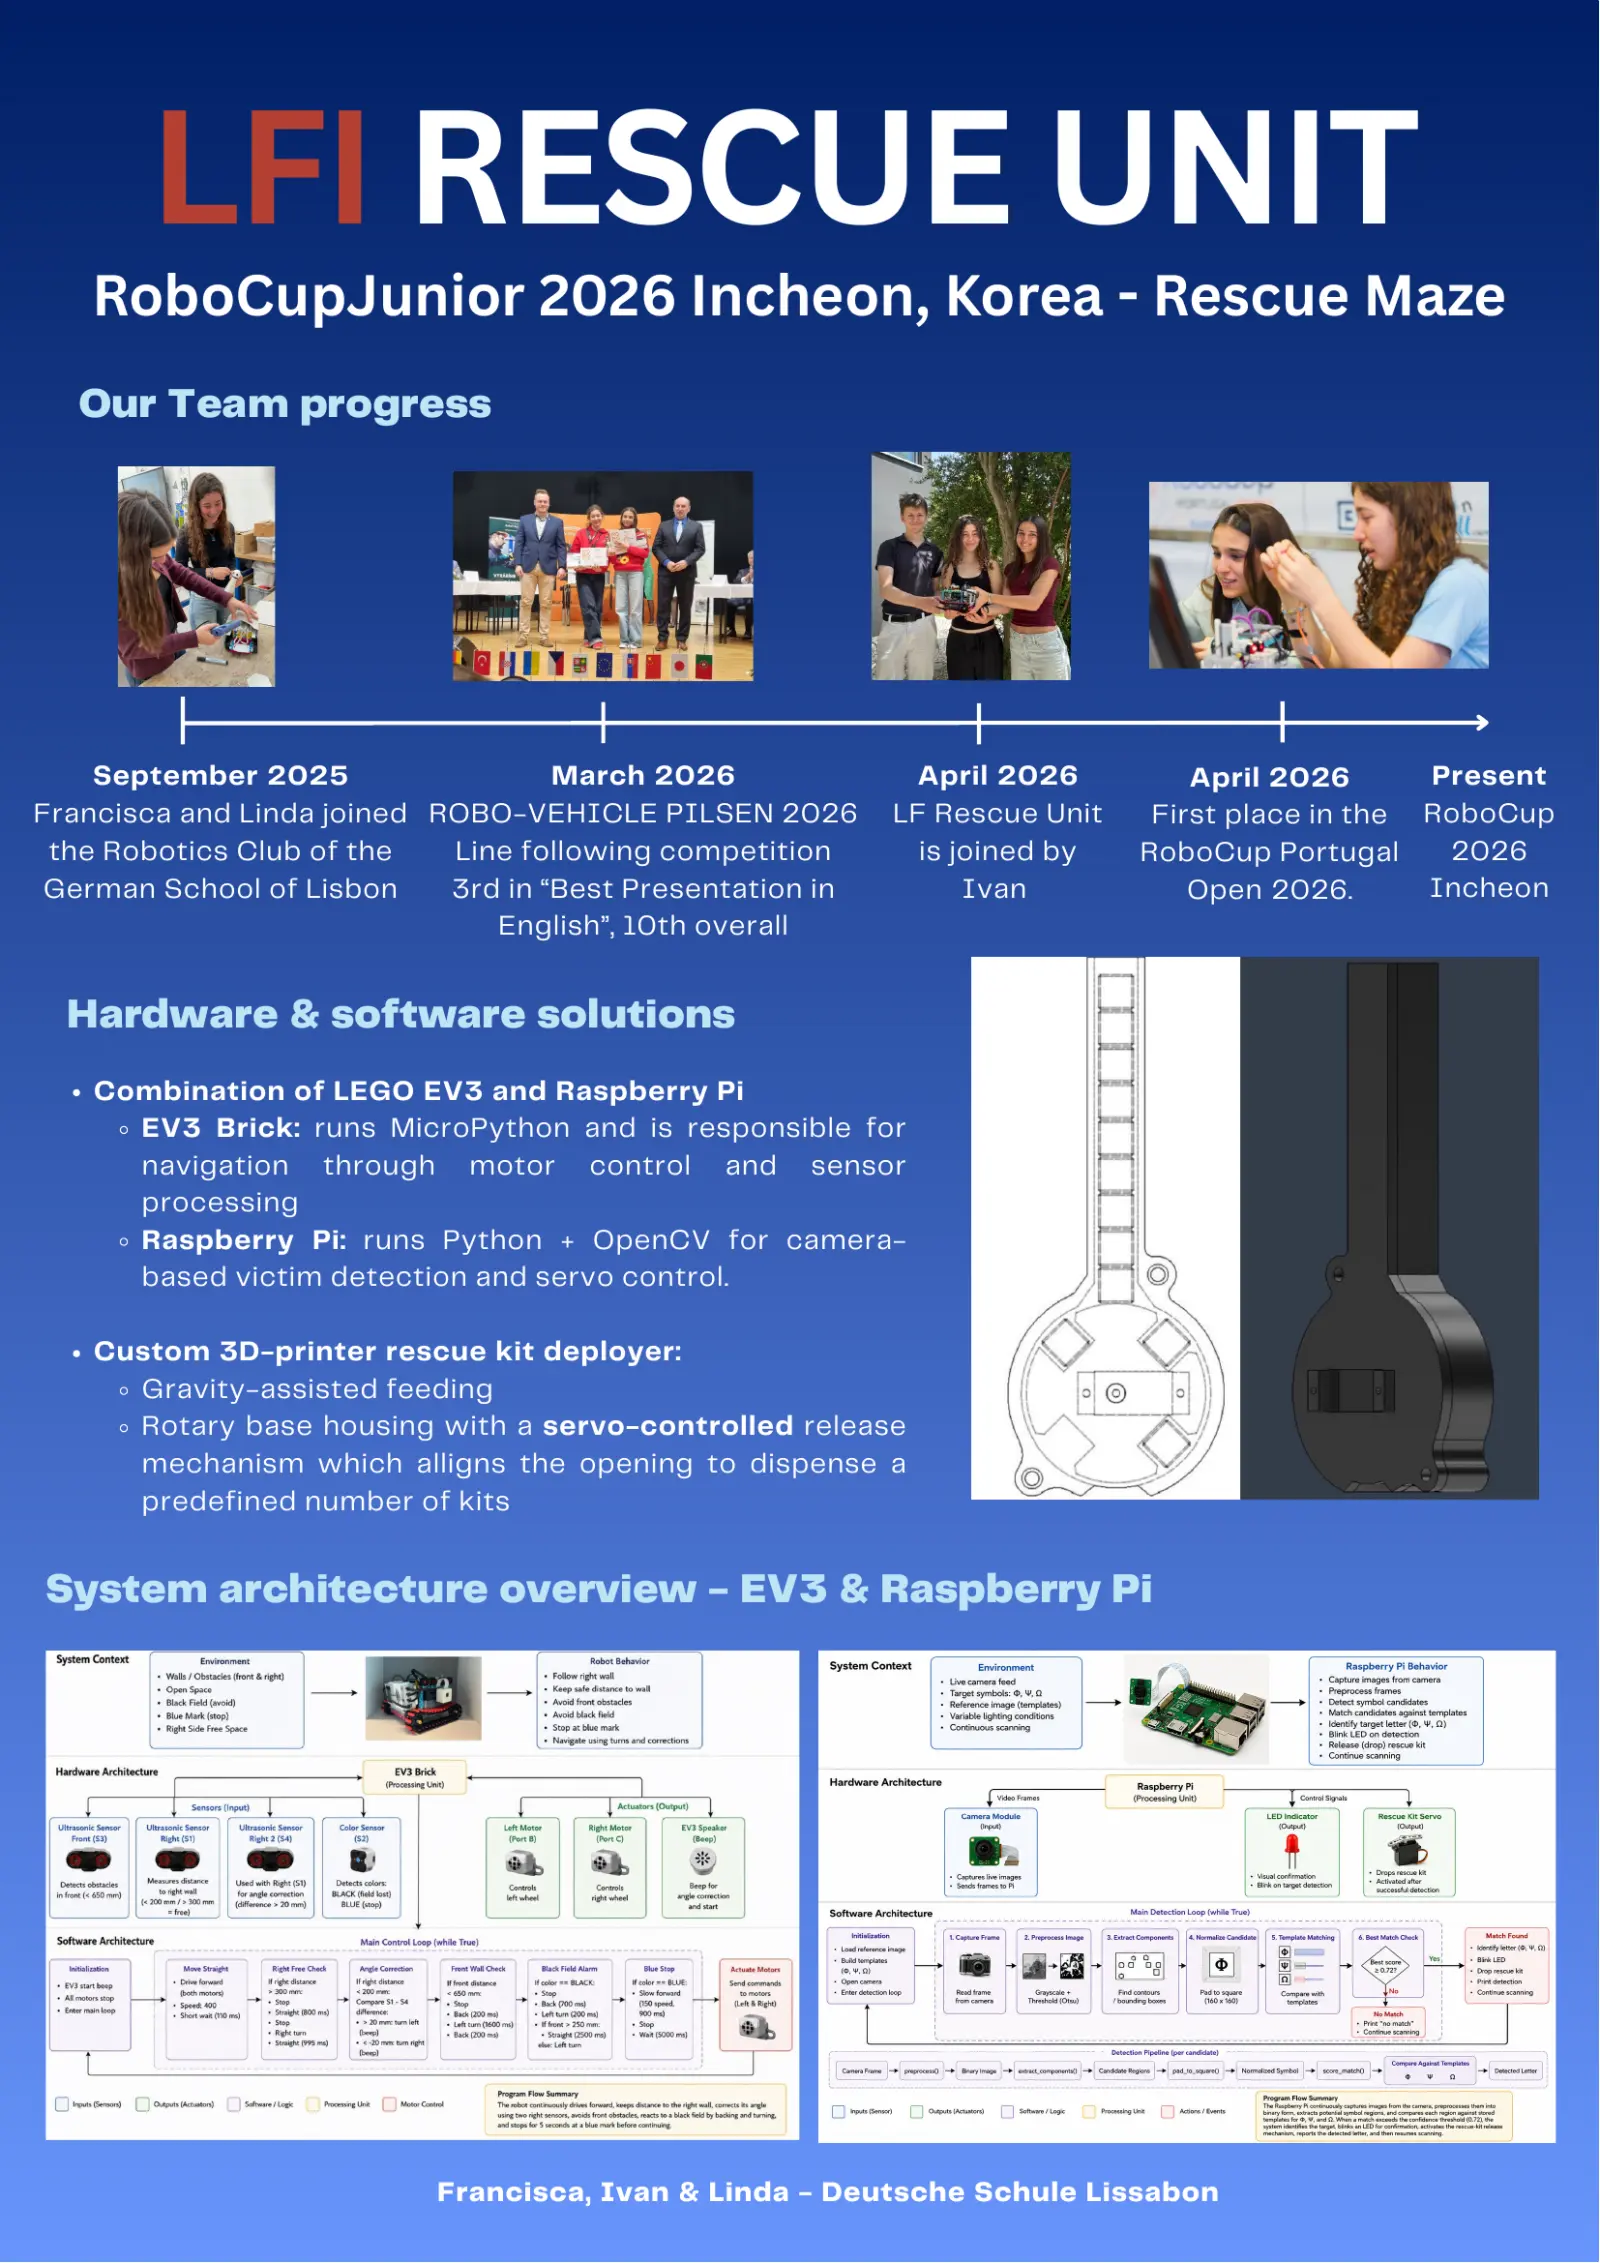
LFI RESCUE UNIT
   RoboCupJunior 2026 Incheon, Korea - Rescue Maze
   Our Team progress

    September 2025                  March 2026              April 2026          April 2026      Present
Francisca and Linda joined ROBO-VEHICLE PILSEN 2026        LF Rescue Unit    First place in the RoboCup
 the Robotics Club of the   Line following competition       is joined by   RoboCup Portugal     2026
 German School of Lisbon    3rd in “Best Presentation in         Ivan           Open 2026.      Incheon
                               English”, 10th overall

  Hardware & software solutions
    Combination of LEGO EV3 and Raspberry Pi
      EV3 Brick: runs MicroPython and is responsible for
      navigation through motor control and sensor
      processing
      Raspberry Pi: runs Python + OpenCV for camera-
      based victim detection and servo control.

    Custom 3D-printer rescue kit deployer:
      Gravity-assisted feeding
      Rotary base housing with a servo-controlled release
      mechanism which alligns the opening to dispense a
      predefined number of kits

System architecture overview - EV3 & Raspberry Pi

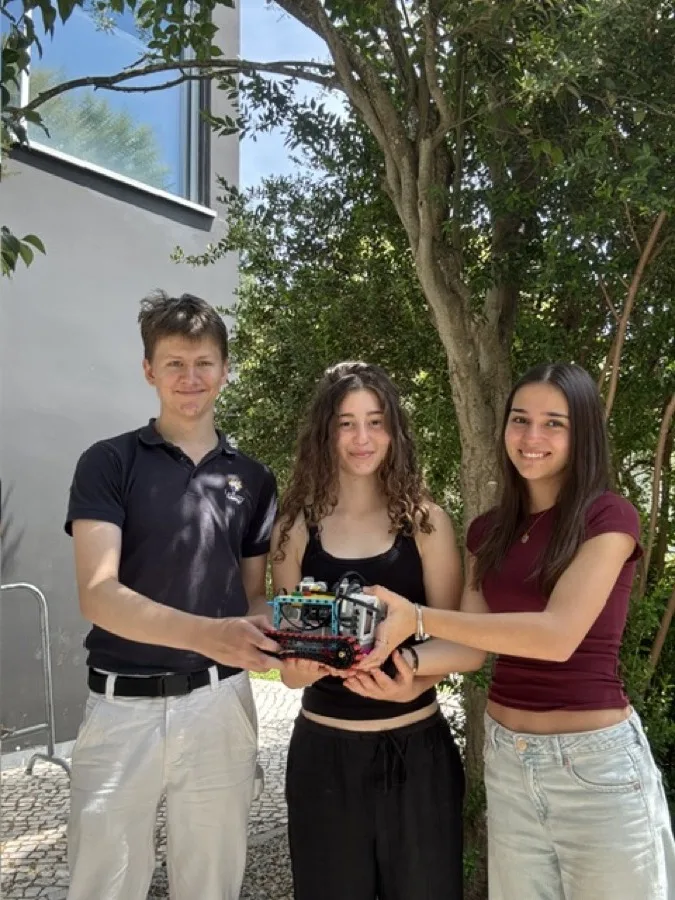
                           Francisca, Ivan & Linda - Deutsche Schule Lissabon
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Source code
The team's own source code, 3 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.