
Byte Volta
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials2 pagesPublished
- Team description paper5.0 MBPublished
- Engineering journalNot shared
- Source codeNot shared
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
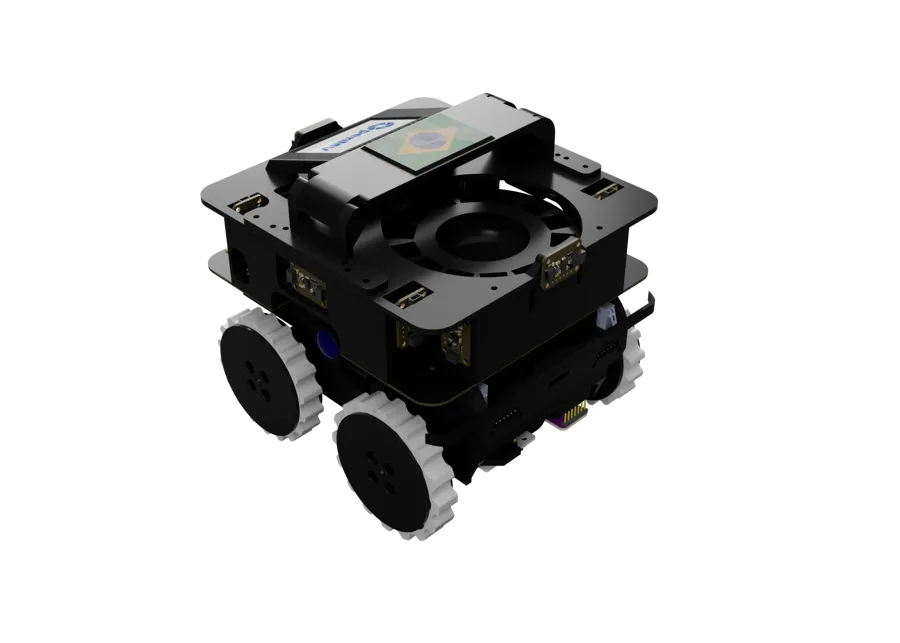
Our robot was entirely designed and built by the team to compete in the RoboCup Junior Rescue Maze category. The mechanical structure was conceived as a three-floor independent modular architecture, allowing quick hardware modifications and component replacements between rounds, giving the team a significant competitive advantage in adaptability.
To handle speedbumps up to 3 cm, the robot features a custom-designed suspension system that ensures stable ground contact across uneven terrain, maintaining sensor accuracy and locomotion consistency throughout the course.
Navigation is powered by a custom mapping algorithm based on Dijkstra's shortest path method, enabling the robot to efficiently explore and traverse the maze while continuously updating its internal map in real time. This approach allows fast and reliable pathfinding even in previously unknown environments.
The robot's electronics are built around a fully custom Printed Circuit Board (PCB), designed to be versatile and easily reconfigurable to meet different competition requirements. Vision capabilities are provided by a pair of OpenMV RT1062 cameras, capable of processing images at high frame rates and running embedded AI models directly on the hardware, enabling real-time victim detection without relying on external processing.
Together, these systems make our robot a robust, adaptable, and intelligent platform, engineered from the ground up for competitive performance.
Poster
Read the text of this document — 1103 words
League: RCJ Maze
Byte Volta Software
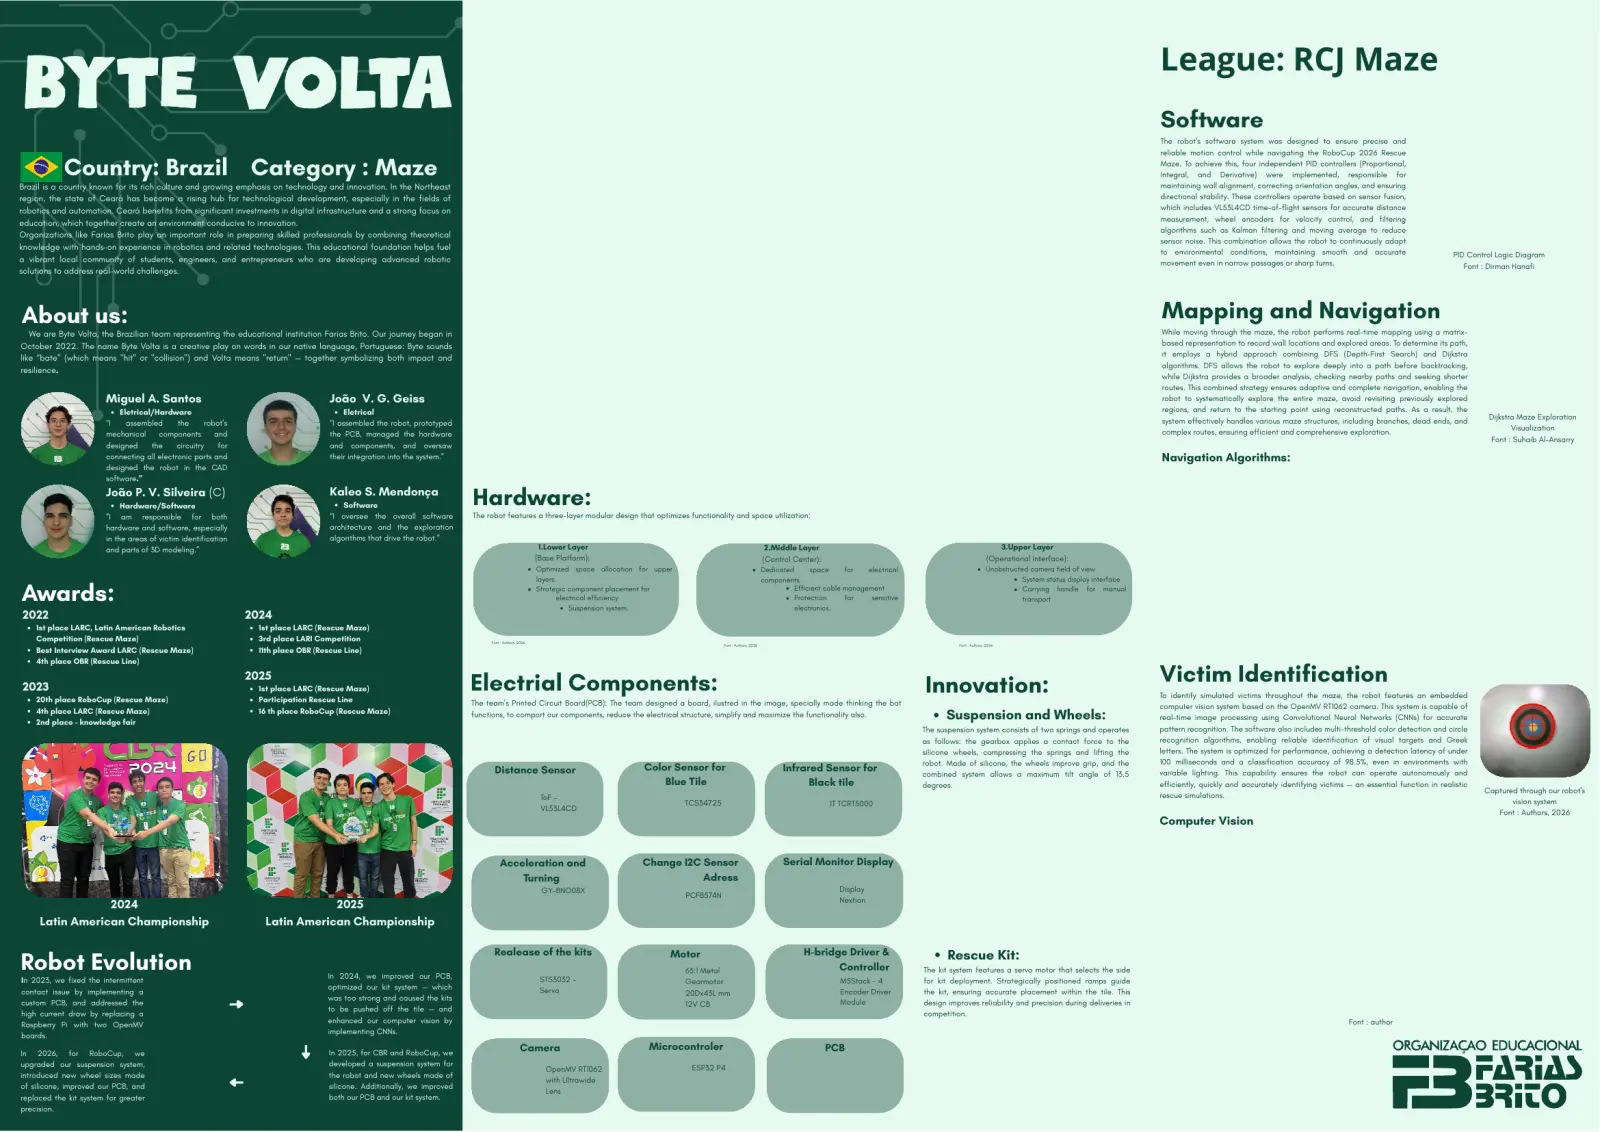
The robot's software system was designed to ensure precise and
reliable motion control while navigating the RoboCup 2026 Rescue
Country: Brazil Category : Maze Maze. To achieve this, four independent PID controllers (Proportional,
Integral, and Derivative) were implemented, responsible for
Brazil is a country known for its rich culture and growing emphasis on technology and innovation. In the Northeast maintaining wall alignment, correcting orientation angles, and ensuring
region, the state of Ceará has become a rising hub for technological development, especially in the fields of directional stability. These controllers operate based on sensor fusion,
robotics and automation. Ceará benefits from significant investments in digital infrastructure and a strong focus on which includes VL53L4CD time-of-flight sensors for accurate distance
measurement, wheel encoders for velocity control, and filtering
education, which together create an environment conducive to innovation.
algorithms such as Kalman filtering and moving average to reduce
Organizations like Farias Brito play an important role in preparing skilled professionals by combining theoretical
sensor noise. This combination allows the robot to continuously adapt
knowledge with hands-on experience in robotics and related technologies. This educational foundation helps fuel
to environmental conditions, maintaining smooth and accurate PID Control Logic Diagram
a vibrant local community of students, engineers, and entrepreneurs who are developing advanced robotic movement even in narrow passages or sharp turns. Font : Dirman Hanafi
solutions to address real-world challenges.
About us: Mapping and Navigation
We are Byte Volta, the Brazilian team representing the educational institution Farias Brito. Our journey began in While moving through the maze, the robot performs real-time mapping using a matrix-
October 2022. The name Byte Volta is a creative play on words in our native language, Portuguese: Byte sounds based representation to record wall locations and explored areas. To determine its path,
like “bate” (which means "hit" or "collision") and Volta means "return" — together symbolizing both impact and it employs a hybrid approach combining DFS (Depth-First Search) and Dijkstra
algorithms. DFS allows the robot to explore deeply into a path before backtracking,
resilience.
while Dijkstra provides a broader analysis, checking nearby paths and seeking shorter
routes. This combined strategy ensures adaptive and complete navigation, enabling the
Miguel A. Santos João V. G. Geiss robot to systematically explore the entire maze, avoid revisiting previously explored
Eletrical/Hardware Eletrical regions, and return to the starting point using reconstructed paths. As a result, the
system effectively handles various maze structures, including branches, dead ends, and Dijkstra Maze Exploration
“I assembled the robot’s “I assembled the robot, prototyped
complex routes, ensuring efficient and comprehensive exploration. Visualization
mechanical components and the PCB, managed the hardware
Font : Suhaib Al-Ansarry
designed the circuitry for and components, and oversaw
connecting all electronic parts and their integration into the system.” Navigation Algorithms:
designed the robot in the CAD
software.”
João P. V. Silveira (C)
Hardware/Software
Kaleo S. Mendonça
Software Hardware:
”I am responsible for both “I oversee the overall software The robot features a three-layer modular design that optimizes functionality and space utilization:
hardware and software, especially architecture and the exploration
in the areas of victim identification algorithms that drive the robot.”
and parts of 3D modeling.” 1.Lower Layer 2.Middle Layer 3.Upper Layer
(Base Platform): (Control Center): (Operational Interface):
Optimized space allocation for upper Dedicated space for electrical Unobstructed camera field of view
layers. components System status display interface
Awards: Strategic component placement for
electrical efficiency
Suspension system.
Efficient cable management
Protection
electronics.
for sensitive
Carrying handle for manual
transport
2022 2024
1st place LARC, Latin American Robotics 1st place LARC (Rescue Maze)
Competition (Rescue Maze) 3rd place LARI Competition Font : Authors, 2026
Font : Authors, 2026 Font : Authors, 2026
Best Interview Award LARC (Rescue Maze) 11th place OBR (Rescue Line)
4th place OBR (Rescue Line)
2023
2025
1st place LARC (Rescue Maze) Electrial Components: Innovation: Victim Identification
To identify simulated victims throughout the maze, the robot features an embedded
20th place RoboCup (Rescue Maze) Participation Rescue Line The team’s Printed Circuit Board(PCB): The team designed a board, ilustred in the image, specially made thinking the bot computer vision system based on the OpenMV RT1062 camera. This system is capable of
4th place LARC (Rescue Maze) 16 th place RoboCup (Rescue Maze)
2nd place - knowledge fair
functions, to comport our components, reduce the electrical structure, simplify and maximize the functionality also. Suspension and Wheels: real-time image processing using Convolutional Neural Networks (CNNs) for accurate
The suspension system consists of two springs and operates pattern recognition. The software also includes multi-threshold color detection and circle
as follows: the gearbox applies a contact force to the recognition algorithms, enabling reliable identification of visual targets and Greek
silicone wheels, compressing the springs and lifting the letters. The system is optimized for performance, achieving a detection latency of under
robot. Made of silicone, the wheels improve grip, and the 100 milliseconds and a classification accuracy of 98.5%, even in environments with
Distance Sensor Color Sensor for Infrared Sensor for variable lighting. This capability ensures the robot can operate autonomously and
combined system allows a maximum tilt angle of 13.5
Blue Tile Black tile degrees. efficiently, quickly and accurately identifying victims — an essential function in realistic
Captured through our robot's
ToF - rescue simulations.
TCS34725 IT TCRT5000 vision system
VL53L4CD Font : Authors, 2026
Computer Vision
Acceleration and Change I2C Sensor Serial Monitor Display
Turning Adress
GY-BNO08X Display
PCF8574N
Nextion
2024 2025
Latin American Championship Latin American Championship
Realease of the kits H-bridge Driver & Rescue Kit:
Robot Evolution In 2024, we improved our PCB,
Motor
63:1 Metal Controller The kit system features a servo motor that selects the side
In 2023, we fixed the intermittent STS3032 - Gearmotor M5Stack - 4 for kit deployment. Strategically positioned ramps guide
optimized our kit system — which Servo
contact issue by implementing a 20Dx43L mm Encoder Driver the kit, ensuring accurate placement within the tile. This
was too strong and caused the kits
custom PCB, and addressed the 12V CB Module design improves reliability and precision during deliveries in
to be pushed off the tile — and
high current draw by replacing a competition.
enhanced our computer vision by Font : author
Raspberry Pi with two OpenMV
implementing CNNs.
boards.
Camera Microcontroler PCB
In 2026, for RoboCup, we In 2025, for CBR and RoboCup, we
upgraded our suspension system, developed a suspension system for ESP32 P4
OpenMV RT1062
introduced new wheel sizes made the robot and new wheels made of
with Ultrawide
of silicone, improved our PCB, and silicone. Additionally, we improved
Lens
replaced the kit system for greater both our PCB and our kit system.
precision.
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Read the text of this document — 758 words
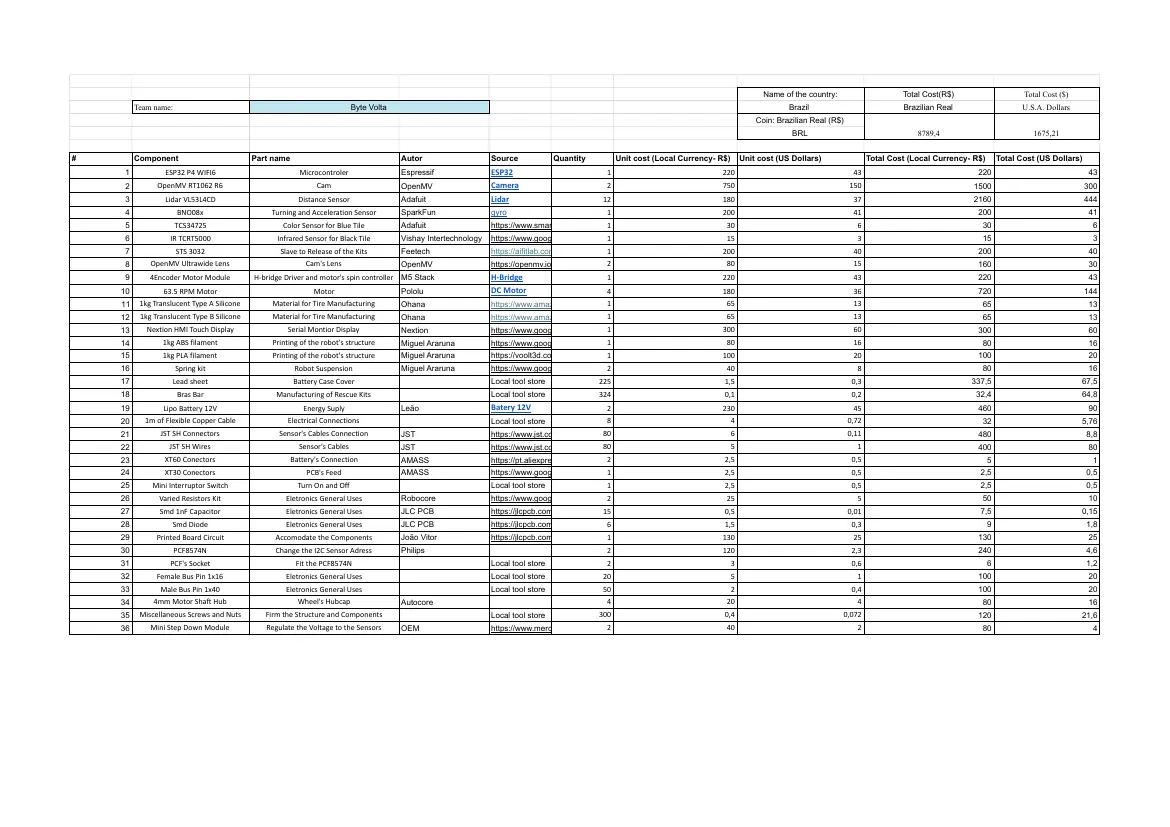
Name of the country: Total Cost(R$) Total Cost ($)
Team name: Byte Volta Brazil Brazilian Real U.S.A. Dollars
Coin: Brazilian Real (R$)
BRL 8789,4 1675,21
# Component Part name Autor Source Quantity Unit cost (Local Currency- R$) Unit cost (US Dollars) Total Cost (Local Currency- R$) Total Cost (US Dollars)
1 ESP32 P4 WIFI6 Microcontroler Espressif ESP32 1 220 43 220 43
2 OpenMV RT1062 R6 Cam OpenMV Camera 2 750 150 1500 300
3 Lidar VL53L4CD Distance Sensor Adafuit Lidar 12 180 37 2160 444
4 BNO08x Turning and Acceleration Sensor SparkFun gyro 1 200 41 200 41
5 TCS34725 Color Sensor for Blue Tile Adafuit 1 30 6 30 6
https://www.smartkits.com.br/modulo-sensor-de-cor-rgb-tcs34725-com-filtro-ir?parceiro=9390&srsltid=AfmBOooxjj2Y546MxXx4r4eIA9y9OTj6FQEgWs-w8iKq-dfbeBJ6uAs2Z2Y
6 IR TCRT5000 Infrared Sensor for Black Tile Vishay Intertechnology 1 15 3 15 3
https://www.google.com/url?sa=i&source=web&cd=&ved=0CGgQj_IEahcKEwiA8pya04KVAxUAAAAAHQAAAAAQBQ&url=https%3A%2F%2Fwww.ebay.com%2Fitm%2F132544534420&psig=A
7 STS 3032 Slave to Release of the Kits Feetech https://aifitlab.com/products/feetech-sts3032-servo-motor?srsltid=AfmBOorHnT_nUKwgy-JfPjvX6iXPP_KrQq532TxT_Xoo7fN1aP4yq7Cz
1 200 40 200 40
8 OpenMV Ultrawide Lens Cam's Lens OpenMV https://openmv.io/products/ultra-wide-angle-lens?srsltid=AfmBOooL5HiXNDjG1Wlj6_Unq8M6tf6FI2lfna5BFUMiJLfwBrKH0g1j
2 80 15 160 30
9 4Encoder Motor Module H-bridge Driver and motor's spin controller M5 Stack H-Bridge 1 220 43 220 43
10 63.5 RPM Motor Motor Pololu DC Motor 4 180 36 720 144
11 1kg Translucent Type A Silicone Material for Tire Manufacturing Ohana https://www.amazon.com.br/Borracha-Silicone-Transl%C3%BAcida-Flex%C3%ADvel-Detalhados/dp/B0G1PLBB9F/ref=asc_df_B0G1PLBB9F?mcid=bac9be7e56703fbbbf34741306b2042f&tag
1 65 13 65 13
12 1kg Translucent Type B Silicone Material for Tire Manufacturing Ohana 1 65 13 65 13
https://www.amazon.com.br/Borracha-Silicone-Transl%C3%BAcida-Flex%C3%ADvel-Detalhados/dp/B0G1PLBB9F/ref=asc_df_B0G1PLBB9F?mcid=bac9be7e56703fbbbf34741306b2042f&tag
13 Nextion HMI Touch Display Serial Montior Display Nextion 1 300 60 300 60
https://www.google.com/aclk?sa=L&ai=DChsSEwiV2ZHQ1IKVAxUrXkgAHTASNAAYACICCAEQEhoCY2U&co=1&gclid=Cj0KCQjw3K7RBhDJARIsAKRtP5RN3bG8PcFQxkftb5Zz8CgFt-VPSx4
14 1kg ABS filament Printing of the robot's structure Miguel Araruna https://www.google.com/aclk?sa=L&ai=DChsSEwirzezj1IKVAxX3X0gAHUNoN5oYACICCAEQFhoCY2U&co=1&gclid=Cj0KCQjw3K7RBhDJARIsAKRtP5QpP3uJSVlcdFElC8eiR9a13DLFi9r4VU
1 80 16 80 16
15 1kg PLA filament Printing of the robot's structure Miguel Araruna https://voolt3d.com.br/produtos/filamento-pla-preto-premium/?variant=1194390075&pf=mc
1 100 20 100 20
16 Spring kit Robot Suspension Miguel Araruna https://www.google.com/aclk?sa=L&ai=DChsSEwiQz7ie1YKVAxUgVUgAHSzXGGkYACICCAEQAxoCY2U&co=1&gclid=Cj0KCQjw3K7RBhDJARIsAKRtP5Rz0uV0ddcW6hrsLD70TF_moAyvNH
2 40 8 80 16
17 Lead sheet Battery Case Cover Local tool store 225 1,5 0,3 337,5 67,5
18 Bras Bar Manufacturing of Rescue Kits Local tool store 324 0,1 0,2 32,4 64,8
19 Lipo Battery 12V Energy Suply Leão Batery 12V 2 230 45 460 90
20 1m of Flexible Copper Cable Electrical Connections Local tool store 8 4 0,72 32 5,76
21 JST SH Connectors Sensor's Cables Connection JST https://www.jst.com/ 80 6 0,11 480 8,8
22 JST SH Wires Sensor's Cables JST https://www.jst.com/ 80 5 1 400 80
23 XT60 Conectors Battery's Connection AMASS 2 2,5 0,5 5 1
https://pt.aliexpress.com/item/1005011821738974.html?src=google&src=google&albch=shopping&acnt=248-630-5778&isdl=y&slnk=&plac=&mtctp=&albbt=Google_7_shopping&aff_platform=g
24 XT30 Conectors PCB's Feed AMASS https://www.google.com/aclk?sa=L&ai=DChsSEwjTieH_1YKVAxWlXkgAHeK6Nd0YACICCAEQEBoCY2U&co=1&gclid=Cj0KCQjw3K7RBhDJARIsAKRtP5T9CQMt08gUrfqQ2AqIlJmVCRNZdujT
1 2,5 0,5 2,5 0,5
25 Mini Interruptor Switch Turn On and Off Local tool store 1 2,5 0,5 2,5 0,5
26 Varied Resistors Kit Eletronics General Uses Robocore https://www.google.com/url?sa=t&source=web&rct=j&opi=89978449&url=https://www.robocore.net/resistor-potenciometro/kit-resistor%3Fsrsltid%3DAfmBOorp_BNqRzXyg7HU4V1p4R9QfIB_Y
2 25 5 50 10
27 Smd 1nF Capacitor Eletronics General Uses JLC PCB https://jlcpcb.com/ 15 0,5 0,01 7,5 0,15
28 Smd Diode Eletronics General Uses JLC PCB https://jlcpcb.com/ 6 1,5 0,3 9 1,8
29 Printed Board Circuit Accomodate the Components João Vitor https://jlcpcb.com/ 1 130 25 130 25
30 PCF8574N Change the I2C Sensor Adress Philips 2 120 2,3 240 4,6
31 PCF's Socket Fit the PCF8574N Local tool store 2 3 0,6 6 1,2
32 Female Bus Pin 1x16 Eletronics General Uses Local tool store 20 5 1 100 20
33 Male Bus Pin 1x40 Eletronics General Uses Local tool store 50 2 0,4 100 20
34 4mm Motor Shaft Hub Wheel's Hubcap Autocore 4 20 4 80 16
35 Miscellaneous Screws and Nuts Firm the Structure and Components Local tool store 300 0,4 0,072 120 21,6
36 Mini Step Down Module Regulate the Voltage to the Sensors OEM https://www.mercadolivre.com.br/regulador-tensao-step-down-buck-dcdc-mini-360-ate-3a/up/MLBU2364900335
2 40 2 80 4
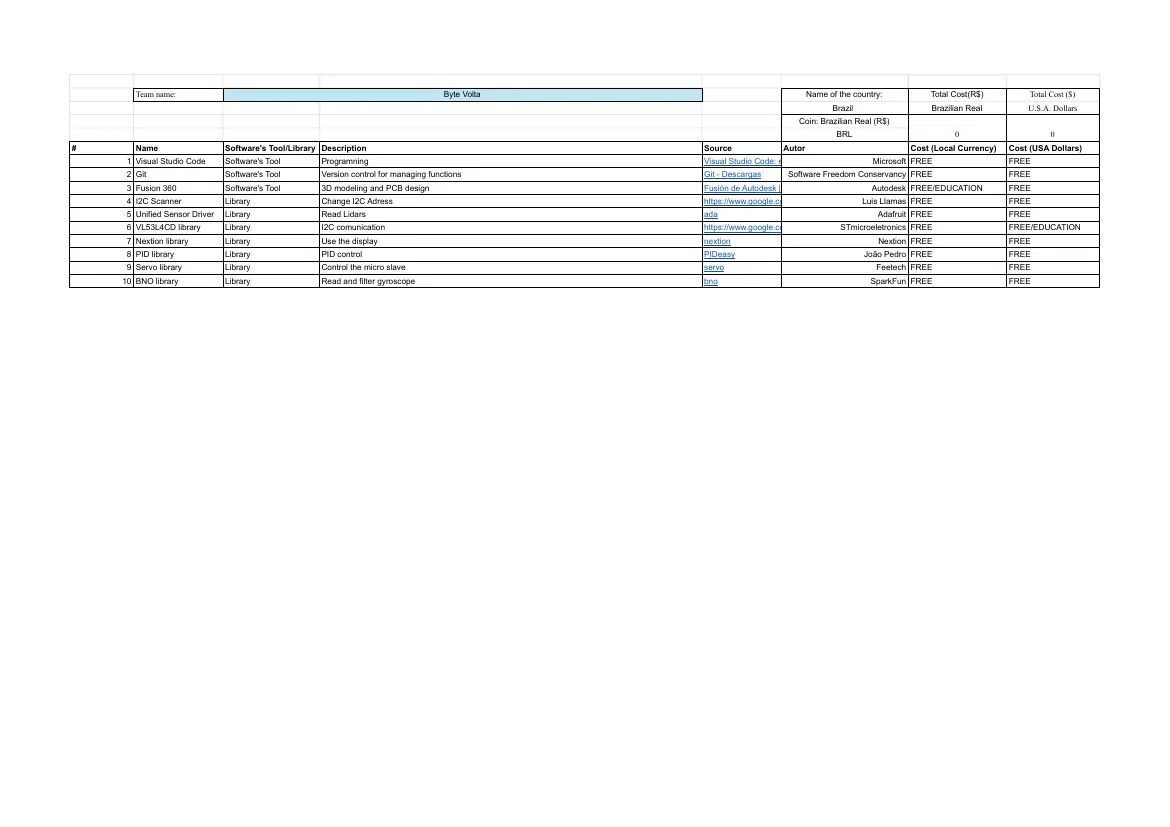
Team name: Byte Volta Name of the country: Total Cost(R$) Total Cost ($)
Brazil Brazilian Real U.S.A. Dollars
Coin: Brazilian Real (R$)
BRL 0 0
# Name Software's Tool/Library Description Source Autor Cost (Local Currency) Cost (USA Dollars)
1 Visual Studio Code Software's Tool Programning Visual Studio Code: edición de código. Redefinido
Microsoft FREE FREE
2 Git Software's Tool Version control for managing functions Git - Descargas Software Freedom Conservancy FREE FREE
3 Fusion 360 Software's Tool 3D modeling and PCB design Fusión de Autodesk | Software basado en la nube
Autodesk
3D CAD,
FREE/EDUCATION
CAM, CAE y PCB | Autodesk
FREE
4 I2C Scanner Library Change I2C Adress https://www.google.com/url?sa=t&source=web&rct=j&opi=89978449&url=https://github.com/luisllamasbinaburo/Arduino-I2CScan
Luis Llamas FREE FREE
5 Unified Sensor Driver Library Read Lidars ada Adafruit FREE FREE
6 VL53L4CD library Library I2C comunication https://www.google.com/url?sa=t&source=web&rct=j&opi=89978449&url=https://github.com/stm32duino/VL53L4CD&ved=2ahUK
STmicroeletronics FREE FREE/EDUCATION
7 Nextion library Library Use the display nextion Nextion FREE FREE
8 PID library Library PID control PIDeasy João Pedro FREE FREE
9 Servo library Library Control the micro slave servo Feetech FREE FREE
10 BNO library Library Read and filter gyroscope bno SparkFun FREE FREE
2 pages, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Team description paper
Shown as the original PDF: this document could not be rendered as images, so the file itself is what the page offers.