
AURAT
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials2 pagesPublished
- Team description paper349 KBPublished
- Engineering journalNot shared
- Source code20 KB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
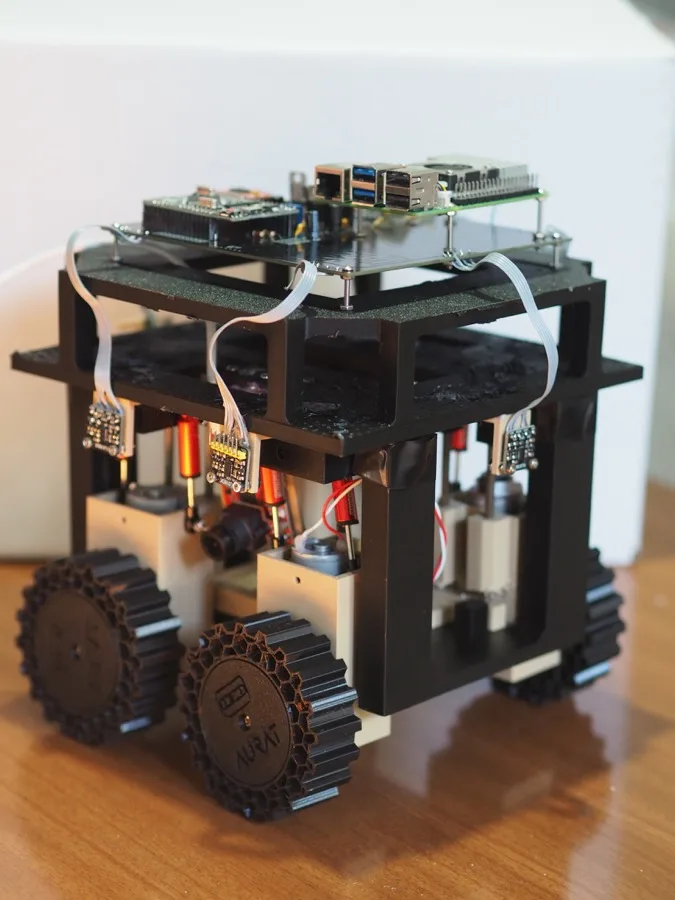
This paper presents the autonomous rescue robot developed by team AURAT for the RoboCupJunior Rescue Maze 2026 World Finals. Designed to achieve full exploration and precise victim identification within a strict 8-minute time limit, the robot features a robust, modular three-level physical architecture built with a custom vertical suspension system and hollow-rimmed TPU tires to safely navigate speedbumps and 25° ramps. The hardware ecosystem coordinates an Arduino Mega for low-level motion control, a custom 4-layer PCB for noise-free electronics routing, and a Raspberry Pi 5 acting as the high-level master node. To optimize computational efficiency, the software implements a concurrent, multi-threaded architecture utilizing Dijkstra’s algorithm for real-time dynamic pathfinding. Following technical challenges encountered during the national qualifiers in Catania, the vision pipeline was successfully upgraded from a blocking full-frame YOLOv8 model into an optimized, two-tiered framework. Spatial-chromatic blob localization is offloaded to an OpenMV H7 Plus edge camera, while character classification is executed on the Raspberry Pi 5 via a high-speed, rotation-invariant K-Nearest Neighbors (KNN) pipeline. System integration testing validates that these concurrent refinements guarantee deterministic obstacle navigation, robust cell alignment, and highly resilient target identification under variable arena conditions
Poster
Read the text of this document — 1094 words
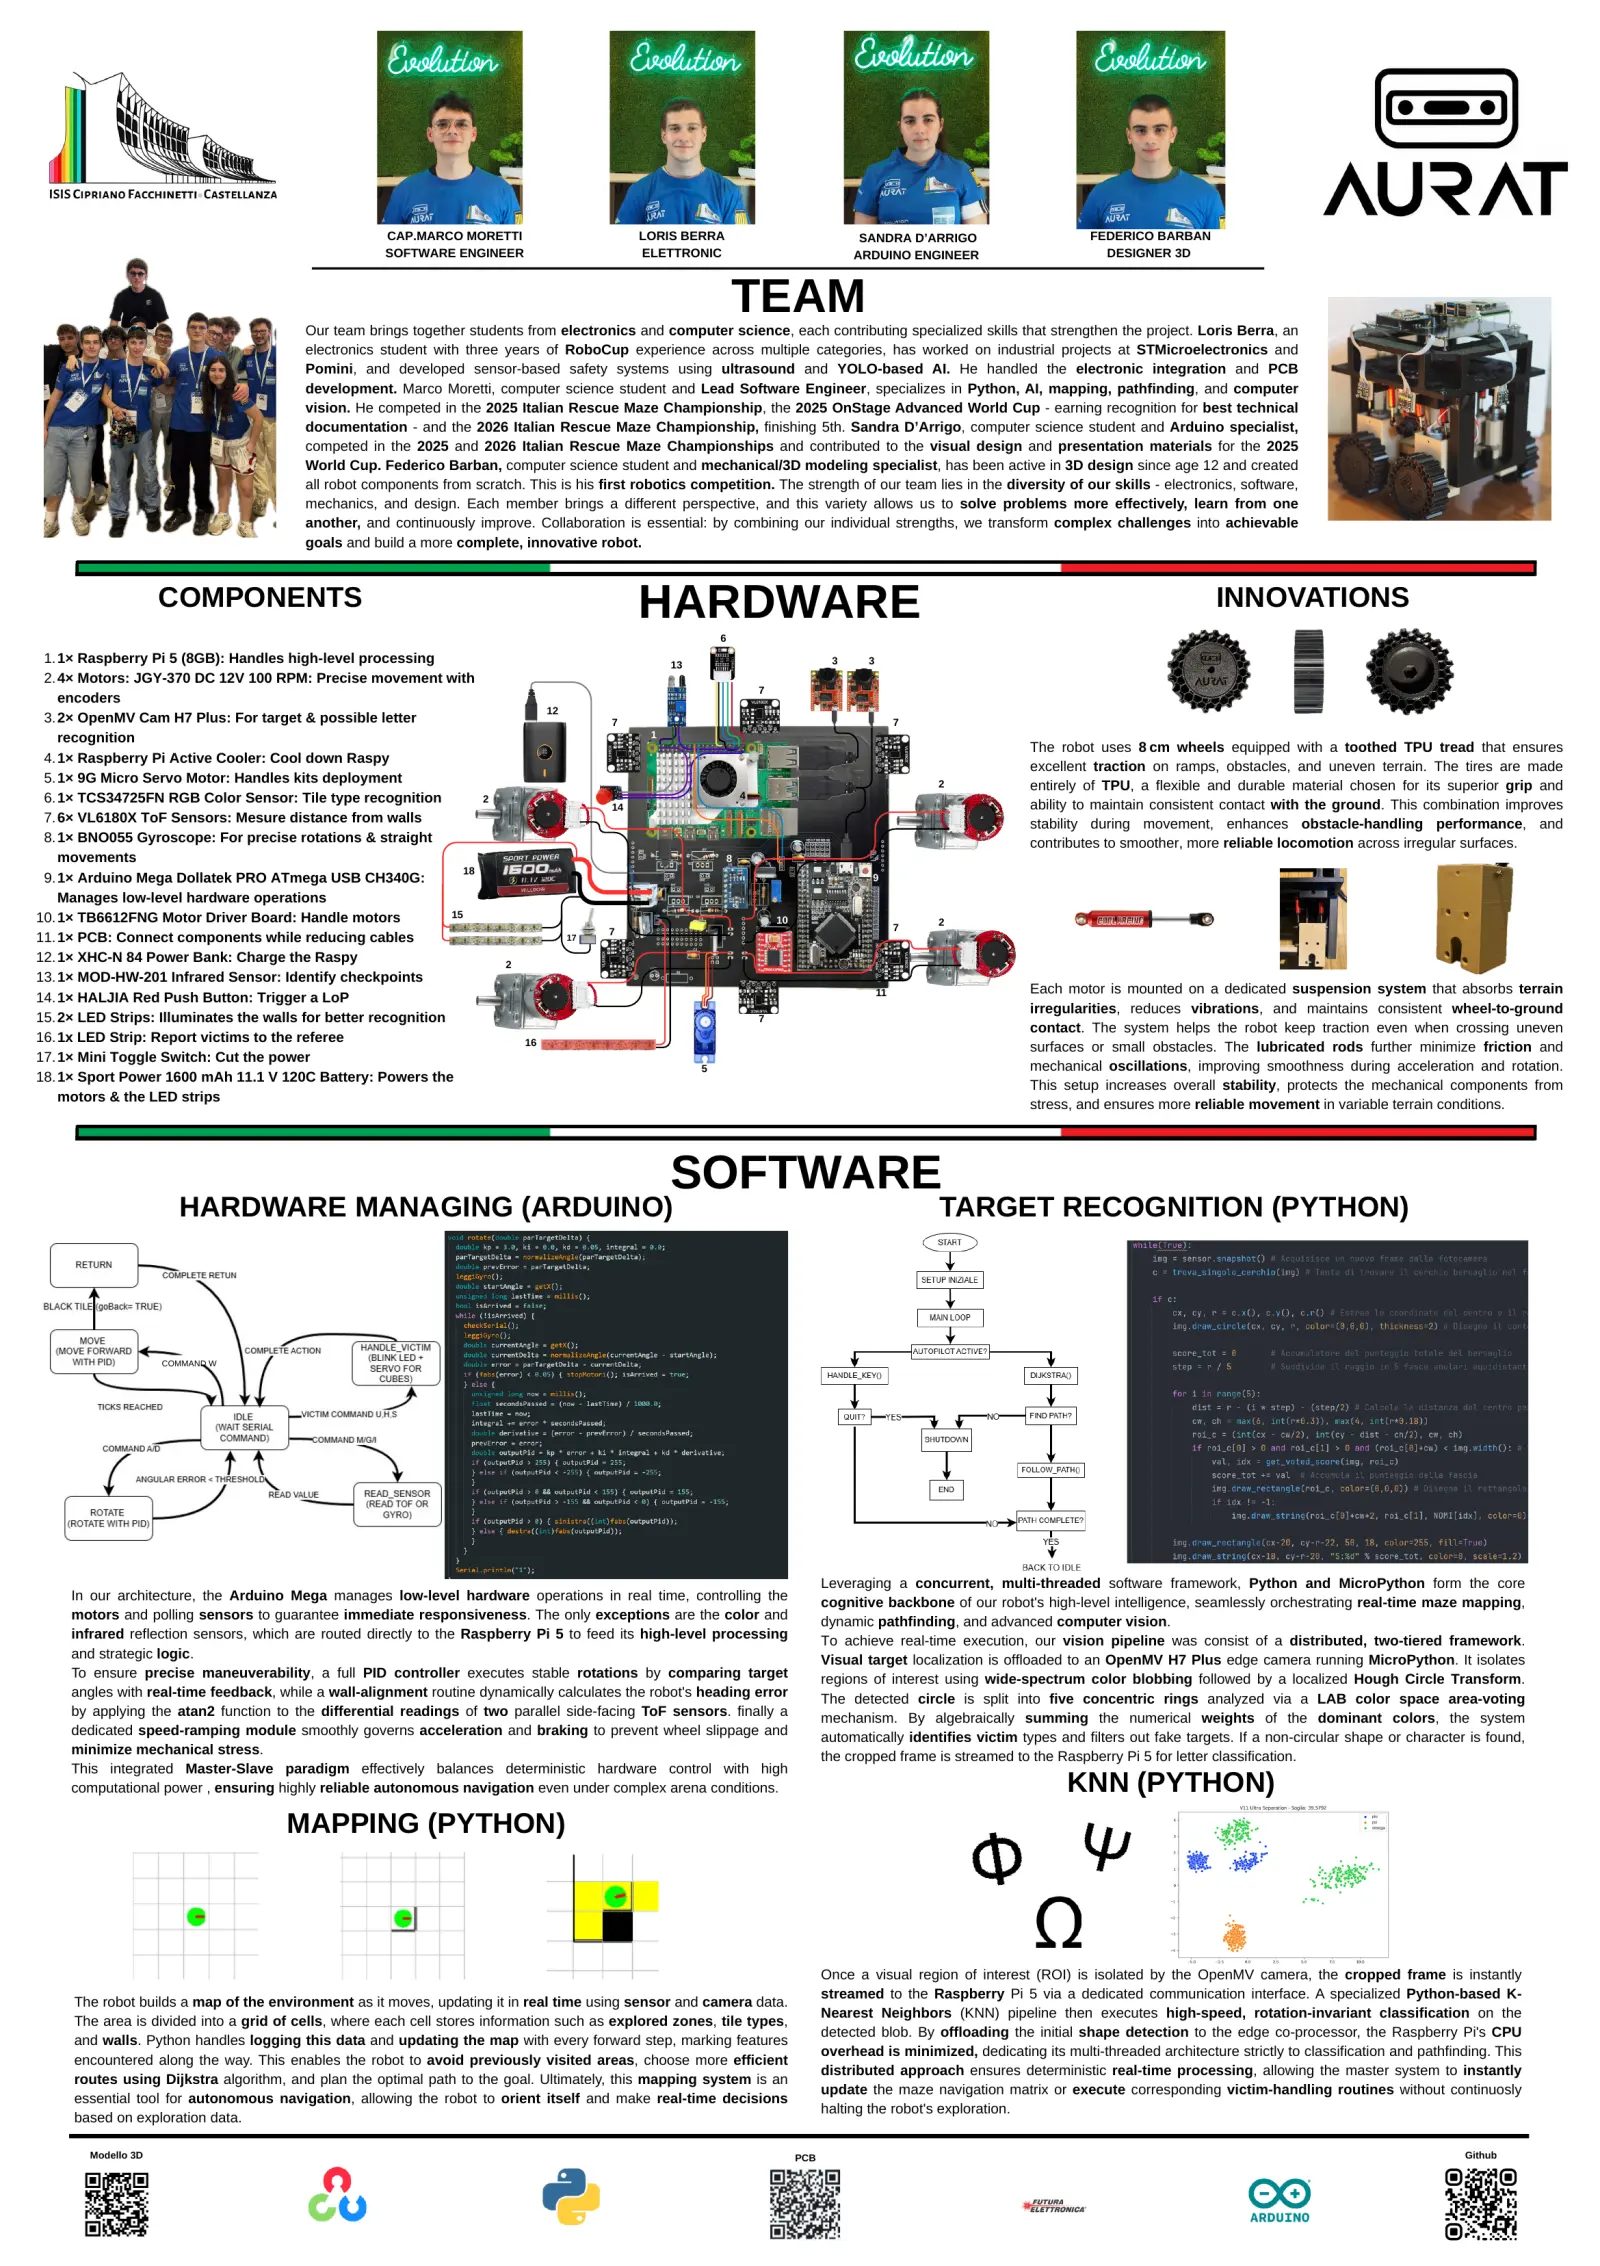
CAP.MARCO MORETTI LORIS BERRA SANDRA D’ARRIGO FEDERICO BARBAN
SOFTWARE ENGINEER ELETTRONIC ARDUINO ENGINEER DESIGNER 3D
TEAM
Our team brings together students from electronics and computer science, each contributing specialized skills that strengthen the project. Loris Berra, an
electronics student with three years of RoboCup experience across multiple categories, has worked on industrial projects at STMicroelectronics and
Pomini, and developed sensor‑based safety systems using ultrasound and YOLO‑based AI. He handled the electronic integration and PCB
development. Marco Moretti, computer science student and Lead Software Engineer, specializes in Python, AI, mapping, pathfinding, and computer
vision. He competed in the 2025 Italian Rescue Maze Championship, the 2025 OnStage Advanced World Cup - earning recognition for best technical
documentation - and the 2026 Italian Rescue Maze Championship, finishing 5th. Sandra D’Arrigo, computer science student and Arduino specialist,
competed in the 2025 and 2026 Italian Rescue Maze Championships and contributed to the visual design and presentation materials for the 2025
World Cup. Federico Barban, computer science student and mechanical/3D modeling specialist, has been active in 3D design since age 12 and created
all robot components from scratch. This is his first robotics competition. The strength of our team lies in the diversity of our skills - electronics, software,
mechanics, and design. Each member brings a different perspective, and this variety allows us to solve problems more effectively, learn from one
another, and continuously improve. Collaboration is essential: by combining our individual strengths, we transform complex challenges into achievable
goals and build a more complete, innovative robot.
COMPONENTS HARDWARE INNOVATIONS
6
1. 1× Raspberry Pi 5 (8GB): Handles high-level processing 13 3 3
2. 4× Motors: JGY‑370 DC 12V 100 RPM: Precise movement with
7
encoders
12
3. 2× OpenMV Cam H7 Plus: For target & possible letter 7 7
recognition 1
1 The robot uses 8 cm wheels equipped with a toothed TPU tread that ensures
4. 1× Raspberry Pi Active Cooler: Cool down Raspy
excellent traction on ramps, obstacles, and uneven terrain. The tires are made
5. 1× 9G Micro Servo Motor: Handles kits deployment 2 entirely of TPU, a flexible and durable material chosen for its superior grip and
6. 1× TCS34725FN RGB Color Sensor: Tile type recognition 2 4
ability to maintain consistent contact with the ground. This combination improves
14
7. 6× VL6180X ToF Sensors: Mesure distance from walls stability during movement, enhances obstacle‑handling performance, and
8. 1× BNO055 Gyroscope: For precise rotations & straight contributes to smoother, more reliable locomotion across irregular surfaces.
movements 8
18
9. 1× Arduino Mega Dollatek PRO ATmega USB CH340G: 9
7
Manages low-level hardware operations
10. 1× TB6612FNG Motor Driver Board: Handle motors 15
10 2
7 7
11. 1× PCB: Connect components while reducing cables 17
12. 1× XHC‑N 84 Power Bank: Charge the Raspy 2
13. 1× MOD‑HW‑201 Infrared Sensor: Identify checkpoints
11 Each motor is mounted on a dedicated suspension system that absorbs terrain
14. 1× HALJIA Red Push Button: Trigger a LoP
irregularities, reduces vibrations, and maintains consistent wheel‑to‑ground
15. 2× LED Strips: Illuminates the walls for better recognition 7
contact. The system helps the robot keep traction even when crossing uneven
16. 1x LED Strip: Report victims to the referee 16
surfaces or small obstacles. The lubricated rods further minimize friction and
17. 1× Mini Toggle Switch: Cut the power
5 mechanical oscillations, improving smoothness during acceleration and rotation.
18. 1× Sport Power 1600 mAh 11.1 V 120C Battery: Powers the
This setup increases overall stability, protects the mechanical components from
motors & the LED strips
stress, and ensures more reliable movement in variable terrain conditions.
SOFTWARE
HARDWARE MANAGING (ARDUINO) TARGET RECOGNITION (PYTHON)
COMMAND W
Leveraging a concurrent, multi-threaded software framework, Python and MicroPython form the core
In our architecture, the Arduino Mega manages low-level hardware operations in real time, controlling the cognitive backbone of our robot's high-level intelligence, seamlessly orchestrating real-time maze mapping,
motors and polling sensors to guarantee immediate responsiveness. The only exceptions are the color and dynamic pathfinding, and advanced computer vision.
infrared reflection sensors, which are routed directly to the Raspberry Pi 5 to feed its high-level processing To achieve real-time execution, our vision pipeline was consist of a distributed, two-tiered framework.
and strategic logic. Visual target localization is offloaded to an OpenMV H7 Plus edge camera running MicroPython. It isolates
To ensure precise maneuverability, a full PID controller executes stable rotations by comparing target regions of interest using wide-spectrum color blobbing followed by a localized Hough Circle Transform.
angles with real-time feedback, while a wall-alignment routine dynamically calculates the robot's heading error The detected circle is split into five concentric rings analyzed via a LAB color space area-voting
by applying the atan2 function to the differential readings of two parallel side-facing ToF sensors. finally a mechanism. By algebraically summing the numerical weights of the dominant colors, the system
dedicated speed-ramping module smoothly governs acceleration and braking to prevent wheel slippage and automatically identifies victim types and filters out fake targets. If a non-circular shape or character is found,
minimize mechanical stress. the cropped frame is streamed to the Raspberry Pi 5 for letter classification.
This integrated Master-Slave paradigm effectively balances deterministic hardware control with high
computational power , ensuring highly reliable autonomous navigation even under complex arena conditions. KNN (PYTHON)
MAPPING (PYTHON)
Once a visual region of interest (ROI) is isolated by the OpenMV camera, the cropped frame is instantly
streamed to the Raspberry Pi 5 via a dedicated communication interface. A specialized Python-based K-
The robot builds a map of the environment as it moves, updating it in real time using sensor and camera data.
Nearest Neighbors (KNN) pipeline then executes high-speed, rotation-invariant classification on the
The area is divided into a grid of cells, where each cell stores information such as explored zones, tile types,
detected blob. By offloading the initial shape detection to the edge co-processor, the Raspberry Pi's CPU
and walls. Python handles logging this data and updating the map with every forward step, marking features
overhead is minimized, dedicating its multi-threaded architecture strictly to classification and pathfinding. This
encountered along the way. This enables the robot to avoid previously visited areas, choose more efficient
distributed approach ensures deterministic real-time processing, allowing the master system to instantly
routes using Dijkstra algorithm, and plan the optimal path to the goal. Ultimately, this mapping system is an
update the maze navigation matrix or execute corresponding victim-handling routines without continuosly
essential tool for autonomous navigation, allowing the robot to orient itself and make real-time decisions
halting the robot's exploration.
based on exploration data.
Modello 3D PCB Github
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Read the text of this document — 1177 words
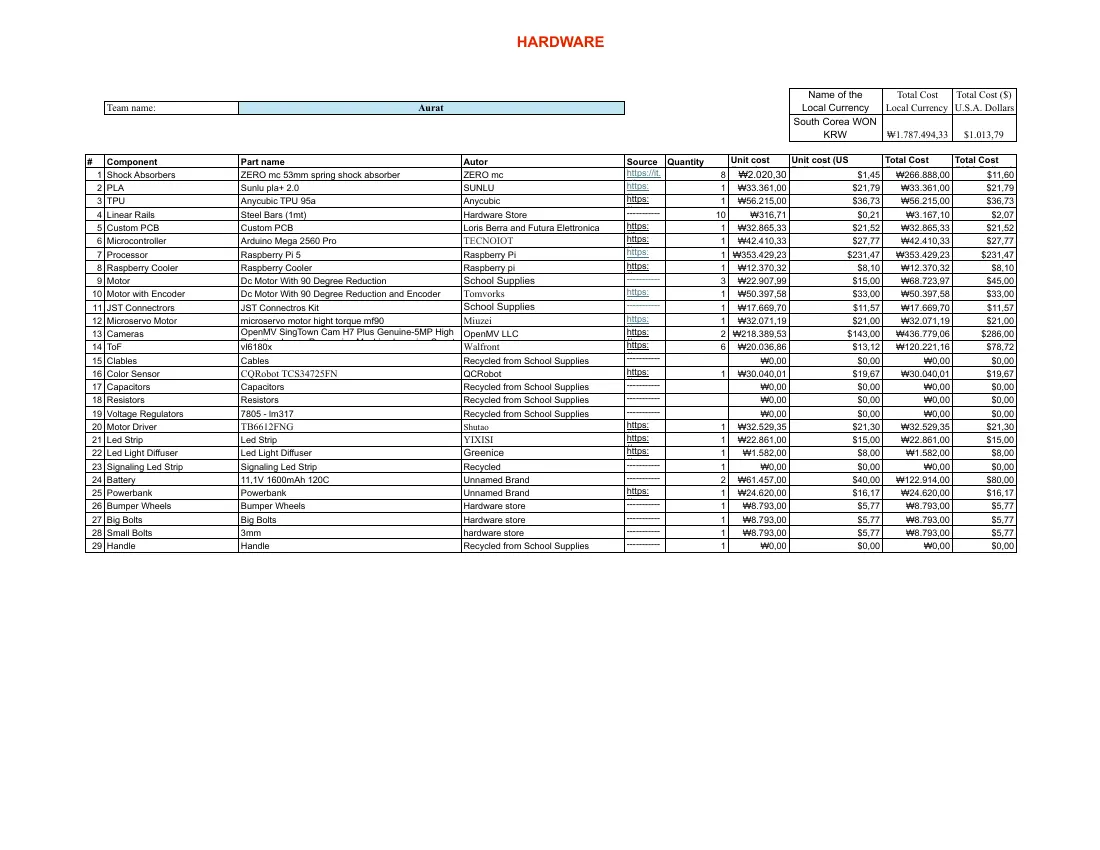
HARDWARE
Name of the Total Cost Total Cost ($)
Team name: Aurat Local Currency Local Currency U.S.A. Dollars
South Corea WON
KRW ₩1.787.494,33 $1.013,79
# Component Part name Autor Source Quantity Unit cost Unit cost (US Total Cost Total Cost
https://it. (Local Dollars) (Local (USA Dollars)
1 Shock Absorbers ZERO mc 53mm spring shock absorber ZERO mc 8 ₩2.020,30 $1,45 ₩266.888,00 $11,60
aliexpre Currency) Currency)
2 PLA Sunlu pla+ 2.0 SUNLU https: 1 ₩33.361,00 $21,79 ₩33.361,00 $21,79
ss.
//www.
3 TPU Anycubic TPU 95a Anycubic https: 1 ₩56.215,00 $36,73 ₩56.215,00 $36,73
com/ite
amazon.
//www.
-----------
4 Linear Rails Steel Bars (1mt) Hardware Store m/10050
it/SUNL 10 ₩316,71 $0,21 ₩3.167,10 $2,07
-amazon.
0931280
https:
5 Custom PCB Custom PCB Loris Berra and Futura Elettronica U-PLA-
it/ANYC 1 ₩32.865,33 $21,52 ₩32.865,33 $21,52
9629.
//futuran
Aggiorn
https:
6 Microcontroller Arduino Mega 2560 Pro TECNOIOT UBIC-
html?
1 ₩42.410,33 $27,77 ₩42.410,33 $27,77
et.it/?
amento-
//www.
7 Processor Raspberry Pi 5 Raspberry Pi Filament
https: 1 ₩353.429,23 $231,47 ₩353.429,23 $231,47
spm=a2
utm_sou
resisten
amazon.
o-
//www.
https:
8 Raspberry Cooler Raspberry Cooler Raspberry pi g0o.
rce=goo
za-
it/TECN 1 ₩12.370,32 $8,10 ₩12.370,32 $8,10
Stampa
amazon.
//amzn.
9 Motor Dc Motor With 90 Degree Reduction School Supplies productli
gle&utm
-----------
dimensi
OIOT- 3 ₩22.907,99 $15,00 ₩68.723,97 $45,00
nte-
it/Raspb
-eu/d/0f4I
st.main.
_mediu
onale/dp
Integrat
https:
10 Motor with Encoder Dc Motor With 90 Degree Reduction and Encoder Tomvorks Precisio
erry-Pi-
Xp9J
9.14
m=cpc&
1 ₩50.397,58 $33,00 ₩50.397,58 $33,00
/B0DHC
o-
//amzn.
ne-
Quad-
11 JST Connectrors JST Connectros Kit School Supplies -----------
c8NSDV
utm_ca 1 ₩17.669,70 $11,57 ₩17.669,70 $11,57
T8YDN/r
ATMEG
eu/d/05s
Dimensi
-Core-
https:
NSDVy
12 Microservo Motor microservo motor hight torque mf90 Miuzei mpaign=
ef=sr_1_
A2560-
sAVJy
onale/dp
ARMA7
1 ₩32.071,19 $21,00 ₩32.071,19 $21,00
OpenMV SingTown Cam H7 Plus Genuine-5MP High //amzn.
W&algo
Sales-
https:
6?
16AU-
13 Cameras OpenMV LLC /B0DJR
6- 2 ₩218.389,53 $143,00 ₩436.779,06 $286,00
Definition Image Processing Machine Learning Smart eu/d/0h
_pvid=8
Perform
//amzn.
__mk_it
intestazi
14 ToF vl6180x Walfront https:
FVLLS/r
Bits/dp/ 6 ₩20.036,86 $13,12 ₩120.221,16 $78,72
Camera Robotics OpenMV4 H7 Plus Tp07bJ
ddbed9f
ance%
eu/d/0c
_IT=%
oni-
//amzn.
ef=sr_1_
B0CK2F
-----------
15 Clables Cables Recycled from School Supplies -b614-
20Rema
mwMCo
C3%
Maschili/ ₩0,00 $0,00 ₩0,00 $0,00
eu/d/05h
7?
CG1K?
-rketing&
16 Color Sensor CQRobot TCS34725FN QCRobot 4ec8-
https:
9
85M%
dp/B098 1 ₩30.040,01 $19,67 ₩30.040,01 $19,67
MhN99
__mk_it
ref_=ast
927e-
//amzn.
gad_sou
C3%
-----------
R819XX
17 Capacitors Capacitors Recycled from School Supplies _IT=%
_sto_dp ₩0,00 $0,00 ₩0,00 $0,00
1132dc5
-eu/d/06
rce=1&g
85%
/ref=sr_
18 Resistors Resistors Recycled from School Supplies C3%
-----------
&th=1 ₩0,00 $0,00 ₩0,00 $0,00
d1edd&
mdHe0o
ad_cam
C5%
1_2?
-85M%
-----------
algo_ex
19 Voltage Regulators 7805 - lm317 Recycled from School Supplies paignid=
BD%
__mk_it ₩0,00 $0,00 ₩0,00 $0,00
C3%
-1732693
20 Motor Driver TB6612FNG Shutao p_id=8d
https:
C3%
_IT=% 1 ₩32.529,35 $21,30 ₩32.529,35 $21,30
85%
dbed9f-
7709&g
//amzn.
95%
C3%
https:
21 Led Strip Led Strip YIXISI C5%
b614- 1 ₩22.861,00 $15,00 ₩22.861,00 $15,00
braid=0
eu/d/0g
C3%
85M%
//amzn.
22 Led Light Diffuser Led Light Diffuser Greenice BD%
https: 1 ₩1.582,00 $8,00 ₩1.582,00 $8,00
4ec8-
AAAAA
OsFsDG
91&crid
C3%
eu/d/090
C3%
//www.
-----------
23 Signaling Led Strip Signaling Led Strip Recycled 927e-
D_OkO
=2EYG
85%
KGGif 1 ₩0,00 $0,00 ₩0,00 $0,00
95%
amazon.
------------
1132dc5
NBCr4k
HXAFX
C5%
24 Battery 11,1V 1600mAh 120C Unnamed Brand C3%
it/Profilo 2 ₩61.457,00 $40,00 ₩122.914,00 $80,00
d1edd-
PPNK81
-BD%
DF6L&di
25 Powerbank Powerbank Unnamed Brand https:
-91&crid 1 ₩24.620,00 $16,17 ₩24.620,00 $16,17
8&pdp_
cqaGbW
b=eyJ2Ij
C3%
//amzn.
=3LLDM
allumini
-----------
26 Bumper Wheels Bumper Wheels Hardware store ext_f=%
Kd1Xn&
oiMSJ9.
95% 1 ₩8.793,00 $5,77 ₩8.793,00 $5,77
eu/d/07
M78PC8
-o-
27 Big Bolts Big Bolts Hardware store 7B%
-----------
gclid=Cj
4aBIpsa
C3% 1 ₩8.793,00 $5,77 ₩8.793,00 $5,77
DUdskl
GB&dib
diffusore
22order
-0KCQjwl
cbOrPI0
-----------
91&crid
28 Small Bolts 3mm hardware store =eyJ2Ijo
-striscia- 1 ₩8.793,00 $5,77 ₩8.793,00 $5,77
%22%
qTRBhC
FFgEI1
-=ER8ID
29 Handle Handle Recycled from School Supplies iMSJ9.
-----------
metri/dp/ 1 ₩0,00 $0,00 ₩0,00 $0,00
3A%
BARIsA
Drng8N
QVHRT
-7
-B00RH4
22203%
Nrkrxjs8
Oy3IzT
HV&dib
DQMEj_
10SS/ref
22%
YCvfwf
C7m5R
=eyJ2Ijo
VblAJsq
=sr_1_1
2C%
WgInaM
HXO2Td
iMSJ9.
fmXFcm
_sspa?
22spu_b
3yk9fPE
zQPge0
kTXdLvz
FD0RH3
__mk_it
est_type
rWmTge
QkaB_6
BrRKEz
v-
_IT=%
%22%
XzRjnw
92chs_h
gwfQlSp
0MIWaX
C3%
3A%
_1eSkC
kZCUPz
oCayYm
QJQSR
85M%
22price
xO2Ewf
P6-
l1fav3S
UEP0iV
C3%
%22%
nK8rLlw
CP6UvX
GZu6Ui
97HTaT
85%
2C%
aAl7SE
_PQA5c
_gEvZ2
ZooImO
C5%
22eval%
ALw_wc
rATQ_W
RY5Q8
FdA5KI_
BD%
22%
B
NdOcXI
P1pOlT
dFeknfc
C3%
3A%
wpYSsA
UsDK86
gyDJGn
95%
221%
xG8ISrf
YYPuAI
e129aB
C3%
22%
qcQu4E
m5fWJT
dHyljFm
91&crid
2C%
MeCKYt
_yBV5G
vz9bhn7
=1XQXX
22fromP
OkZ2ap
5qlumO
64G2Ha
1O3UJI
age%
R3ACG
s4SG4l
OxJAzn
7T&dib=
22%
8DazrM
HnMXvp
3Qn6kp
eyJ2Ijoi
3A%
DUQzY
FXNga1
cw2TurL
MSJ9.
22searc
25kFLLI
8WMbNj
FSYxmb
uE-
h%22%
L449jyjD
sZDk62
4zOsXj
NMnWO
7D&pdp
rYxxO4z
7BwOy7
OkIrhjvV
Nk2-
_npi=6%
QpDHe
KRdk-
heyd-
s_NIIj3R
40dis%
Ss2xO
mkhv32
SwckUl
mCCPf
21EUR
WBdrAH
_cOAQ
T5MLYA
D6W2V
%
2JVrkQu
PC5JpT
hFd9G2
oEnZIbJ
2111.00
Vh4AjF5
A94eTT
LFEm0B
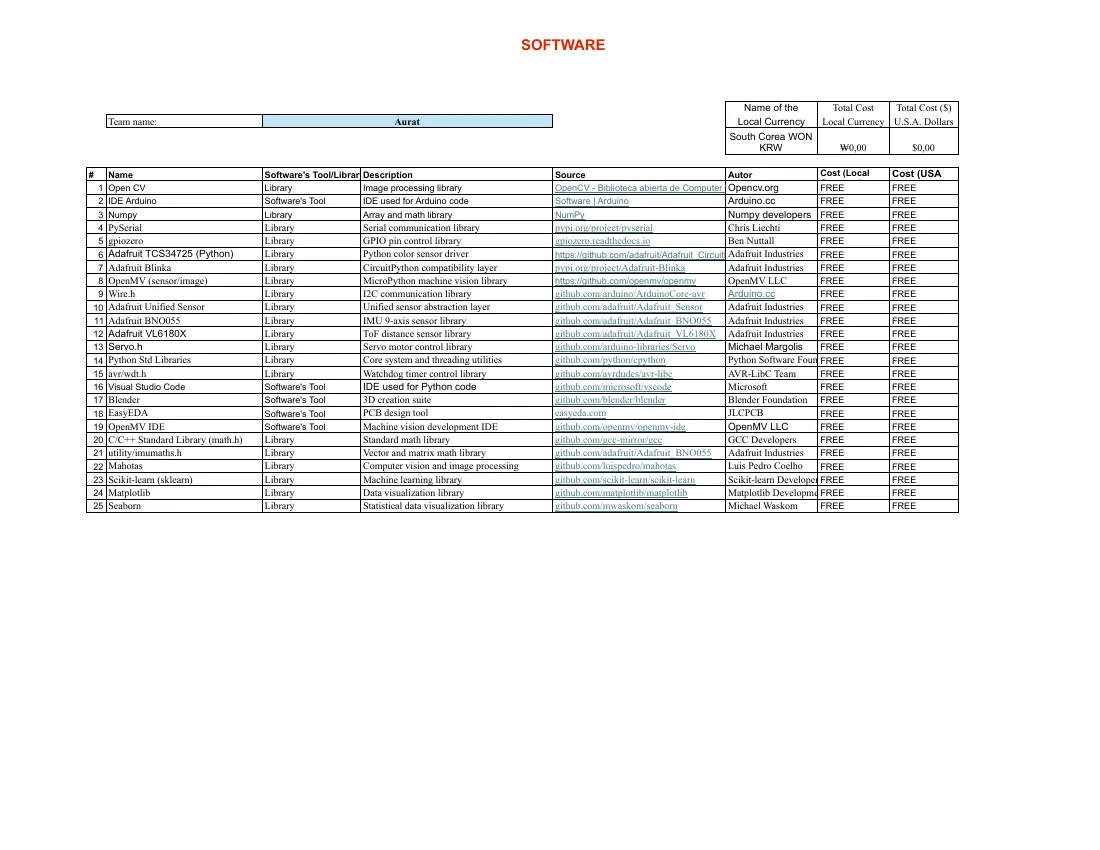
SOFTWARE
Name of the Total Cost Total Cost ($)
Team name: Aurat Local Currency Local Currency U.S.A. Dollars
South Corea WON
KRW ₩0,00 $0,00
# Name Software's Tool/LibraryDescription Source Autor Cost (Local Cost (USA
Currency) Dollars)
1 Open CV Library Image processing library Opencv.org
OpenCV - Biblioteca abierta de Computer Vision FREE FREE
2 IDE Arduino Software's Tool IDE used for Arduino code Software | Arduino Arduino.cc FREE FREE
3 Numpy Library Array and math library NumPy Numpy developers FREE FREE
4 PySerial Library Serial communication library pypi.org/project/pyserial Chris Liechti FREE FREE
5 gpiozero Library GPIO pin control library gpiozero.readthedocs.io Ben Nuttall FREE FREE
6 Adafruit TCS34725 (Python) Library Python color sensor driver Adafruit Industries
https://github.com/adafruit/Adafruit_CircuitPython_TCS34725 FREE FREE
7 Adafruit Blinka Library CircuitPython compatibility layer pypi.org/project/Adafruit-Blinka Adafruit Industries FREE FREE
8 OpenMV (sensor/image) Library MicroPython machine vision library https://github.com/openmv/openmv OpenMV LLC FREE FREE
9 Wire.h Library I2C communication library github.com/arduino/ArduinoCore-avr Arduino.cc FREE FREE
10 Adafruit Unified Sensor Library Unified sensor abstraction layer github.com/adafruit/Adafruit_Sensor Adafruit Industries FREE FREE
11 Adafruit BNO055 Library IMU 9-axis sensor library github.com/adafruit/Adafruit_BNO055 Adafruit Industries FREE FREE
12 Adafruit VL6180X Library ToF distance sensor library github.com/adafruit/Adafruit_VL6180X Adafruit Industries FREE FREE
13 Servo.h Library Servo motor control library github.com/arduino-libraries/Servo Michael Margolis FREE FREE
14 Python Std Libraries Library Core system and threading utilities github.com/python/cpython Python Software Foundation
FREE FREE
15 avr/wdt.h Library Watchdog timer control library github.com/avrdudes/avr-libc AVR-LibC Team FREE FREE
16 Visual Studio Code Software's Tool IDE used for Python code github.com/microsoft/vscode Microsoft FREE FREE
17 Blender Software's Tool 3D creation suite github.com/blender/blender Blender Foundation FREE FREE
18 EasyEDA Software's Tool PCB design tool easyeda.com JLCPCB FREE FREE
19 OpenMV IDE Software's Tool Machine vision development IDE github.com/openmv/openmv-ide OpenMV LLC FREE FREE
20 C/C++ Standard Library (math.h) Library Standard math library github.com/gcc-mirror/gcc GCC Developers FREE FREE
21 utility/imumaths.h Library Vector and matrix math library github.com/adafruit/Adafruit_BNO055 Adafruit Industries FREE FREE
22 Mahotas Library Computer vision and image processing github.com/luispedro/mahotas Luis Pedro Coelho FREE FREE
23 Scikit-learn (sklearn) Library Machine learning library github.com/scikit-learn/scikit-learn Scikit-learn DevelopersFREE FREE
24 Matplotlib Library Data visualization library github.com/matplotlib/matplotlib Matplotlib Development Team
FREE FREE
25 Seaborn Library Statistical data visualization library github.com/mwaskom/seaborn Michael Waskom FREE FREE
2 pages, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Team description paper
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Source code
The team's own source code, 20 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.