
TPA Thailand RLine
Document register
- Poster1 pagePublished
- Presentation videoNot shared
- Bill of materials39 KBPublished
- Team description paperNot shared
- Engineering journalNot shared
- Source codeNot shared
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
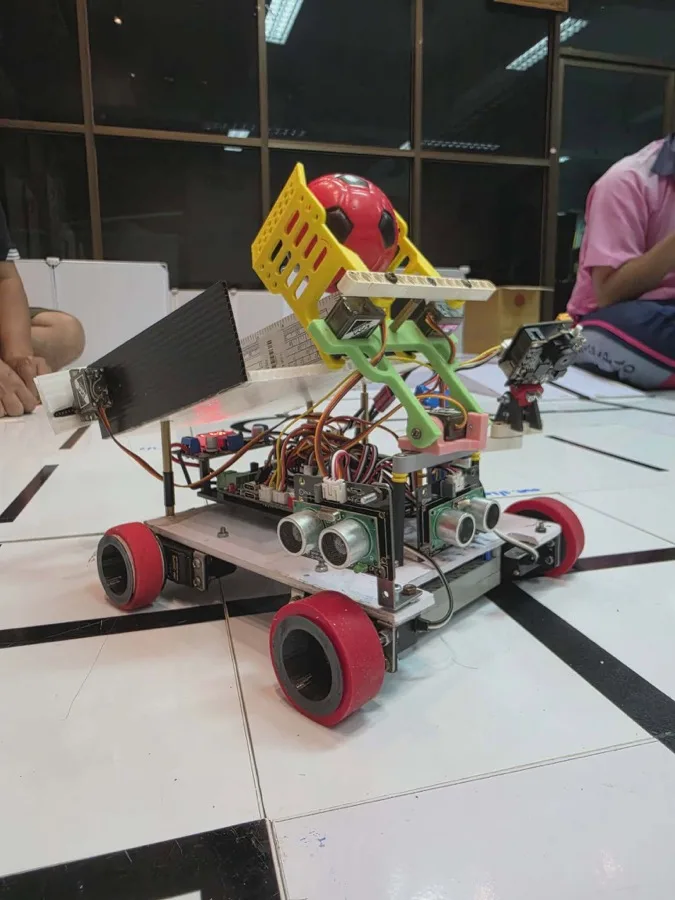
Our Rescue Line robot was developed with the objective of achieving reliable and competitive performance while making efficient use of the components and resources available to our team. Instead of relying on expensive or highly specialized hardware, we focused on optimizing the design, integration, and functionality of existing components to complete competition tasks effectively.
The robot is capable of accurate line following using a PID control system, allowing it to navigate the course with stability and precision. A camera system is utilized for rescue ball detection and color recognition, enabling the robot to identify and handle rescue objects efficiently. In addition, a ZX-Sonar1M ultrasonic sensor is integrated for obstacle avoidance and wall detection, improving the robot’s environmental awareness and decision-making capabilities.
The rescue mechanism consists of a servo-driven gripper and storage system that can collect and release rescue balls reliably in the designated rescue area. Throughout the development process, continuous testing and refinement were conducted to improve both hardware and software performance.
What sets our robot apart is our ability to achieve effective and dependable performance using limited resources. This project demonstrates that careful planning, efficient integration, and strong teamwork can produce a capable Rescue Line robot that performs competitively alongside robots equipped with more advanced hardware.
Poster
Read the text of this document — 152 words
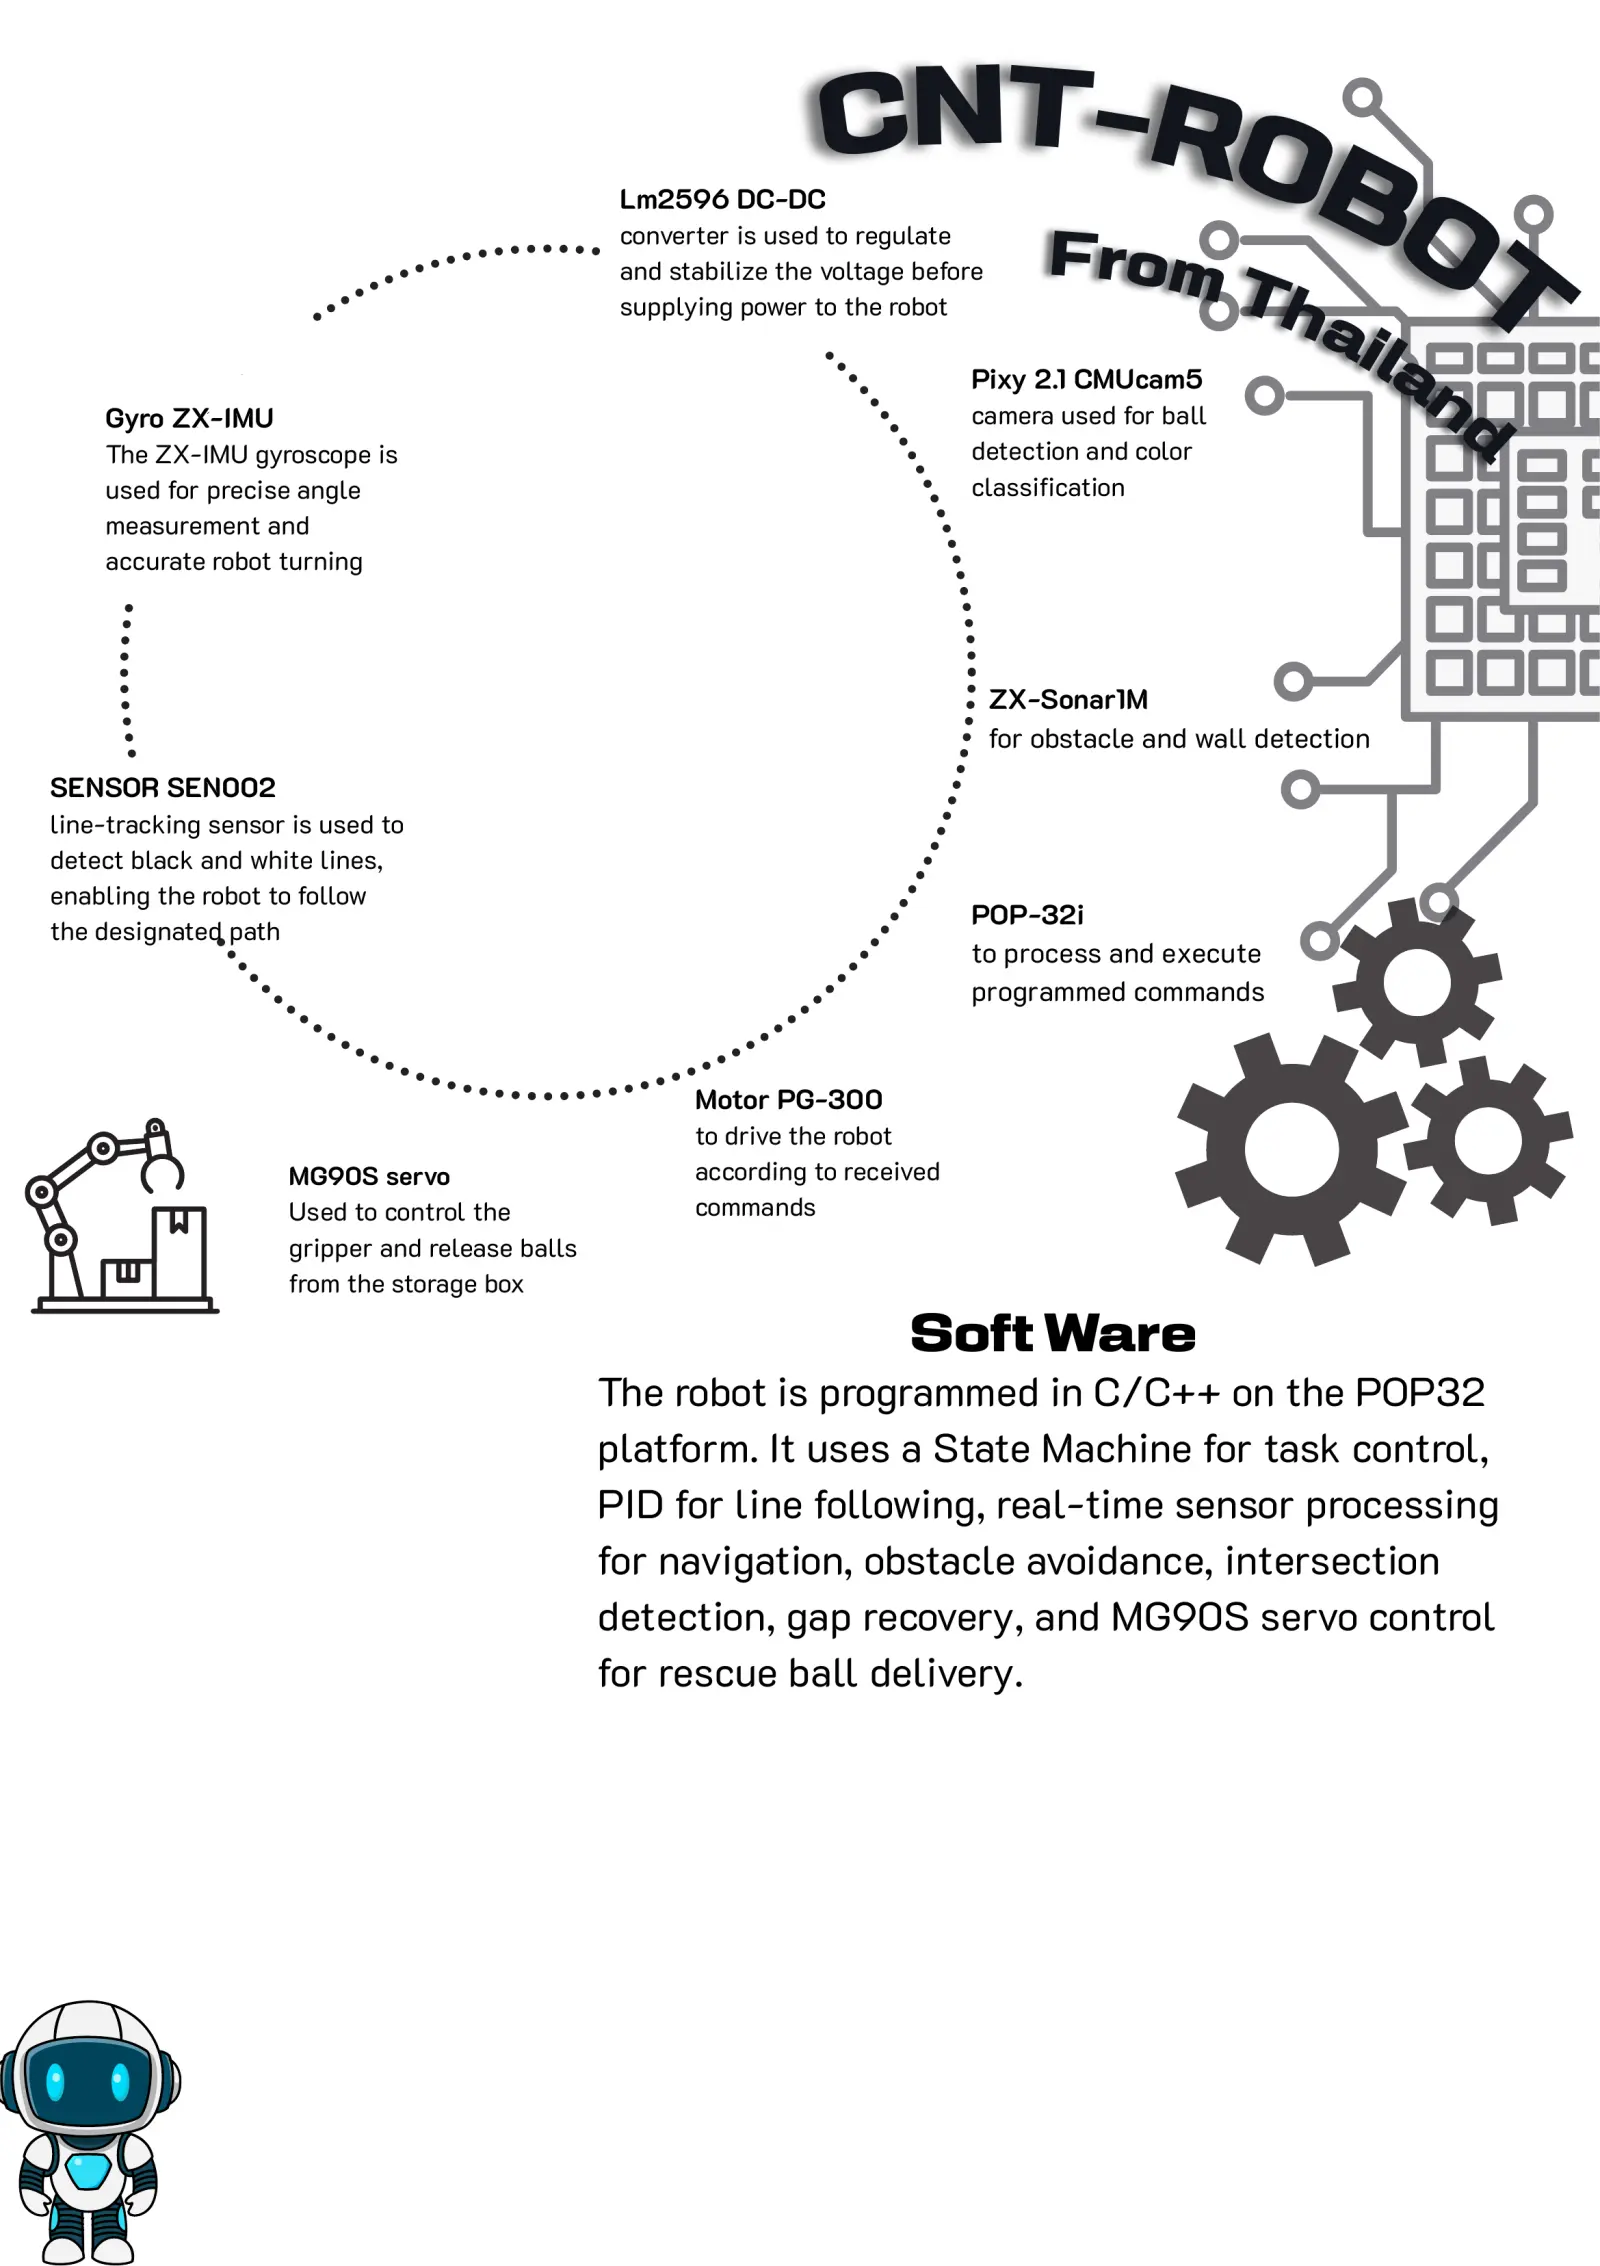
CNT -RO
                                                 Lm2596 DC-DC               BO
                                                                     From
                                                 converter is used to regulate

                                                                          Th  T
                                                 and stabilize the voltage before

                                                                            a
                                                 supplying power to the robot
                                                                                                                 ila
    Gyro ZX-IMU
                                                                               Pixy 2.1 CMUcam5
                                                                               camera used for ball
                                                                                                                    nd
    The ZX-IMU gyroscope is                                                    detection and color
    used for precise angle                                                     classification
    measurement and
    accurate robot turning

                                                                                    ZX-Sonar1M
                                                                                    for obstacle and wall detection
SENSOR SEN002
line-tracking sensor is used to
detect black and white lines,
enabling the robot to follow
                                                                               POP-32i
the designated path
                                                                               to process and execute
                                                                               programmed commands

                                                       Motor PG-300
                                                       to drive the robot
                    MG90S servo                        according to received
                    Used to control the                commands
                    gripper and release balls
                    from the storage box

                                                                          Soft Ware
                                                The robot is programmed in C/C++ on the POP32
                                                platform. It uses a State Machine for task control,
                                                PID for line following, real-time sensor processing
                                                for navigation, obstacle avoidance, intersection
                                                detection, gap recovery, and MG90S servo control
                                                for rescue ball delivery.
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Bill of materials
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.