
Smart
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials22 KBPublished
- Team description paperNot shared
- Engineering journalNot shared
- Source code173 KB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
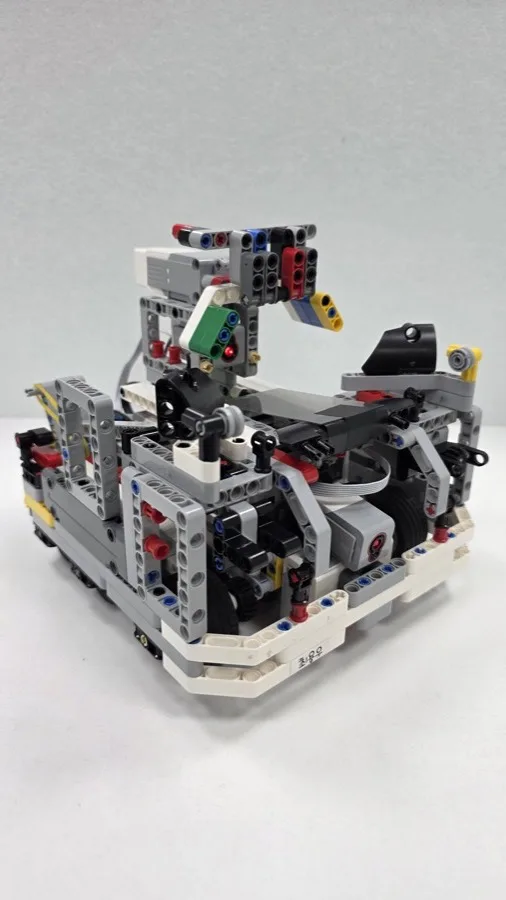
Our robot is driven by two medium motors positioned on both sides. Two ground-facing color sensors installed on each side enable the robot to track the black line precisely. Additionally, by equipping an extra color sensor at the front for obstacle detection, we successfully completed the obstacle avoidance mission. Adopting a 6-wheel base enhanced our grip, allowing the robot to navigate slopes up and down with ease. Thanks to its smooth rotation, it performs turns on inclines much more stably than other teams' robots. We designed a robotic arm specifically capable of gripping ball-shaped victims (the primary mission objects) and utilized a medium motor to actuate it upward and downward. Furthermore, we created a designated payload space on top of the robot to secure the victims, along with a mechanism to distinguish between the alive and the deceased. By efficiently integrating the robotic arm with this containment and sorting space, we were able to pass through the evacuation zone much more smoothly than competing teams.
Poster
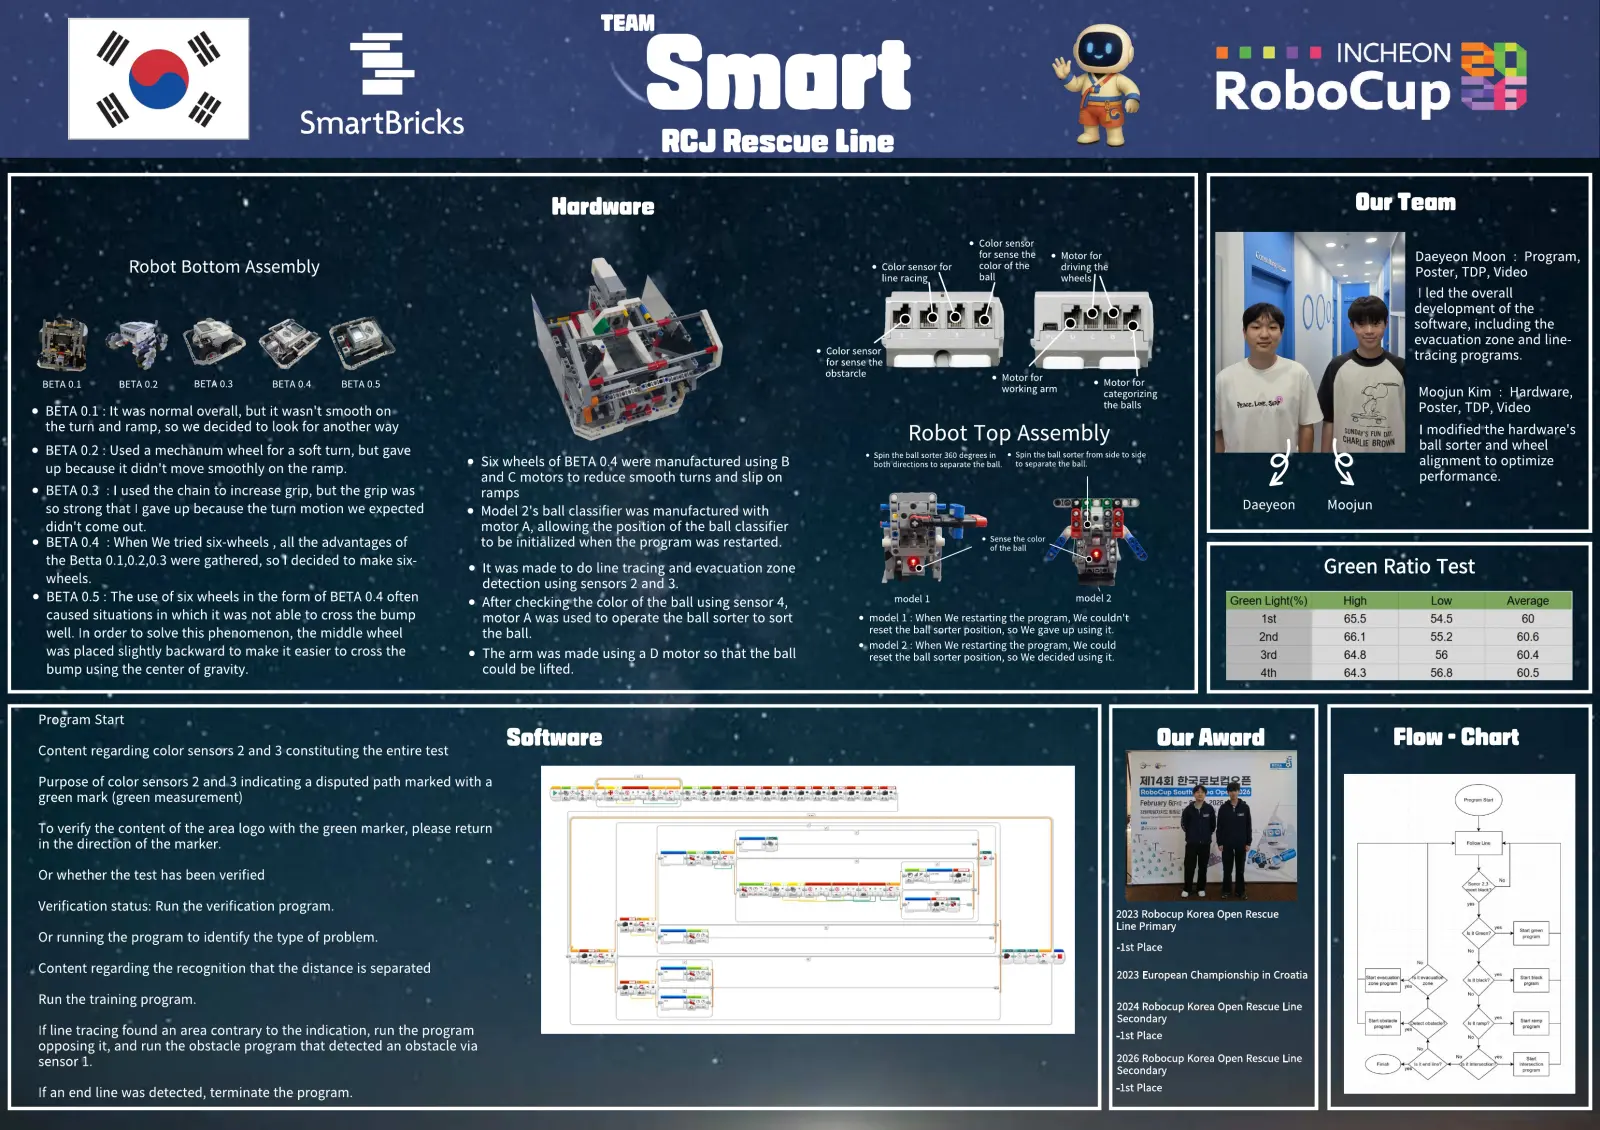
1 page, rendered as images so they load quickly. This document has no text layer — the words in it are part of the image.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Source code
The team's own source code, 173 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.