
QuantumSpeed
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials1 pagePublished
- Team description paper543 KBPublished
- Engineering journalNot shared
- Source code7.9 MB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
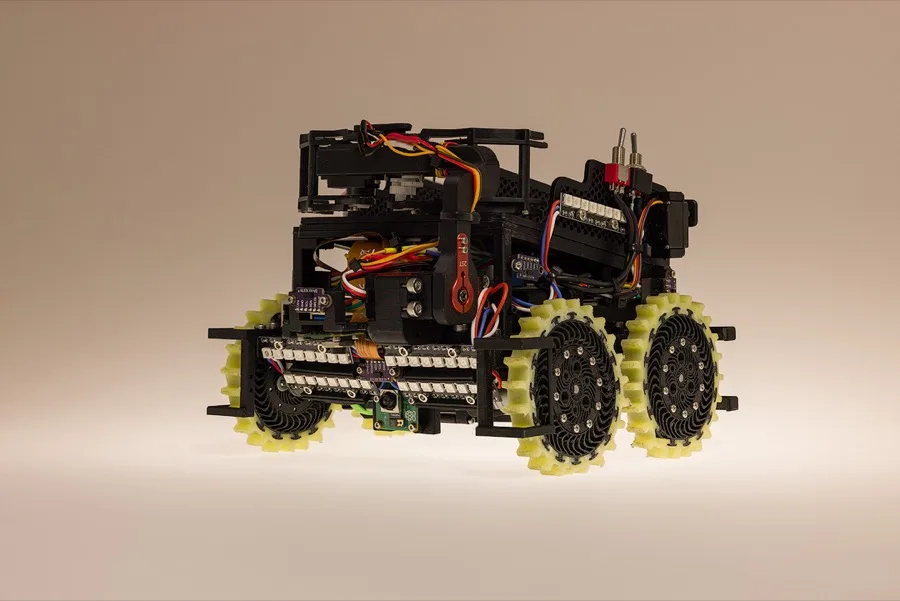
The robot is designed to compete in the RoboCupJunior Rescue Line. We have been working for almost three years to create a robot capable of overcoming all the challenges presented by the competition. Over time, the robot has undergone numerous modifications: we have added artificial intelligence systems; we have increased the number of sensors; we have used better and more suitable sensors for our goals and we have furthermore improved our mechanical components by the addition of a brand new tire system built from scratch. Thanks to these improvements, the robot has significantly enhanced its performance, demonstrating greater reliability in handling complex line-following sections and improved capability in overcoming physically challenging elements of the course. The entire robot was designed in 3D using Fusion 360.
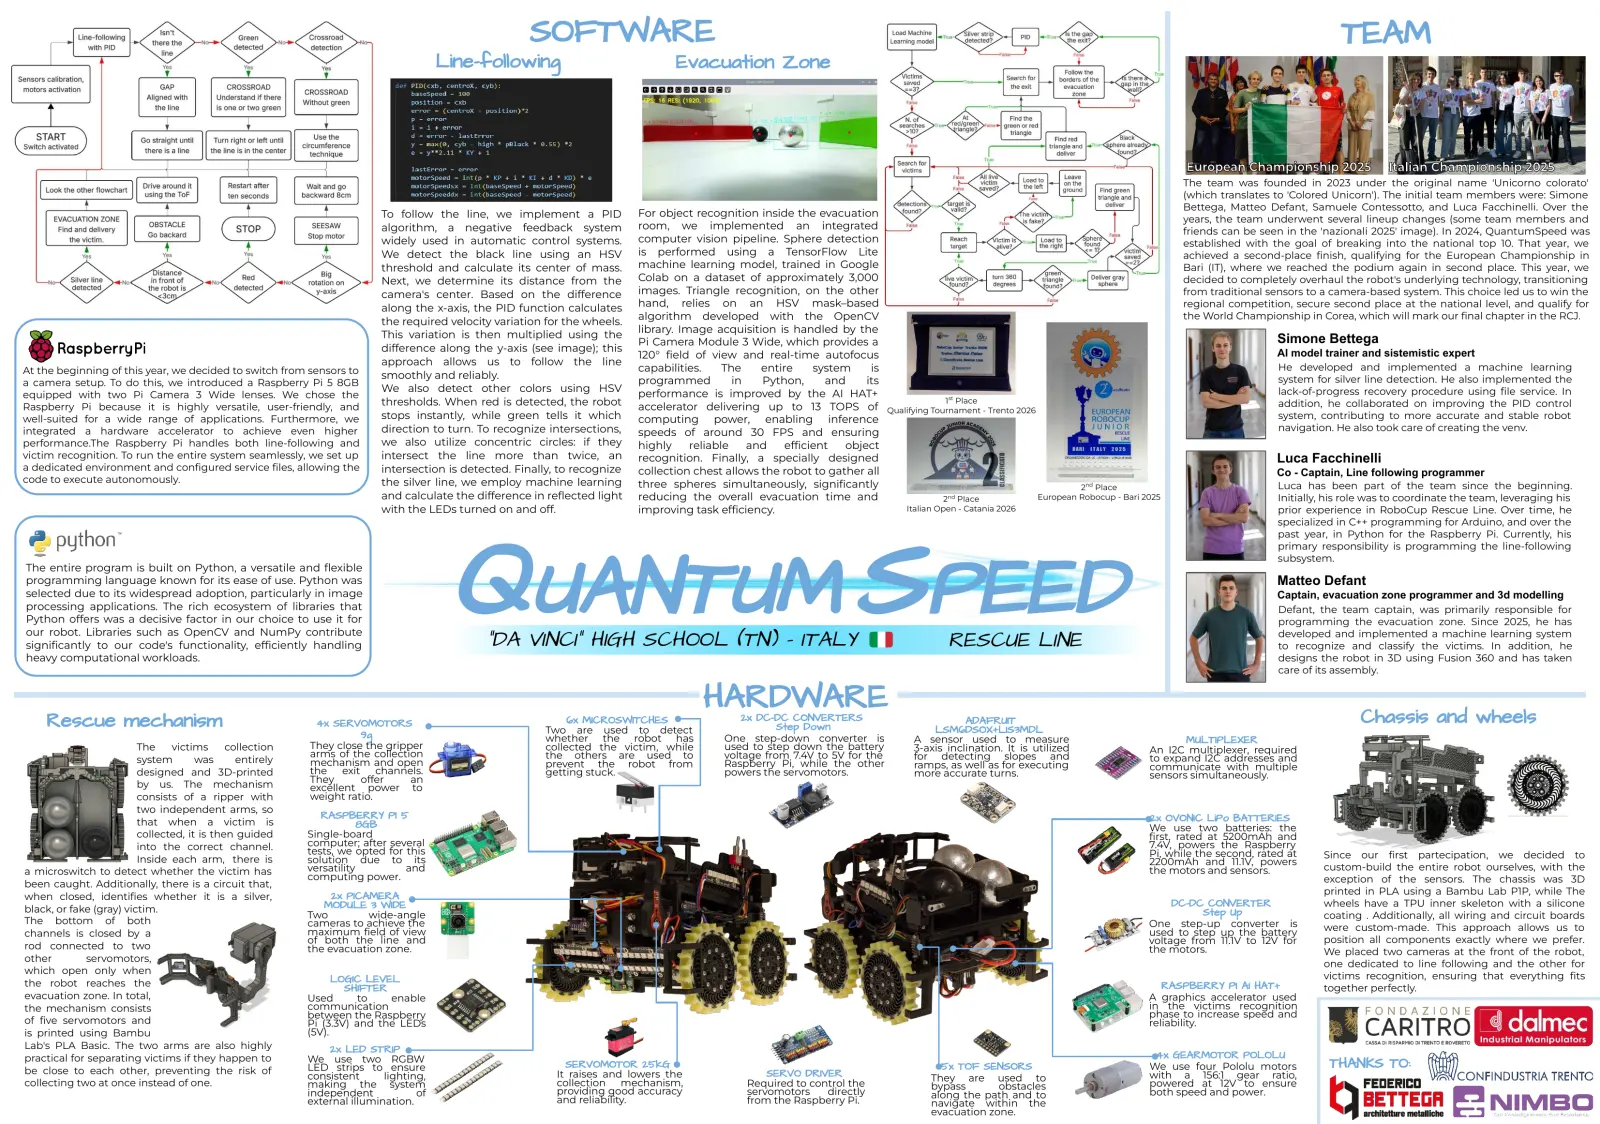
To achieve greater reliability, we decided to rely only on one microcontroller, getting rid of the old serial communication system. In fact, all the computations are done by a Raspberry Pi 5, programmed in Python, connected to a Pi camera, which is used to identify and follow the line, using the tools provided by the OpenCV library, additionally the camera is used to manage the evacuation zone, recognizing the entrance and the exit of it. The Raspberry is also connected to an AI hat, using a model trained with TensorFlow Lite, it is able to recognize victims and evacuation points in the evacuation zone using a second vertical Pi camera.
Poster
Read the text of this document — 1395 words
SOFTWARE TEAM
Line-following Evacuation Zone
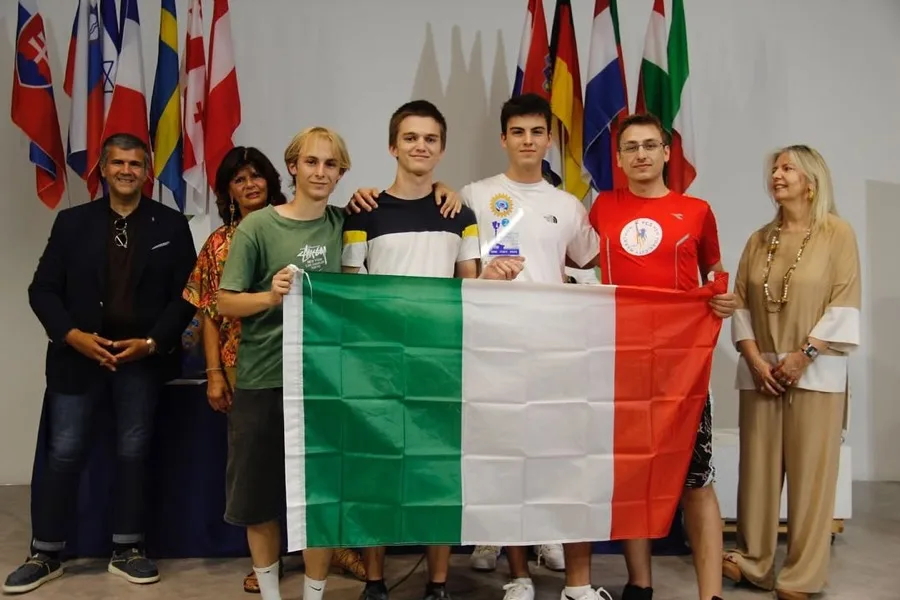
The team was founded in 2023 under the original name 'Unicorno colorato'
(which translates to 'Colored Unicorn'). The initial team members were: Simone
Bettega, Matteo Defant, Samuele Contessotto, and Luca Facchinelli. Over the
To follow the line, we implement a PID For object recognition inside the evacuation
years, the team underwent several lineup changes (some team members and
algorithm, a negative feedback system room, we implemented an integrated friends can be seen in the 'nazionali 2025' image). In 2024, QuantumSpeed was
widely used in automatic control systems. computer vision pipeline. Sphere detection established with the goal of breaking into the national top 10. That year, we
We detect the black line using an HSV is performed using a TensorFlow Lite achieved a second-place finish, qualifying for the European Championship in
threshold and calculate its center of mass. machine learning model, trained in Google Bari (IT), where we reached the podium again in second place. This year, we
Next, we determine its distance from the Colab on a dataset of approximately 3,000 decided to completely overhaul the robot's underlying technology, transitioning
camera's center. Based on the difference images. Triangle recognition, on the other from traditional sensors to a camera-based system. This choice led us to win the
along the x-axis, the PID function calculates hand, relies on an HSV mask–based regional competition, secure second place at the national level, and qualify for
the required velocity variation for the wheels. algorithm developed with the OpenCV the World Championship in Corea, which will mark our final chapter in the RCJ.
library. Image acquisition is handled by the
This variation is then multiplied using the Simone Bettega
Pi Camera Module 3 Wide, which provides a
difference along the y-axis (see image); this AI model trainer and sistemistic expert
120° field of view and real-time autofocus
approach allows us to follow the line He developed and implemented a machine learning
At the beginning of this year, we decided to switch from sensors to capabilities. The entire system is
smoothly and reliably. system for silver line detection. He also implemented the
a camera setup. To do this, we introduced a Raspberry Pi 5 8GB programmed in Python, and its
We also detect other colors using HSV performance is improved by the AI HAT+ lack-of-progress recovery procedure using file service. In
equipped with two Pi Camera 3 Wide lenses. We chose the
Raspberry Pi because it is highly versatile, user-friendly, and thresholds. When red is detected, the robot accelerator delivering up to 13 TOPS of
1st Place addition, he collaborated on improving the PID control
Qualifying Tournament - Trento 2026
well-suited for a wide range of applications. Furthermore, we stops instantly, while green tells it which computing power, enabling inference system, contributing to more accurate and stable robot
integrated a hardware accelerator to achieve even higher direction to turn. To recognize intersections, speeds of around 30 FPS and ensuring navigation. He also took care of creating the venv.
performance.The Raspberry Pi handles both line-following and we also utilize concentric circles: if they highly reliable and efficient object
victim recognition. To run the entire system seamlessly, we set up intersect the line more than twice, an recognition. Finally, a specially designed Luca Facchinelli
a dedicated environment and configured service files, allowing the intersection is detected. Finally, to recognize collection chest allows the robot to gather all Co - Captain, Line following programmer
code to execute autonomously. the silver line, we employ machine learning three spheres simultaneously, significantly 2nd Place Luca has been part of the team since the beginning.
and calculate the difference in reflected light reducing the overall evacuation time and nd
2 Place European Robocup - Bari 2025 Initially, his role was to coordinate the team, leveraging his
with the LEDs turned on and off. improving task efficiency. Italian Open - Catania 2026 prior experience in RoboCup Rescue Line. Over time, he
Q UANTUM S PEED
specialized in C++ programming for Arduino, and over the
past year, in Python for the Raspberry Pi. Currently, his
primary responsibility is programming the line-following
subsystem.
The entire program is built on Python, a versatile and flexible
programming language known for its ease of use. Python was Matteo Defant
selected due to its widespread adoption, particularly in image Captain, evacuation zone programmer and 3d modelling
processing applications. The rich ecosystem of libraries that Defant, the team captain, was primarily responsible for
Python offers was a decisive factor in our choice to use it for programming the evacuation zone. Since 2025, he has
our robot. Libraries such as OpenCV and NumPy contribute
significantly to our code's functionality, efficiently handling “DA VINCI” HIGH SCHOOL (TN) - ITALY RESCUE LINE developed and implemented a machine learning system
to recognize and classify the victims. In addition, he
heavy computational workloads. designs the robot in 3D using Fusion 360 and has taken
care of its assembly.
HARDWARE Chassis and wheels
Rescue mechanism 4x SERVOMOTORS 6x MICROSWITCHES
Two are used to detect
2x DC-DC CONVERTERS
Step Down
ADAFRUIT
LSM6DSOX+LIS3MDL
9g whether the robot has One step-down converter is A sensor used to measure MULTIPLEXER
The victims collection They close the gripper collected the victim, while used to step down the battery 3-axis inclination. It is utilized An I2C multiplexer, required
arms of the collection the others are used to voltage from 7.4V to 5V for the for detecting slopes and to expand I2C addresses and
system was entirely mechanism and open prevent the robot from Raspberry Pi, while the other ramps, as well as for executing communicate with multiple
designed and 3D-printed the exit channels. getting stuck. powers the servomotors. more accurate turns. sensors simultaneously.
They offer an
by us. The mechanism excellent power to
consists of a ripper with weight ratio.
two independent arms, so
RASPBERRY PI 5 2x OVONIC LiPo BATTERIES
that when a victim is 8GB We use two batteries: the
collected, it is then guided Single-board first, rated at 5200mAh and
into the correct channel. computer; after several 7.4V, powers the Raspberry
tests, we opted for this Pi, while the second, rated at Since our first partecipation, we decided to
Inside each arm, there is solution due to its 2200mAh and 11.1V, powers
a microswitch to detect whether the victim has versatility and the motors and sensors. custom-build the entire robot ourselves, with the
computing power. exception of the sensors. The chassis was 3D
been caught. Additionally, there is a circuit that,
2x PICAMERA printed in PLA using a Bambu Lab P1P, while The
when closed, identifies whether it is a silver,
MODULE 3 WIDE DC-DC CONVERTER wheels have a TPU inner skeleton with a silicone
black, or fake (gray) victim. Step Up
Two wide-angle coating . Additionally, all wiring and circuit boards
The bottom of both cameras to achieve the One step-up converter is
maximum field of view used to step up the battery were custom-made. This approach allows us to
channels is closed by a
of both the line and voltage from 11.1V to 12V for position all components exactly where we prefer.
rod connected to two the evacuation zone. the motors. We placed two cameras at the front of the robot,
other servomotors,
one dedicated to line following and the other for
which open only when
LOGIC LEVEL victims recognition, ensuring that everything fits
the robot reaches the SHIFTER RASPBERRY PI AI HAT+ together perfectly.
evacuation zone. In total, Used to enable A graphics accelerator used
the mechanism consists communication in the victims recognition
between the Raspberry phase to increase speed and
of five servomotors and Pi (3.3V) and the LEDs reliability.
is printed using Bambu (5V).
Lab's PLA Basic. The two arms are also highly 2x LED STRIP
practical for separating victims if they happen to We use two RGBW 4x GEARMOTOR POLOLU
be close to each other, preventing the risk of LED strips to ensure SERVOMOTOR 25kG 5x TOF SENSORS We use four Pololu motors THANKS TO:
consistent lighting, It raises and lowers the SERVO DRIVER They are used to with a 156:1 gear ratio,
collecting two at once instead of one. making the system collection mechanism, Required to control the bypass obstacles powered at 12V to ensure
independent of providing good accuracy servomotors directly along the path and to both speed and power.
external illumination. and reliability. from the Raspberry Pi. navigate within the
evacuation zone.
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Read the text of this document — 1236 words
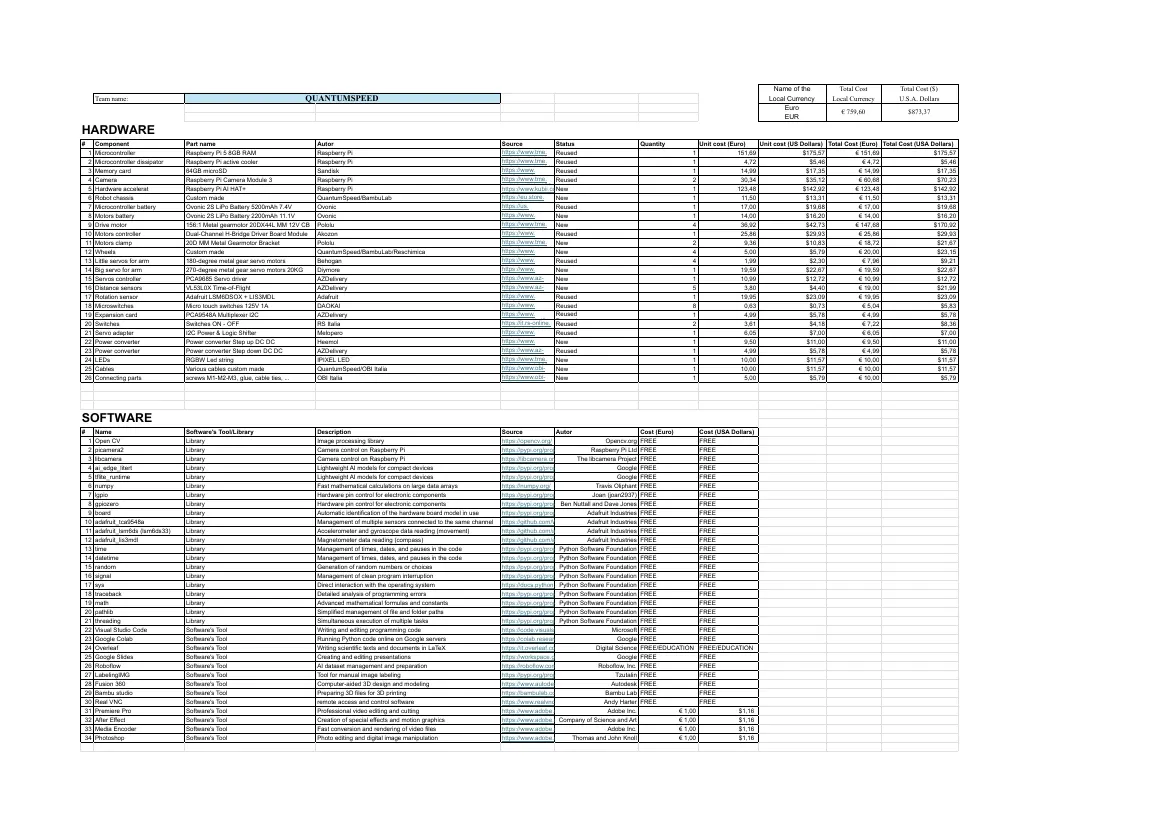
Name of the Total Cost Total Cost ($)
Team name: QUANTUMSPEED Local Currency Local Currency U.S.A. Dollars
Euro
€ 759,60 $873,37
EUR
HARDWARE
# Component Part name Autor Source Status Quantity Unit cost (Euro) Unit cost (US Dollars) Total Cost (Euro) Total Cost (USA Dollars)
1 Microcontroller Raspberry Pi 5 8GB RAM Raspberry Pi https://www.tme. Reused 1 151,69 $175,57 € 151,69 $175,57
eu/it/details/sc111
https://www.tme.
2 Microcontroller dissipator Raspberry Pi active cooler Raspberry Pi Reused 1 4,72 $5,46 € 4,72 $5,46
2/raspberry-pi-
eu/it/details/sc114
3 Memory card 64GB microSD Sandisk https://www.
minicomputer/rasp Reused
8/raspberry-pi-
1 14,99 $17,35 € 14,99 $17,35
mediaworld.
https://www.tme.
4 Camera Raspberry Pi Camera Module 3 Raspberry Pi berry-pi/raspberry-
accessori/raspberr Reused 2 30,34 $35,12 € 60,68 $70,23
it/it/product/_sche
eu/it/details/sc122
5 Hardware accelerat Raspberry Pi AI HAT+ Raspberry Pi pi-5-8gb-ram/
y-pi/raspberry-pi-
https://www.kubii.com/it/schede-integrate/4343-2136-kit-ai-ai-hat-raspberry-pi-3272496319608.html#/kit_ai_hat_raspberry_pi-cappello_ai_26_top
New 1 123,48 $142,92 € 123,48 $142,92
da-di-memoria-
4/raspberry-pi-
6 Robot chassis Custom made QuantumSpeed/BambuLab active-cooler/
https://eu.store.
sandisk-sdsqxah- New 1 11,50 $13,31 € 11,50 $13,31
accessori/raspberr
bambulab.
064g-gn6aa-
https://us.
7 Microcontroller battery Ovonic 2S LiPo Battery 5200mAh 7.4V Ovonic y-pi/camera- Reused 1 17,00 $19,68 € 17,00 $19,68
com/it/products/pl
177538.html
ovonicshop.
8 Motors battery Ovonic 2S LiPo Battery 2200mAh 11.1V Ovonic module-3-wide/
https://www. New 1 14,00 $16,20 € 14,00 $16,20
a-basic-filament?
com/products/2-
ampow.
https://www.tme.
9 Drive motor 156:1 Metal gearmotor 20DX44L MM 12V CB Pololu variant=59361122
ovonic-2s-lipo- New 4 36,92 $42,73 € 147,68 $170,92
com/it/products/ov
eu/it/details/pololu
10 Motors controller Dual-Channel H-Bridge Driver Board Module Akozon 3076515872
https://www.
battery-5200mah- Reused 1 25,86 $29,93 € 25,86 $29,93
onic-50c-7-4v-
-3480/motori-
amazon.
2s1p-7-4v-
https://www.tme.
11 Motors clamp 20D MM Metal Gearmotor Bracket Pololu 2200mah-2s1p-
dc/pololu/156-1- New 2 9,36 $10,83 € 18,72 $21,67
it/dp/B07H2MDX
hardcase-rc-lipo-
eu/en/details/polol
12 Wheels Custom made QuantumSpeed/BambuLab/Reschimica deans-2pcs-lipo-
https://www.
metal-gearmotor- New 4 5,00 $5,79 € 20,00 $23,15
MN?
battery-with-
u-
battery?
reschimica.
20dx44l-mm-12v- Reused
https://www.
13 Little servos for arm 180-degree metal gear servo motors Behogan ref=cm_sw_r_cp_
deans-t-plug-for-
1138/accessories- 4 1,99 $2,30 € 7,96 $9,21
variant=42940968
com/it/gomme-
cb/
amazon.
14 Big servo for arm 270-degree metal gear servo motors 20KG Diymore ud_dp_AGQPQZ
https://www.
1-8-1-10-rc-
for- New 1 19,59 $22,67 € 19,59 $22,67
173812
siliconiche/127-
it/dp/B0FFSTDF9
N6X7RGT8K04C
amazon.
vehicles-car-
micromotors/polol
https://www.az-
15 Servos controller PCA9685 Servo driver AZDelivery 203-r20-silicone-
5? New 1 10,99 $12,72 € 10,99 $12,72
X8&ref_=cm_sw_r
it/dp/B0BD4DDTY
trucks-airplane-
u/20d-mm-metal-
delivery.
16 Distance sensors VL53L0X Time-of-Flight AZDelivery liquido-per-
https://www.az-
ref=cm_sw_r_cp_ New 5 3,80 $4,40 € 19,00 $21,99
_cp_ud_dp_AGQ
7?
boats
gearmotor-
de/it/products/pca
stampi-di-media-
delivery.
ud_dp_CQB1HFT
https://www.
17 Rotation sensor Adafruit LSM6DSOX + LIS3MDL Adafruit PQZN6X7RGT8K
_encoding=UTF8
bracket-pair/
9685- Reused 1 19,95 $23,09 € 19,95 $23,09
durezza.
de/it/products/vl53
1AJRVF117YD1N
adafruit.
18 Microswitches Micro touch switches 125V 1A DAOKAI 04CX8&social_sh Reused
&ref=cm_sw_r_cp
https://www.
servotreiber? 8 0,63 $0,73 € 5,04 $5,83
html#8370/fullscre
l0x-time-of-flight-
&ref_=cm_sw_r_c
com/product/4517
are=cm_sw_r_cp_
_ud_dp_95BP2TJ
amazon.
variant=40364395
19 Expansion card PCA9548A Multiplexer I2C AZDelivery https://www.
en-initial/ https:
tof-laser-
p_ud_dp_CQB1H Reused 1 4,99 $5,78 € 4,99 $5,78
ud_dp_AGQPQZ
VHMEGPH8PZY
it/dp/B09WVMRD
410
google.com/url?
//eu.store.
abstandssensor?
https://it.rs-online.
FT1AJRVF117YD Reused
20 Switches Switches ON - OFF RS Italia N6X7RGT8K04C
C6&ref_=cm_sw_
5V? Reused 2 3,61 $4,18 € 7,22 $8,36
q=https://www.az-
bambulab.
variant=32344531
com/web/p/interrut
1N&social_share=
21 Servo adapter I2C Power & Logic Shifter Melopero https://www.
X8
r_cp_ud_dp_95B
_encoding=UTF8 Reused 1 6,05 $7,00 € 6,05 $7,00
delivery.
com/it/products/tp
435616
tori-a-
cm_sw_r_cp_ud_
melopero.
P2TJVHMEGPH8
&psc=1&ref=cm_s
https://www.
22 Power converter Power converter Step up DC DC Heemol de/it/products/tca9 New
u-for-ams?
levetta/7347062
dp_CQB1HFT1AJ 1 9,50 $11,00 € 9,50 $11,00
com/it/shop/melop
PZYC6&social_sh
w_r_cp_ud_dp_78
amazon.it/-
23 Power converter Power converter Step down DC DC AZDelivery 548a-i2c-iic-
https://www.az-
variant=59361470 Reused
RVF117YD1N 1 4,99 $5,78 € 4,99 $5,78
ero/meloperoi2cp
are=cm_sw_r_cp_
ZA4N0R7ACP5X
/en/Heemol-
multiplexer?
delivery.
4399167492
https://www.tme.
24 LEDs RGBW Led string IPIXEL LED owerandlogicconv New
ud_dp_95BP2TJV
PY8PCH&ref_=c
Converter- 1 10,00 $11,57 € 10,00 $11,57
variant%
de/it/products/lm2
eu/it/details/s0081
25 Cables Various cables custom made QuantumSpeed/OBI Italia erter/
https://www.obi-
HMEGPH8PZYC6
m_sw_r_cp_ud_d
Voltage- New 1 10,00 $11,57 € 10,00 $11,57
3D323443939410
596s-dc-dc-step-
44ca4s1-
italia.it/
&th=1
p_78ZA4N0R7AC New
Regulator-
https://www.obi-
88&sa=D&source
26 Connecting parts screws M1-M2-M3, glue, cable ties, ... OBI Italia down-modul-1?
rgbnw/fonti-di- 1 5,00 $5,79 € 10,00 $5,79
P5XPY8PCH&soc
Constant/dp/B0C9
italia.it/
=editors&ust=178
variant=12228728
luce-led-a-
ial_share=cm_sw
GVF9XC/ref=sr_1
1290442869682&
291424
nastro/ipixel-
_r_cp_ud_dp_78Z
_1?
usg=AOvVaw2he
led/s008144ca4sa
A4N0R7ACP5XP
crid=2IV9GG2R3
JCFae_ZrPwJzaA
1-c1-rgb-4000k-
Y8PCH
FJK4&dib=eyJ2Ijo
5rfPt
SOFTWARE ip20/
iMSJ9.
5fl_SYodjwqu6Qe
# Name Software's Tool/Library Description Source
sNKjh24RjitwgDv Autor Cost (Euro) Cost (USA Dollars)
1 Open CV Library Image processing library 2e8dcyBegynAgH
https://opencv.org/ Opencv.org FREE FREE
QfQvawvj7fGaIBjg
2 picamera2 Library Camera control on Raspberry Pi https://pypi.org/project/picamera2/ Raspberry Pi Ltd FREE FREE
PIVtWaH3Yqbg5f
3 libcamera Library Camera control on Raspberry Pi https://libcamera.org/
Uv6LntmPVmcm6 The libcamera Project FREE FREE
4 ai_edge_litert Library Lightweight AI models for compact devices https://pypi.org/project/ai-edge-litert/
VEcyZIvO6ckBrK Google FREE FREE
5 tflite_runtime Library Lightweight AI models for compact devices 6lLn6cOyQY3f2tqj
https://pypi.org/project/tflite-runtime/ Google FREE FREE
3hCioDrzzgfzwF4
6 numpy Library Fast mathematical calculations on large data arrays https://numpy.org/ Travis Oliphant FREE FREE
NUWYl7ndWGMk
7 lgpio Library Hardware pin control for electronic components https://pypi.org/project/lgpio/
OTbD_3T5Ys0ulg Joan (joan2937) FREE FREE
8 gpiozero Library Hardware pin control for electronic components 0THWAOpNuohm
https://pypi.org/project/gpiozero/
Ben Nuttall and Dave Jones FREE FREE
9 board Library Automatic identification of the hardware board model in use DihLSgSXFmZW-
https://pypi.org/project/board/ Adafruit Industries FREE FREE
22AfmykronLs_Py
10 adafruit_tca9548a Library Management of multiple sensors connected to the same channel https://github.com/WifWaf/TCA9548A
8lPqQnkn2RAWg Adafruit Industries FREE FREE
11 adafruit_lsm6ds (lsm6ds33) Library Accelerometer and gyroscope data reading (movement) https://github.com/adafruit/adafruit_lsm6ds
679XHnW4hgbaf1 Adafruit Industries FREE FREE
12 adafruit_lis3mdl Library Magnetometer data reading (compass) VOMGoAQqgbMX
https://github.com/adafruit/Adafruit_LIS3MDL
Adafruit Industries FREE FREE
ITjn1NvG0uog1tj
13 time Library Management of times, dates, and pauses in the code https://pypi.org/project/timelib/
Python Software Foundation FREE FREE
GBRIeddNadCis5
14 datetime Library Management of times, dates, and pauses in the code https://pypi.org/project/DateTime/
xub47eMzc08H88 Python Software Foundation FREE FREE
15 random Library Generation of random numbers or choices https://pypi.org/project/random-321/
TDo6uvpoKhLEIv Python Software Foundation FREE FREE
16 signal Library Management of clean program interruption Xh-SQ.
https://pypi.org/project/python-signal/
Python Software Foundation FREE FREE
9UXCaU6hEAq84
17 sys Library Direct interaction with the operating system https://docs.python.org/3/library/sys.html
Python Software Foundation FREE FREE
NfycaQUlCejPzek
18 traceback Library Detailed analysis of programming errors https://pypi.org/project/traceback-with-variables/
Lz3bbFTdHw- Python Software Foundation FREE FREE
19 math Library Advanced mathematical formulas and constants Bblw&dib_tag=se
https://pypi.org/project/mathlib/
Python Software Foundation FREE FREE
20 pathlib Library Simplified management of file and folder paths &keywords=PS61 Python Software Foundation FREE
https://pypi.org/project/pathlib/ FREE
088+step+up+10A
21 threading Library Simultaneous execution of multiple tasks https://pypi.org/project/thread/
&qid=1778923700 Python Software Foundation FREE FREE
22 Visual Studio Code Software's Tool Writing and editing programming code https://code.visualstudio.com/
&s=industrial&spr Microsoft FREE FREE
23 Google Colab Software's Tool Running Python code online on Google servers efix=ps61088+ste
https://colab.research.google.com/ Google FREE FREE
24 Overleaf Software's Tool Writing scientific texts and documents in LaTeX p+up+10a%
https://it.overleaf.com/project Digital Science FREE/EDUCATION FREE/EDUCATION
2Cindustrial%
25 Google Slides Software's Tool Creating and editing presentations https://workspace.google.com/products/slides/
2C186&sr=1-1 Google FREE FREE
26 Roboflow Software's Tool AI dataset management and preparation https://roboflow.com/ Roboflow, Inc. FREE FREE
27 LabelingIMG Software's Tool Tool for manual image labeling https://pypi.org/project/labelImg/ Tzutalin FREE FREE
28 Fusion 360 Software's Tool Computer-aided 3D design and modeling https://www.autodesk.com/it/products/fusion-360/overview
Autodesk FREE FREE
29 Bambu studio Software's Tool Preparing 3D files for 3D printing https://bambulab.com/it-it/download/studioBambu Lab FREE FREE
30 Real VNC Software's Tool remote access and control software https://www.realvnc.com/en/ Andy Harter FREE FREE
31 Premiere Pro Software's Tool Professional video editing and cutting https://www.adobe.com/ Adobe Inc. € 1,00 $1,16)
32 After Effect Software's Tool Creation of special effects and motion graphics https://www.adobe.com/ Company of Science and Art € 1,00 $1,16)
33 Media Encoder Software's Tool Fast conversion and rendering of video files https://www.adobe.com/ Adobe Inc. € 1,00 $1,16)
34 Photoshop Software's Tool Photo editing and digital image manipulation https://www.adobe.com/ Thomas and John Knoll € 1,00 $1,16)
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Team description paper
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Source code
The team's own source code, 7.9 MB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.