
Kavosh_Line
Document register
- Poster1 pagePublished
- Presentation videoNot shared
- Bill of materials57 KBPublished
- Team description paper415 KBPublished
- Engineering journalNot shared
- Source code7 KB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
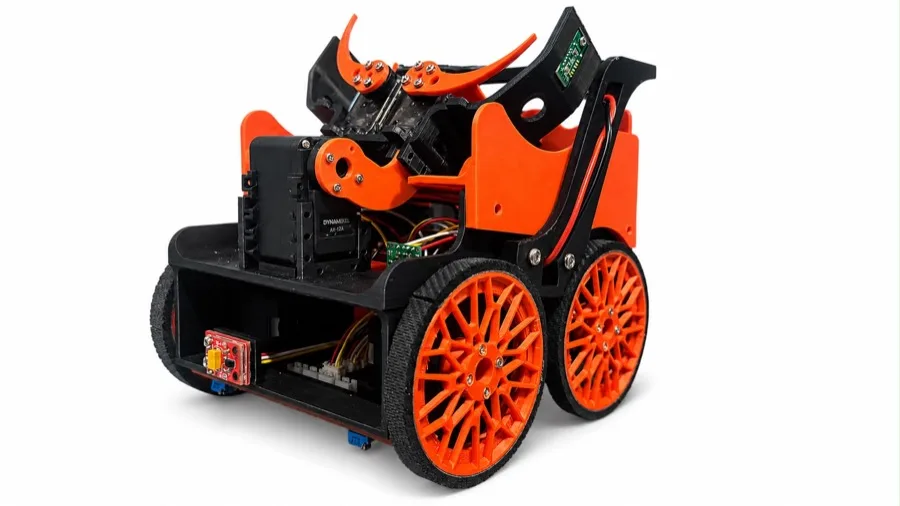
Kavosh Rescue Line Robot is a compact, reliable, and competition-ready autonomous robot designed for accurate navigation, fast decision-making, and consistent rescue performance in the RoboCupJunior Rescue Line challenge. The robot is built around a Teensy 4.1 controller, a four-wheel DYNAMIXEL XC430 drive system, custom 3D-printed rubber-coated wheels, and a modular sensor layout. It uses 16 TCRT5000 reflective sensors for precise line tracking, three APDS9960 color sensors for floor-marker and evacuation-zone color detection, four VL53L1X time-of-flight distance sensors for obstacle and evacuation-zone awareness, and micro switches for reliable mechanical feedback. The main capabilities of the robot include stable line following, intersection decision-making, obstacle avoidance, ramp and gap handling, evacuation-zone entry, structured victim search, victim collection, and safe-zone placement. What sets the robot apart is the combination of mechanical simplicity, strong sensor coverage, fast processing, modular electronics, and easy repair during competition. Each subsystem was tested separately before full integration, which improved debugging and reliability under competition pressure. The project is also supported by Team Kavosh’s long-term RoboCup experience, giving the team a strong background in building practical and robust autonomous rescue robots.
Poster
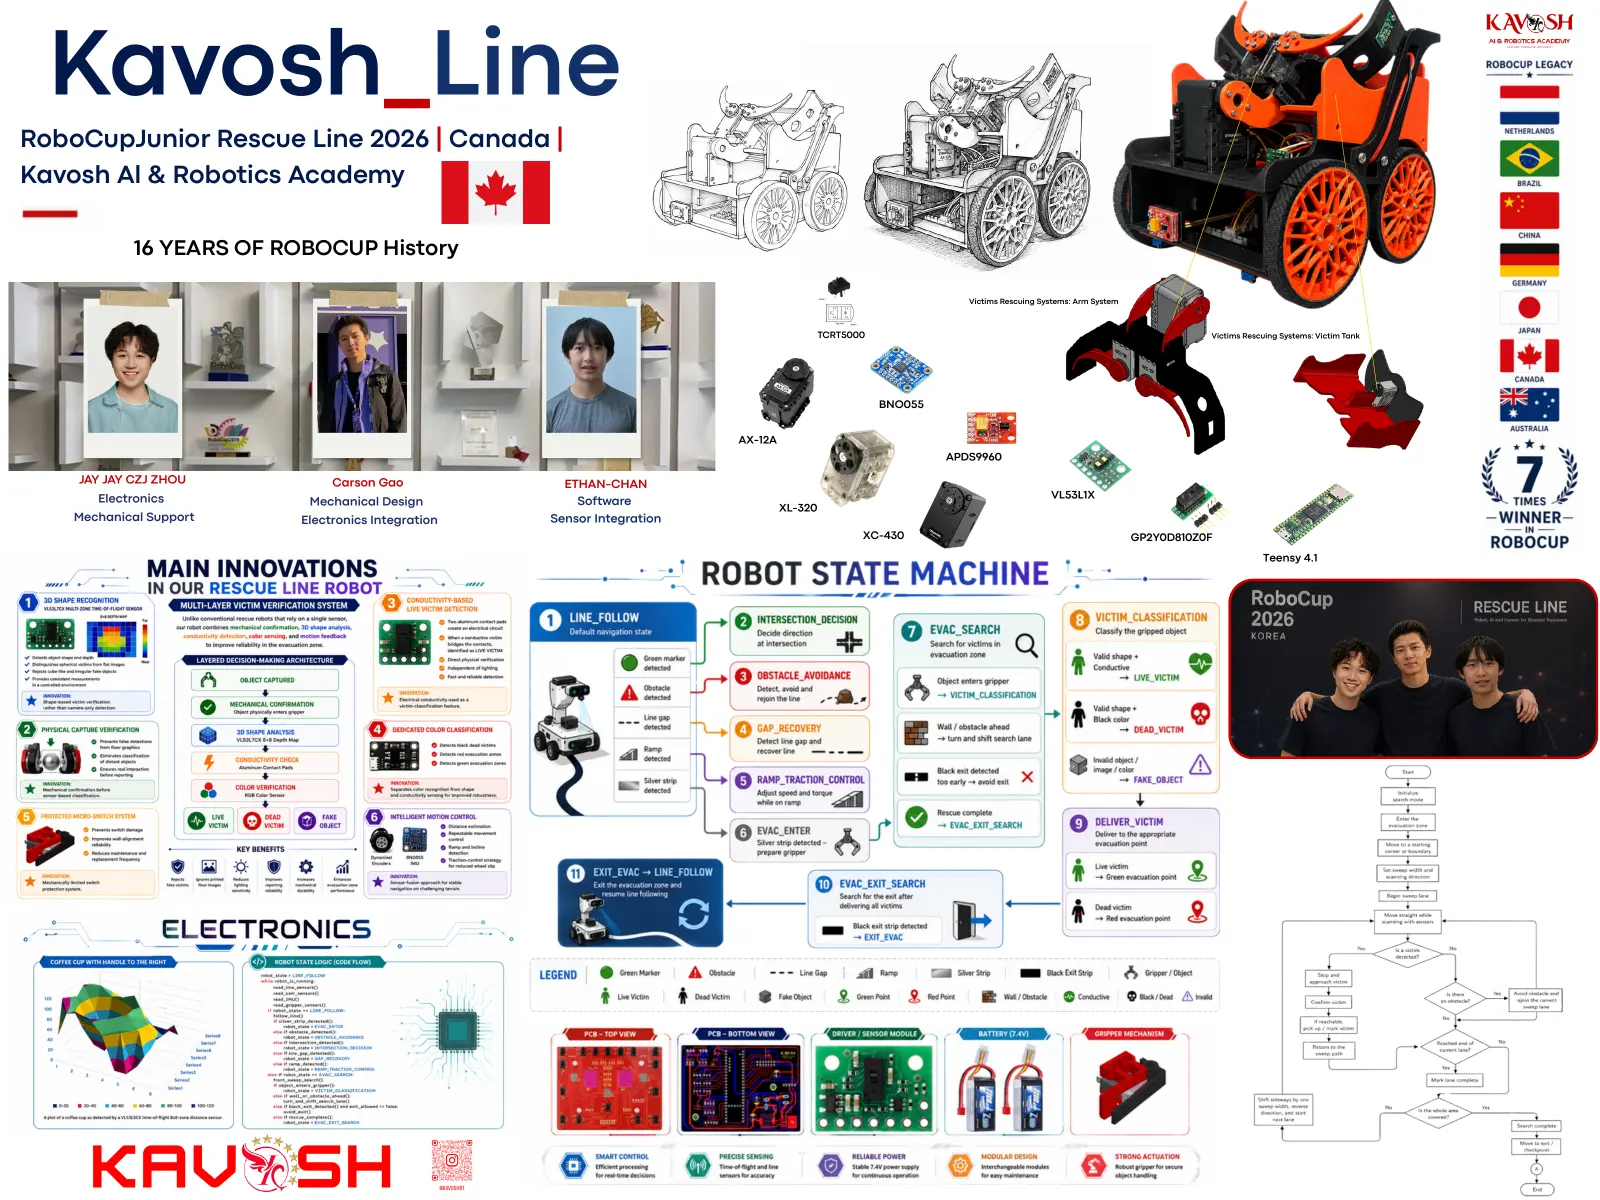
Read the text of this document — 57 words
Kavosh_Line
RoboCupJunior Rescue Line 2026 | Canada |
Kavosh Al & Robotics Academy

            16 YEARS OF ROBOCUP History

                                                                                                                 Victims Rescuing Systems: Arm System

                                                                                          TCRT5000                                                                 Victims Rescuing Systems: Victim Tank

                                                                                                     BNO055

                                                                        AX-12A
                                                                                                              APDS9960

    JAY JAY CZJ ZHOU          Carson Gao             ETHAN-CHAN
       Electronics                                                                                                                  VL53L1X
                          Mechanical Design            Software                  XL-320
    Mechanical Support   Electronics Integration   Sensor Integration
                                                                                                 XC-430                                                 GP2Y0D810Z0F
                                                                                                                                                                               Teensy 4.1

      KAV                SH
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Bill of materials
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Team description paper
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Source code
The team's own source code, 7 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.