
DMS-Kaede
Document register
- Poster1 pagePublished
- Presentation videoYouTubePublished
- Bill of materials91 KBPublished
- Team description paperNot shared
- Engineering journalNot shared
- Source code4 KB · GitHubPublished
Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
In their words
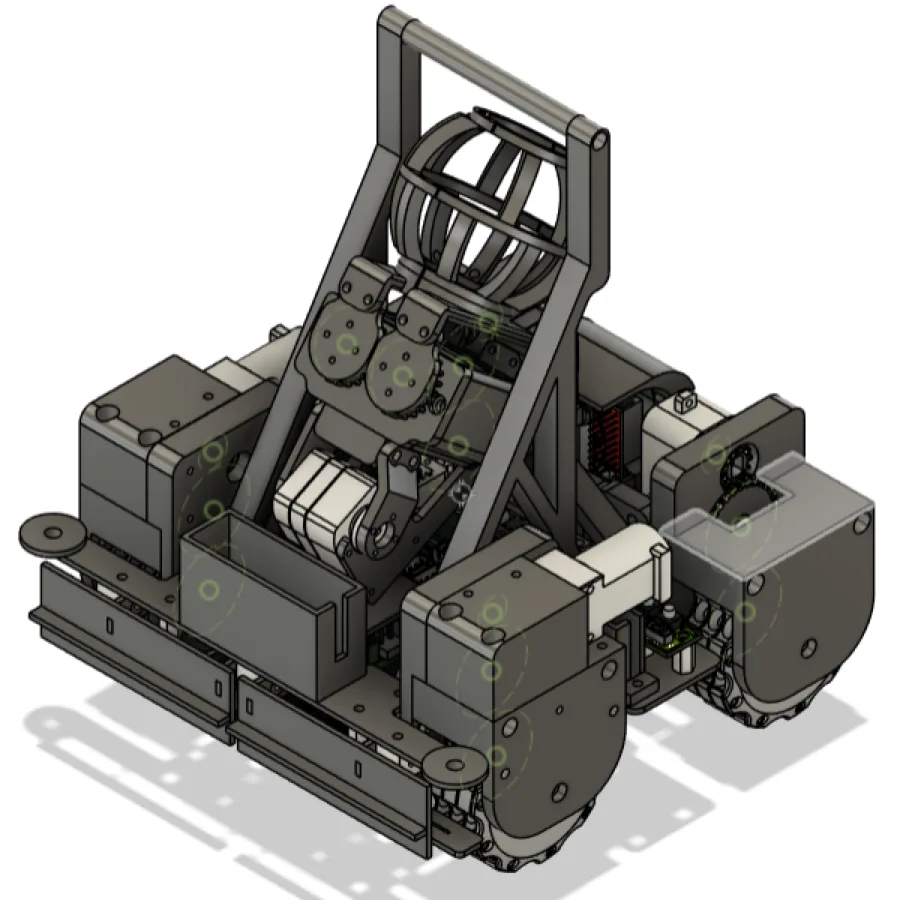
This robot is equipped with an arm for retrieving balls. It also has suspension installed at the rear to help it navigate steps and other obstacles more easily.
Poster
Read the text of this document — 170 words
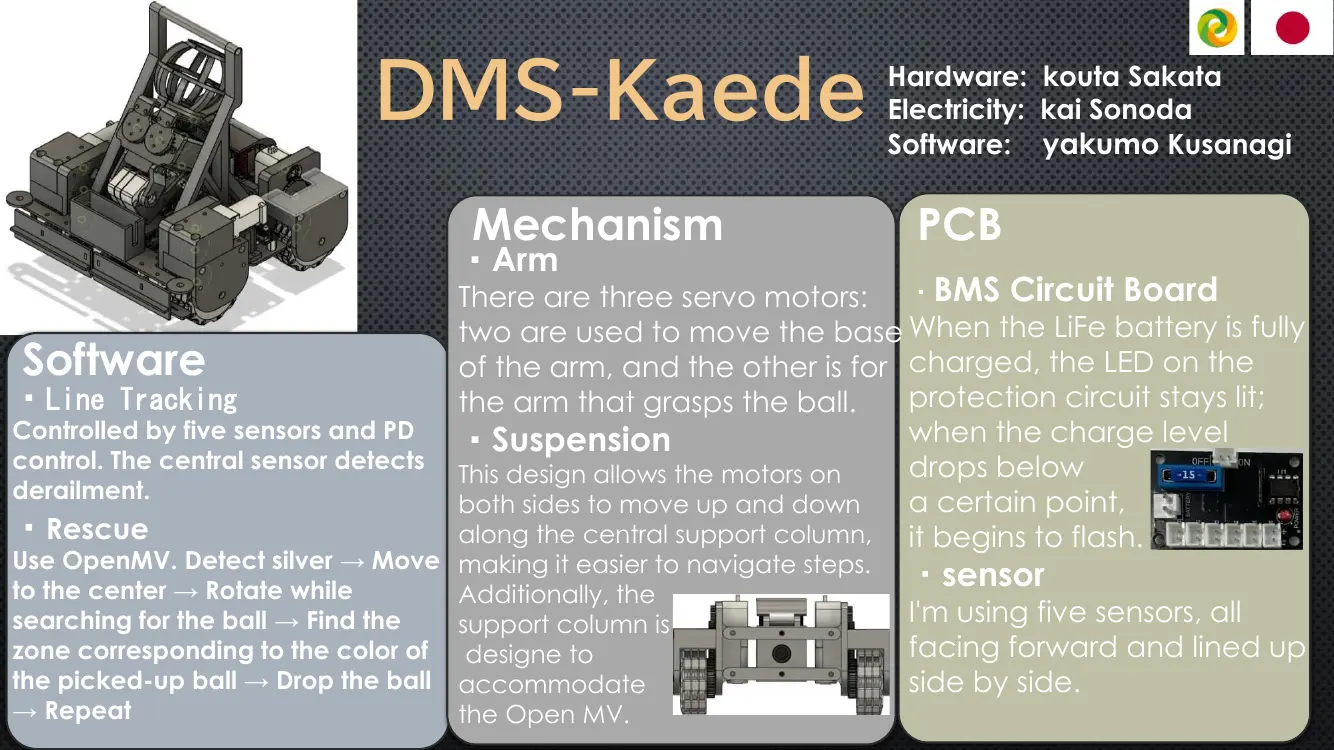
DMS-Kaede                                     Hardware: kouta Sakata
                                                                            Electricity: kai Sonoda
                                                                            Software: yakumo Kusanagi

                                       Mechanism                             PCB
                                      ・Arm
                                      There are three servo motors: ・BMS Circuit Board
                                      two are used to move the base When the LiFe battery is fully
Software                              of the arm, and the other is for charged, the LED on the
・Line Tracking                        the arm that grasps the ball.     protection circuit stays lit;
Controlled by five sensors and PD     ・Suspension                       when the charge level
control. The central sensor detects                                     drops below
                                      This design allows the motors on
derailment.                                                             a certain point,
                                      both sides to move up and down
・Rescue                               along the central support column, it begins to flash.
Use OpenMV. Detect silver → Move      making it easier to navigate steps.
to the center → Rotate while
                                                                             ・sensor
                                      Additionally, the
searching for the ball → Find the     support column is                      I'm using five sensors, all
zone corresponding to the color of     designe to                            facing forward and lined up
the picked-up ball → Drop the ball    accommodate                            side by side.
→ Repeat                              the Open MV.
1 page, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.
Presentation video
Hosted on YouTube. The player loads only when you press play.
Bill of materials
Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.
Source code
The team's own source code, 4 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.