Bricks

Line league · Republic of Korea · RoboCup 2026

Document register

  1. Poster1 pagePublished
  2. Presentation videoYouTubePublished
  3. Bill of materials5 pagesPublished
  4. Team description paper118 KBPublished
  5. Engineering journalNot shared
  6. Source code35 KB · GitHubPublished

Sharing each document is the team's decision. “Not shared” means this team chose not to publish it, or did not submit one — not that it is missing from the archive.
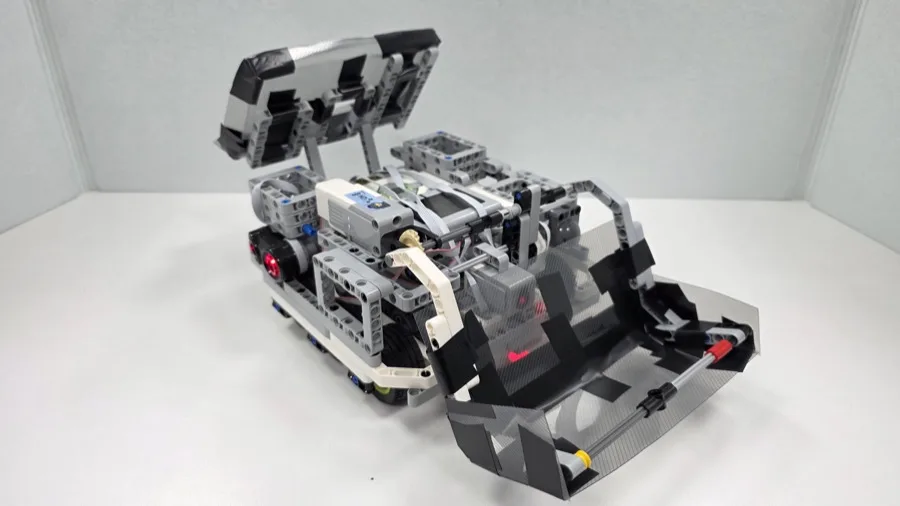
Bricks's robot
The Bricks team

In their words

Our team developed an autonomous rescue robot capable of real-time navigation and victim rescue in complex environments. The main objective of this project was to create a robot that could accurately follow lines, detect rescue zones, and safely transport victims while overcoming obstacles commonly found in rescue environments. Since disaster-response scenarios often involve unstable terrain, obstacles, and limited accessibility, the robot had to be both mechanically durable and computationally reliable. Unlike ordinary robots that focus only on movement, our robot was designed with both mobility and rescue capabilityin mind. The system combines stable hardware, sensor-based environmental recognition, and optimized software algorithms to perform rescue missions autonomously. In particular, the robot was developed to satisfy competition requirements while maintaining practical performance in challenging situations To improve mobility and reduce unnecessary weight, the robot uses medium motors instead of large motors, making the entire structure lighter without significantly sacrificing performance. By reducing total weight, the robot achieved better maneuverability and efficiency during long operations. At the same time, a gear reduction system was implemented to compensate for the lower motor power and ensure sufficient torque for lifting victims and climbing slopes. The robot uses color sensors and a gyro sensorto recognize environmental conditions and maintain driving stability. Color sensors allow the robot to detect lines and identify rescue areas, while the gyro sensor continuously monitors the robot’s tilt and angle. Through this system, the robot can adjust speed and maintain balance when climbing slopes or moving across uneven terrain. Additionally, a lifting mechanism powered by medium motors enables the robot to pick up and transport victims safely.

Poster
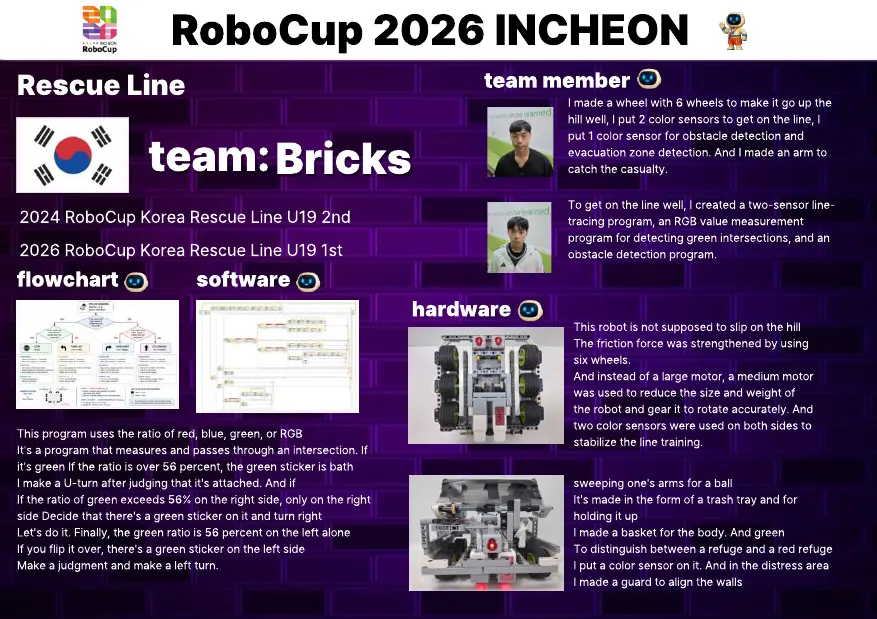
1 page, rendered as images so they load quickly. This document has no text layer — the words in it are part of the image.

Download the original PDF (274 KB) from GitHub

Presentation video

Hosted on YouTube. The player loads only when you press play.

Open in YouTube

Bill of materials

Show the remaining 2 pages
Read the text of this document — 1243 words
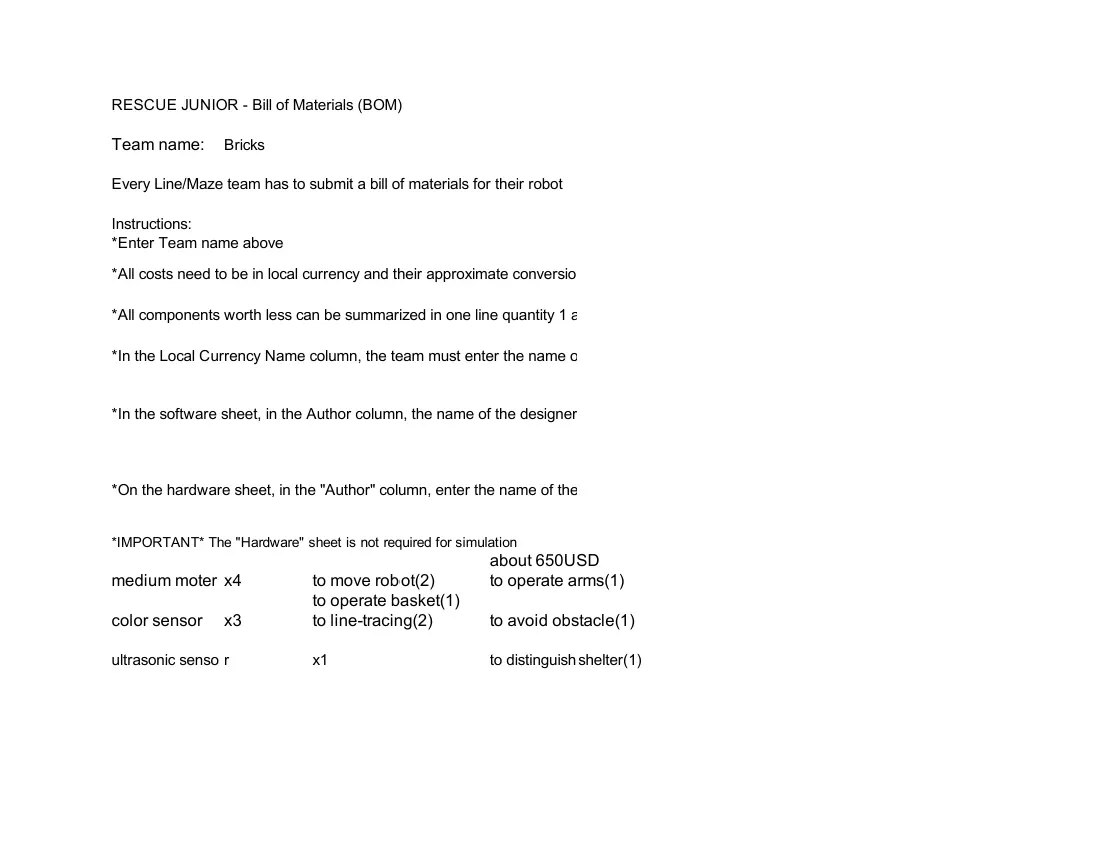
RESCUE JUNIOR - Bill of Materials (BOM)

Team name:       Bricks

Every Line/Maze team has to submit a bill of materials for their robot

Instructions:
*Enter Team name above
*All costs need to be in local currency and their approximate conversion

*All components worth less can be summarized in one line quantity 1 a

*In the Local Currency Name column, the team must enter the name o

*In the software sheet, in the Author column, the name of the designer

*On the hardware sheet, in the "Author" column, enter the name of the

*IMPORTANT* The "Hardware" sheet is not required for simulation
                                                          about 650USD
medium moter x4                to move roboot(2)          to operate arms(1)
                               to operate basket(1)
color sensor     x3            to line-tracing(2)         to avoid obstacle(1)

ultrasonic senso r             x1                         to distinguish shelter(1)
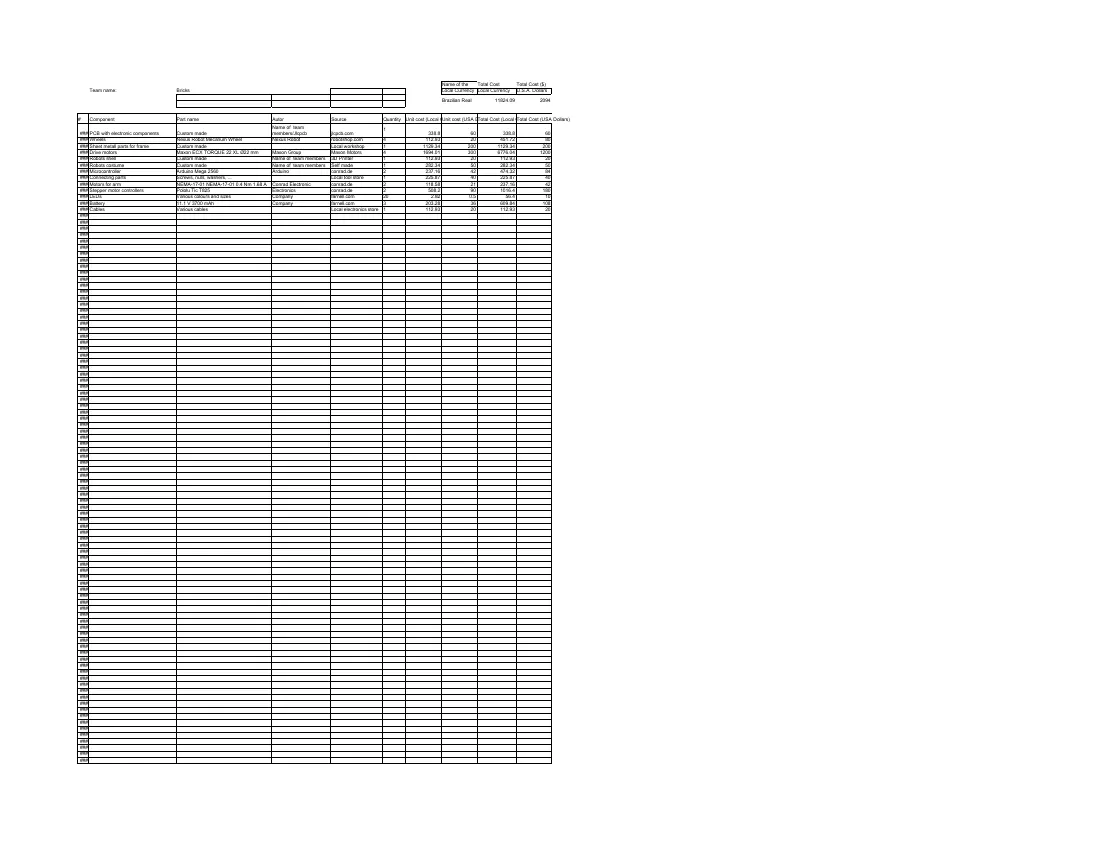
                                                                                                                                                        Name of the    Total Cost         Total Cost ($)
    Team name:                       Bricks                                                                                                             Local Currency Local Currency     U.S.A. Dollars
                                                                                                                                                        Brazilian Real         11824.09             2094

#   Component                        Part name                             Autor                  Source                    Quantity Unit cost (Local CUnit cost (USA DTotal Cost (Local CTotal Cost (USA Dollars)
                                                                           Name of team
                                                                                                                            1
### PCB with electronic components   Custom made                           members/Jlcpcb         jlcpcb.com                                    338.8                 60          338.8               60
### Wheels                           Nexus Robot Mecanum Wheel             Nexus Robot            robotshop.com             4                  112.93                 20         451.72               80
### Sheet metall parts for frame     Custom made                                                  Local workshop            1                 1129.34               200         1129.34              200
### Drive motors                     Maxon ECX TORQUE 22 XL Ø22 mm         Maxon Group            Maxon Motors              4                 1694.01               300         6776.04             1200
### Robots shell                     Custom made                           Name of team members   3D Printer                1                  112.93                 20         112.93               20
### Robots costume                   Custom made                           Name of team members   Self made                 1                  282.34                 50         282.34               50
### Microcontroller                  Arduino Mega 2560                     Arduino                conrad.de                 2                  237.16                 42         474.32               84
### Connecting parts                 Screws, nuts, washers, ...                                   Local tool store          1                  225.87                 40         225.87               40
### Motors for arm                   NEMA-17-01 NEMA-17-01 0.4 Nm 1.68 A   Pololu Robotics
                                                                           Conrad  Electronic
                                                                                           and    conrad.de                 2                  118.58                 21         237.16               42
### Stepper motor controllers        Pololu Tic T825                       Farnell An Avnet
                                                                           Electronics            conrad.de                 2                   508.2                 90         1016.4              180
### LEDs                             Various colours and sizes             Company
                                                                           Farnell An Avnet       farnell.com               20                   2.82                0.5           56.4               10
### Battery                          11.1 V 3700 mAh                       Company                farnell.com               3                  203.28                 36         609.84              108
### Cables                           Various cables                                               Local electronics store   1                  112.93                 20         112.93               20
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
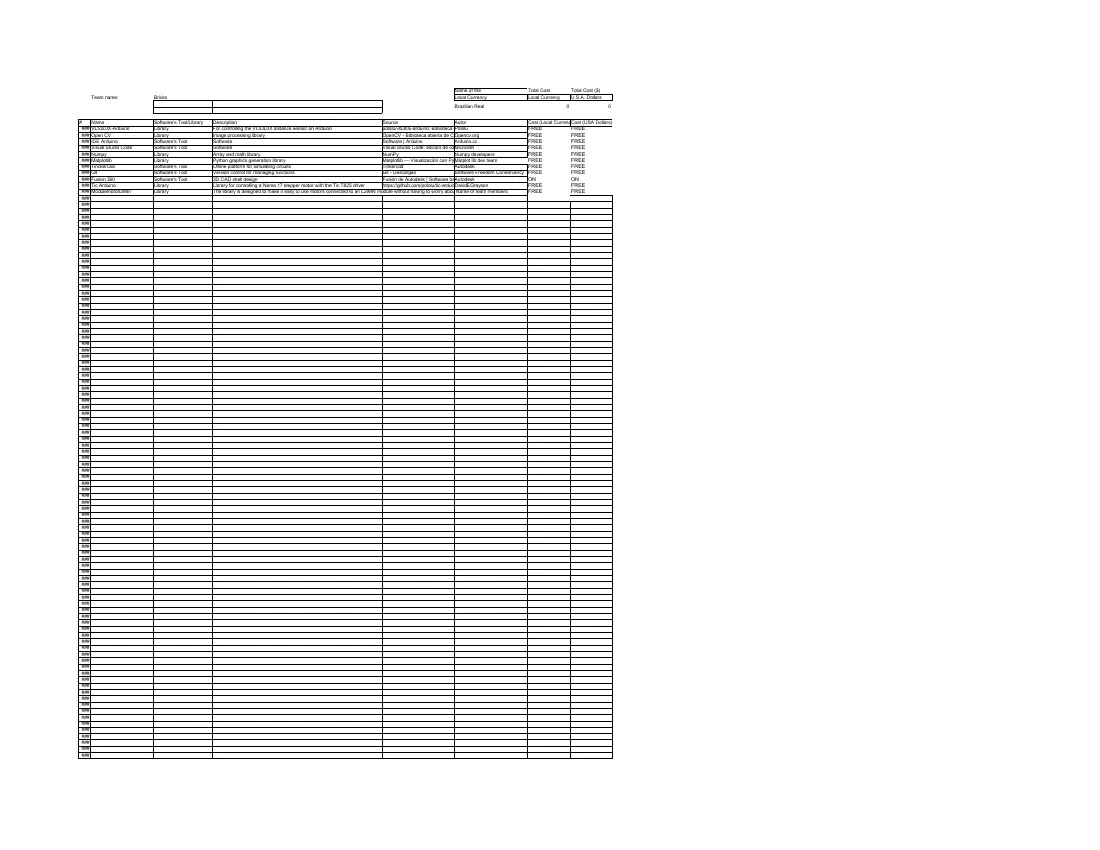
                                                                                                                                                                  Name of the                        Total Cost           Total Cost ($)
     Team name:           Bricks                                                                                                                                  Local Currency                     Local Currency       U.S.A. Dollars
                                                                                                                                                                  Brazilian Real                                      0                    0

#    Name                 Software's Tool/Library   Description                                                                   Source                              Autor                          Cost (Local CurrencCost (USA Dollars)
 ### VL53L0X-Arduino      Library                   For controlling the VL53L0X distance sensor on Arduino                        pololu/vl53l0x-arduino: Biblioteca PPololu                         FREE         FREE
 ### Open CV              Library                   Image processing library                                                      OpenCV - Biblioteca abierta de CoOpencv.org                        FREE         FREE
 ### IDE Arduino          Software's Tool           Software                                                                      Software | Arduino                  Arduino.cc                     FREE         FREE
 ### Visual Studio Code   Software's Tool           Software                                                                      Visual Studio Code: edición de cóMicrosoft                         FREE         FREE
 ### Numpy                Library                   Array and math library                                                        NumPy                               Numpy developers               FREE         FREE
 ### Matplotlib           Library                   Python graphics generation library                                            Matplotlib — Visualización con PyMatplot lib dev team              FREE         FREE
 ### Tinckercad           Software's Tool           Online platform for simulating circuits                                       Tinkercad                           Autodesk                       FREE         FREE
 ### Git                  Software's Tool           Version control for managing functions                                        Git - Descargas                     Software Freedom Conservancy   FREE/EDUCATI
                                                                                                                                                                                                     FREE         FREE/EDUCATI
                                                                                                                                                                                                                  FREE
 ### Fusion 360           Software's Tool           3D CAD shell design                                                           Fusión de Autodesk | Software baAutodesk                           ON           ON
 ### Tic Arduino          Library                   Library for controlling a Nema 17 stepper motor with the Tic T825 driver      https://github.com/pololu/tic-arduinDavidEGrayson                  FREE         FREE
 ### Modulemotorl298n     Library                   The library is designed to make it easy to use motors connected to an L298N module without having to worry abou Name of team members             FREE         FREE
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
 ###
                                                                       Name of the            Total Cost          Total Cost ($)
   Team name:   Bricks                                                 Local Currency         Local Currency      U.S.A. Dollars
                                                                       Brazilian Real
                                                                                                             77      #NAME?
                                                                       BRL

#   Component   Part name   Autor   Source   Quantity   Unit cost (LocalUnit cost (US Dollars) Total Cost (Local C
                                                                                                                 Total Cost (USA Dollars)
###                                                                            #NAME?                        77     #NAME?
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
###                                                                                                           0                0
                                                               Name of the      Total Cost           Total Cost ($)
   Team name:   Bricks                                         Local Currency   Local Currency       U.S.A. Dollars
                                                               Brazilian Real                    0                    0

#   Name        Software's Tool/Library Description   Source   Autor            Cost (Local CurrenCost (USA Dollars)
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###
###

Open as plain text

5 pages, rendered as images so they load quickly. The text above is the document's own, extracted from the PDF.

Download the original PDF (103 KB) from GitHub

Team description paper

Shown as the original PDF, because this one is smaller that way and its text stays selectable and searchable.

Open Team description paper

Source code

The team's own source code, 35 KB. It is a download rather than part of this page, because a zip is something you open on your computer. It comes from GitHub, which some school networks block.

Download Bricks's source code